News
SpaceX’s recent Starship testing challenges don’t worry Elon Musk

In his latest burst of tweets, SpaceX CEO Elon Musk says he isn’t all that worried about a duo of recent Starship prototype failures and talked next steps for the next few Starships.
Aside from SpaceX’s South Texas rocket factory, Musk also touched on progress being made on the cutting-edge Raptor engine set to power Starships and their boosters, revealing a small production milestone in the process. The CEO says that SpaceX has already begun building its 26th Raptor engine, a sign that Raptors may actually be waiting on Starships in a turn of events. Back when SpaceX was busy testing its low-fidelity Starhopper testbed, the ship actually had to wait several months for the full-scale Raptor engine’s design to mature enough to support 15-30+ second hop tests.
Now, Musk’s Raptor SN26 reveal implies that SpaceX is slowly but surely ramping up production of the new engine back at its Hawthorne, California headquarters.

From August to December 2019, SpaceX completed one Raptor engine every ~17 days, on average. With Musk’s confirmation that SpaceX is currently building (or already testing) SN26, the company is completing an engine every 12-14 days – an overall improvement of 20-40%. In other words, SpaceX’s growing engine production capacity is almost perfectly positioned to support a fleet of suborbital Starship prototypes, which is about where the company’s Boca Chica, Texas factory is today.
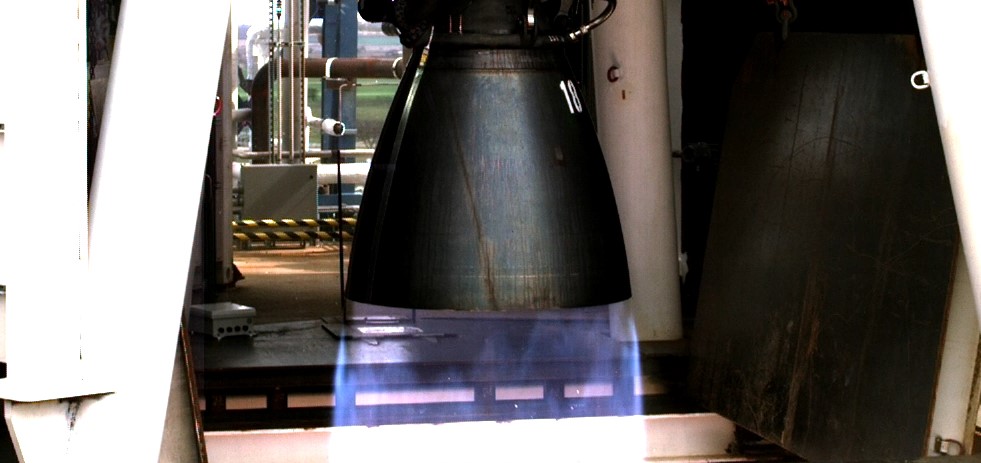
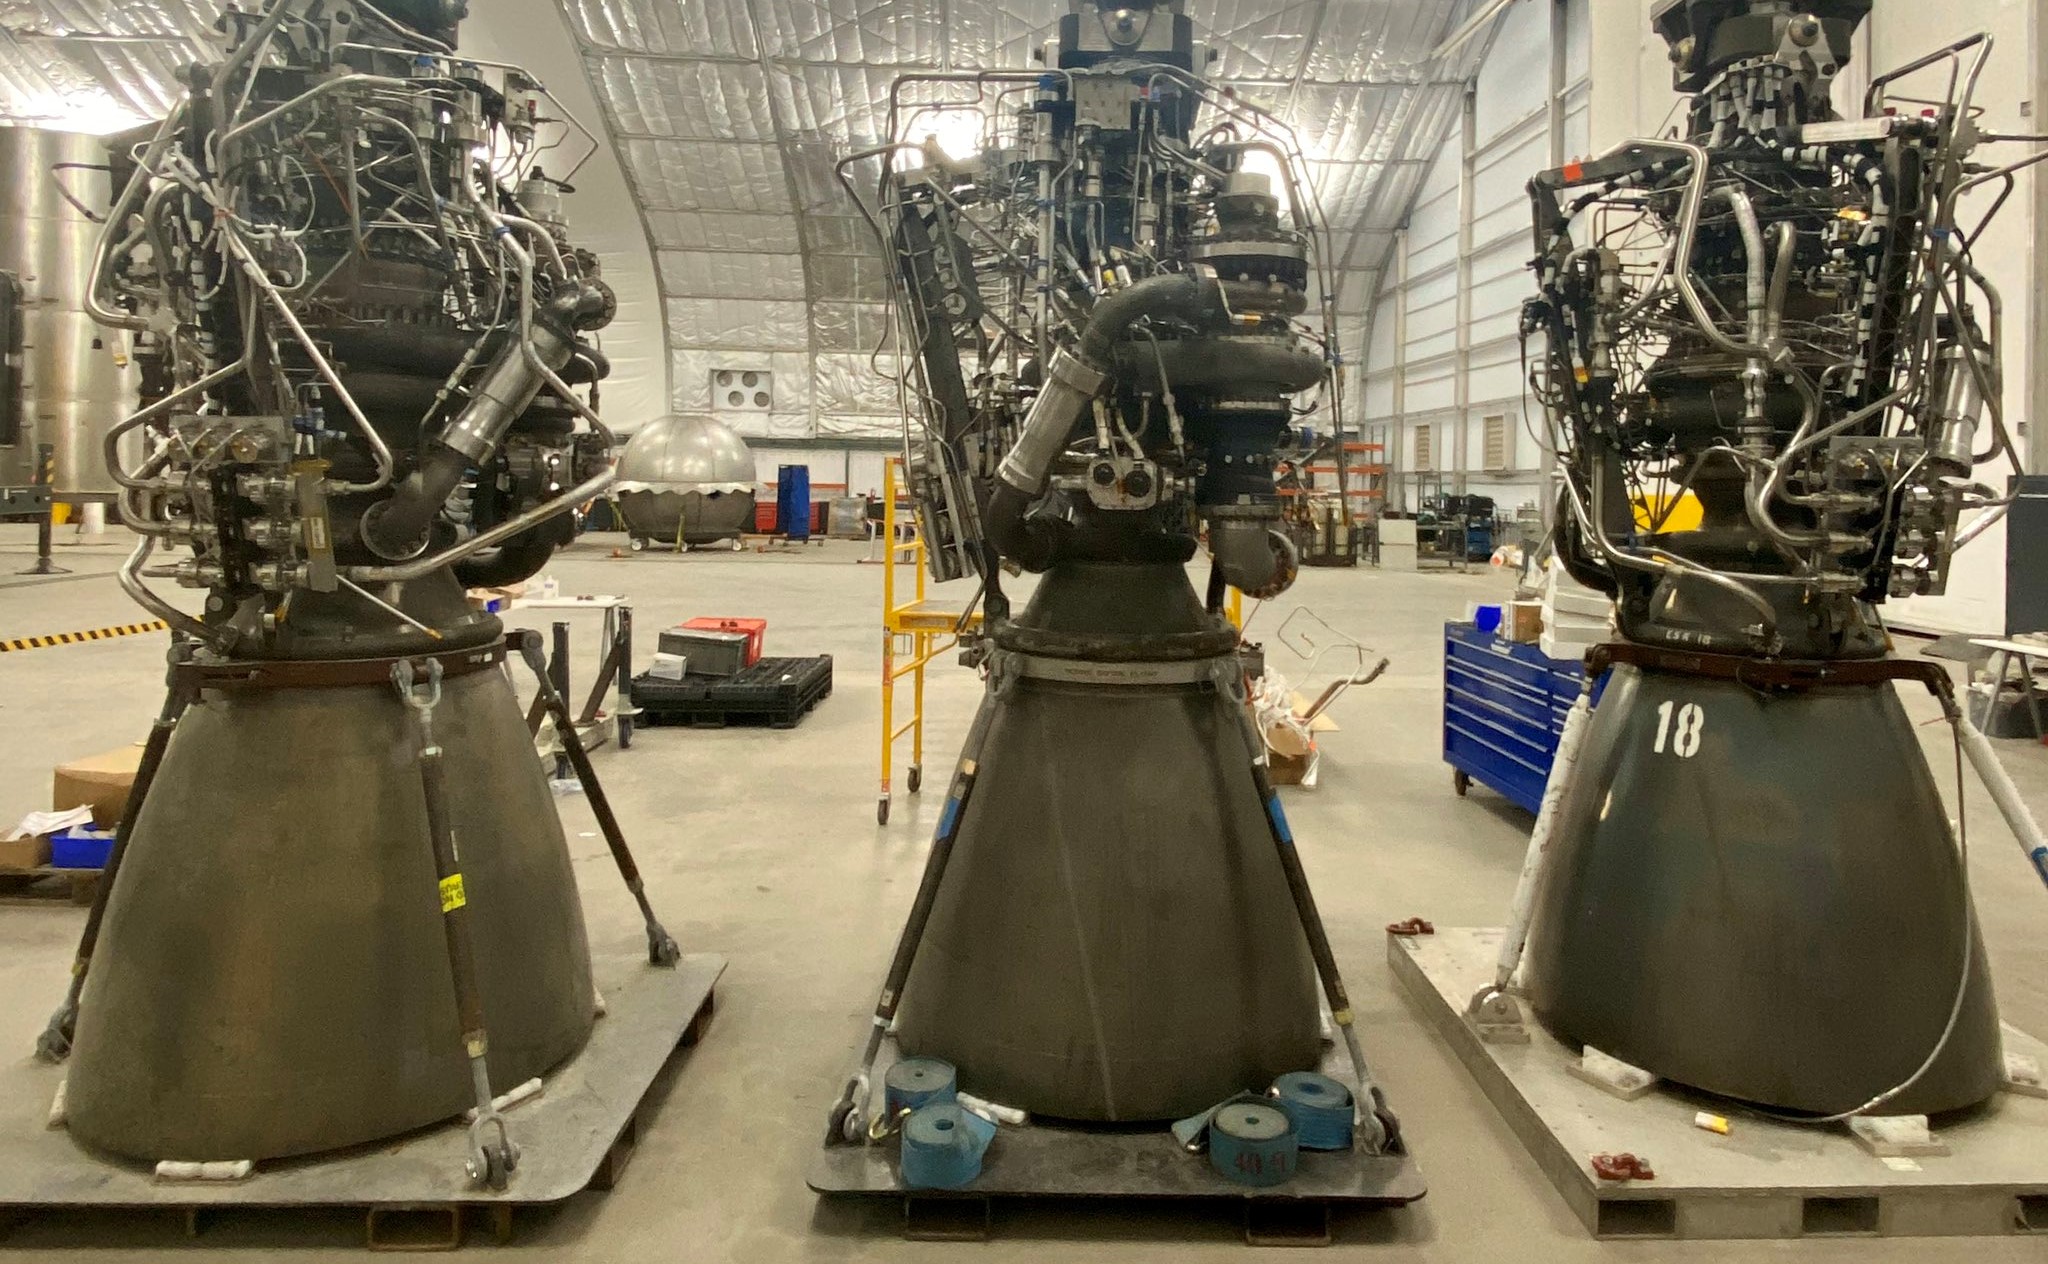
Obviously, following two recent full-scale Starship prototype failures spaced barely a month apart, rocket production has a ways to go before it will need the volume of Raptor engines SpaceX appears to already be capable of producing. For the time being, three Raptor engines – having already completed production in Hawthorne and acceptance testing in McGregor, Texas – are quite literally sitting around and gathering dust as they wait for the first Starship prototype qualified to host them.
Once a Starship passes proof testing, SpaceX will be able to install either one or all three engines for an inaugural static fire test, following by a small Starhopper-class hop (no higher than 150m or 500 ft).
However, once SpaceX has explored the full range of testing available to suborbital Starship prototypes, things will change. Likely ending with the first one or several successful ‘skydiver-style’ rocket landing tests, SpaceX will finally be able to seriously think about its first orbital flight tests. To reach orbit and still be capable of returning to Earth and landing softly, Starship will need a Super Heavy booster – set to be the largest rocket booster ever developed by a large margin.
Although Musk has stated that early orbital flight tests will likely launch with far fewer engines, a single Super Heavy booster could eventually require 37 Raptor engines – a full 42% more engines than SpaceX has managed to build in the entire 15+ month history of full-scale Raptor production.
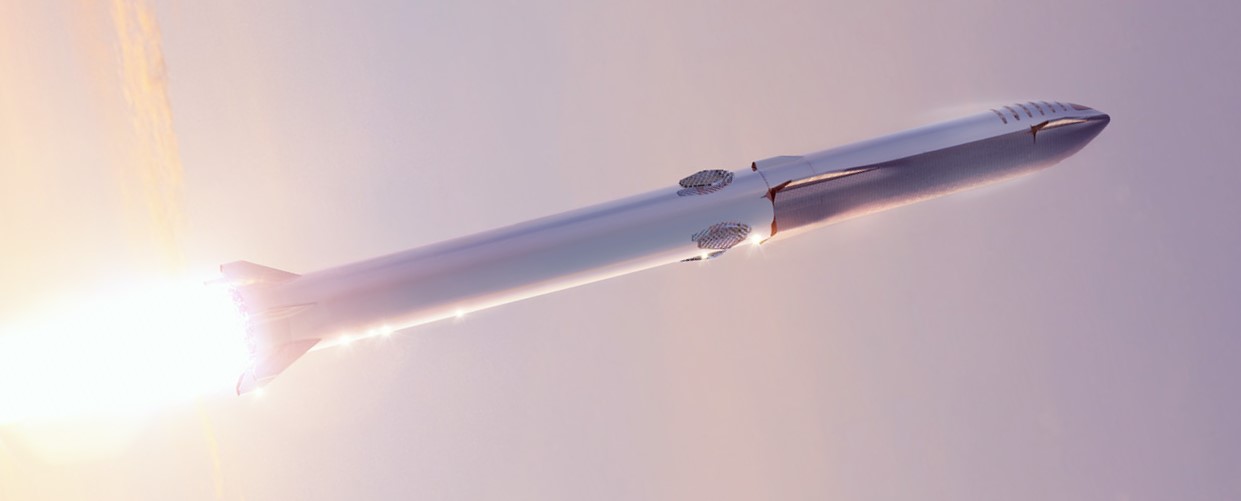
Thankfully, SpaceX’s engine production HQ likely has at least 6-12 months to ramp up production to support fully-outfitted Super Heavy boosters – let alone several. For the time being, each suborbital Starship only needs 3 sea level-optimized Raptor engines, although it’s possible that SpaceX will eventually perform suborbital tests with a full compliment of six engines – including three with much larger vacuum-optimized nozzles.
Ultimately, Musk explained that his lack of concern about recent Starship prototype failures – potentially including any anomalies that follow SN4’s test campaign – comes from the fact that he believes that producing Starships is a much more challenging and pressing concern. Indeed, if your factory can churn out functioning building-sized spacecraft for pennies on the dollar, losing a few during testing is little more than an annoyance. The first failed prototypes can thus be considered learning experiences, helping SpaceX improve designs and optimize the factory and production strategies. SpaceX does still need to prove that its existing approach really can build functioning rockets, but that should (in theory) come with enough trial and error.
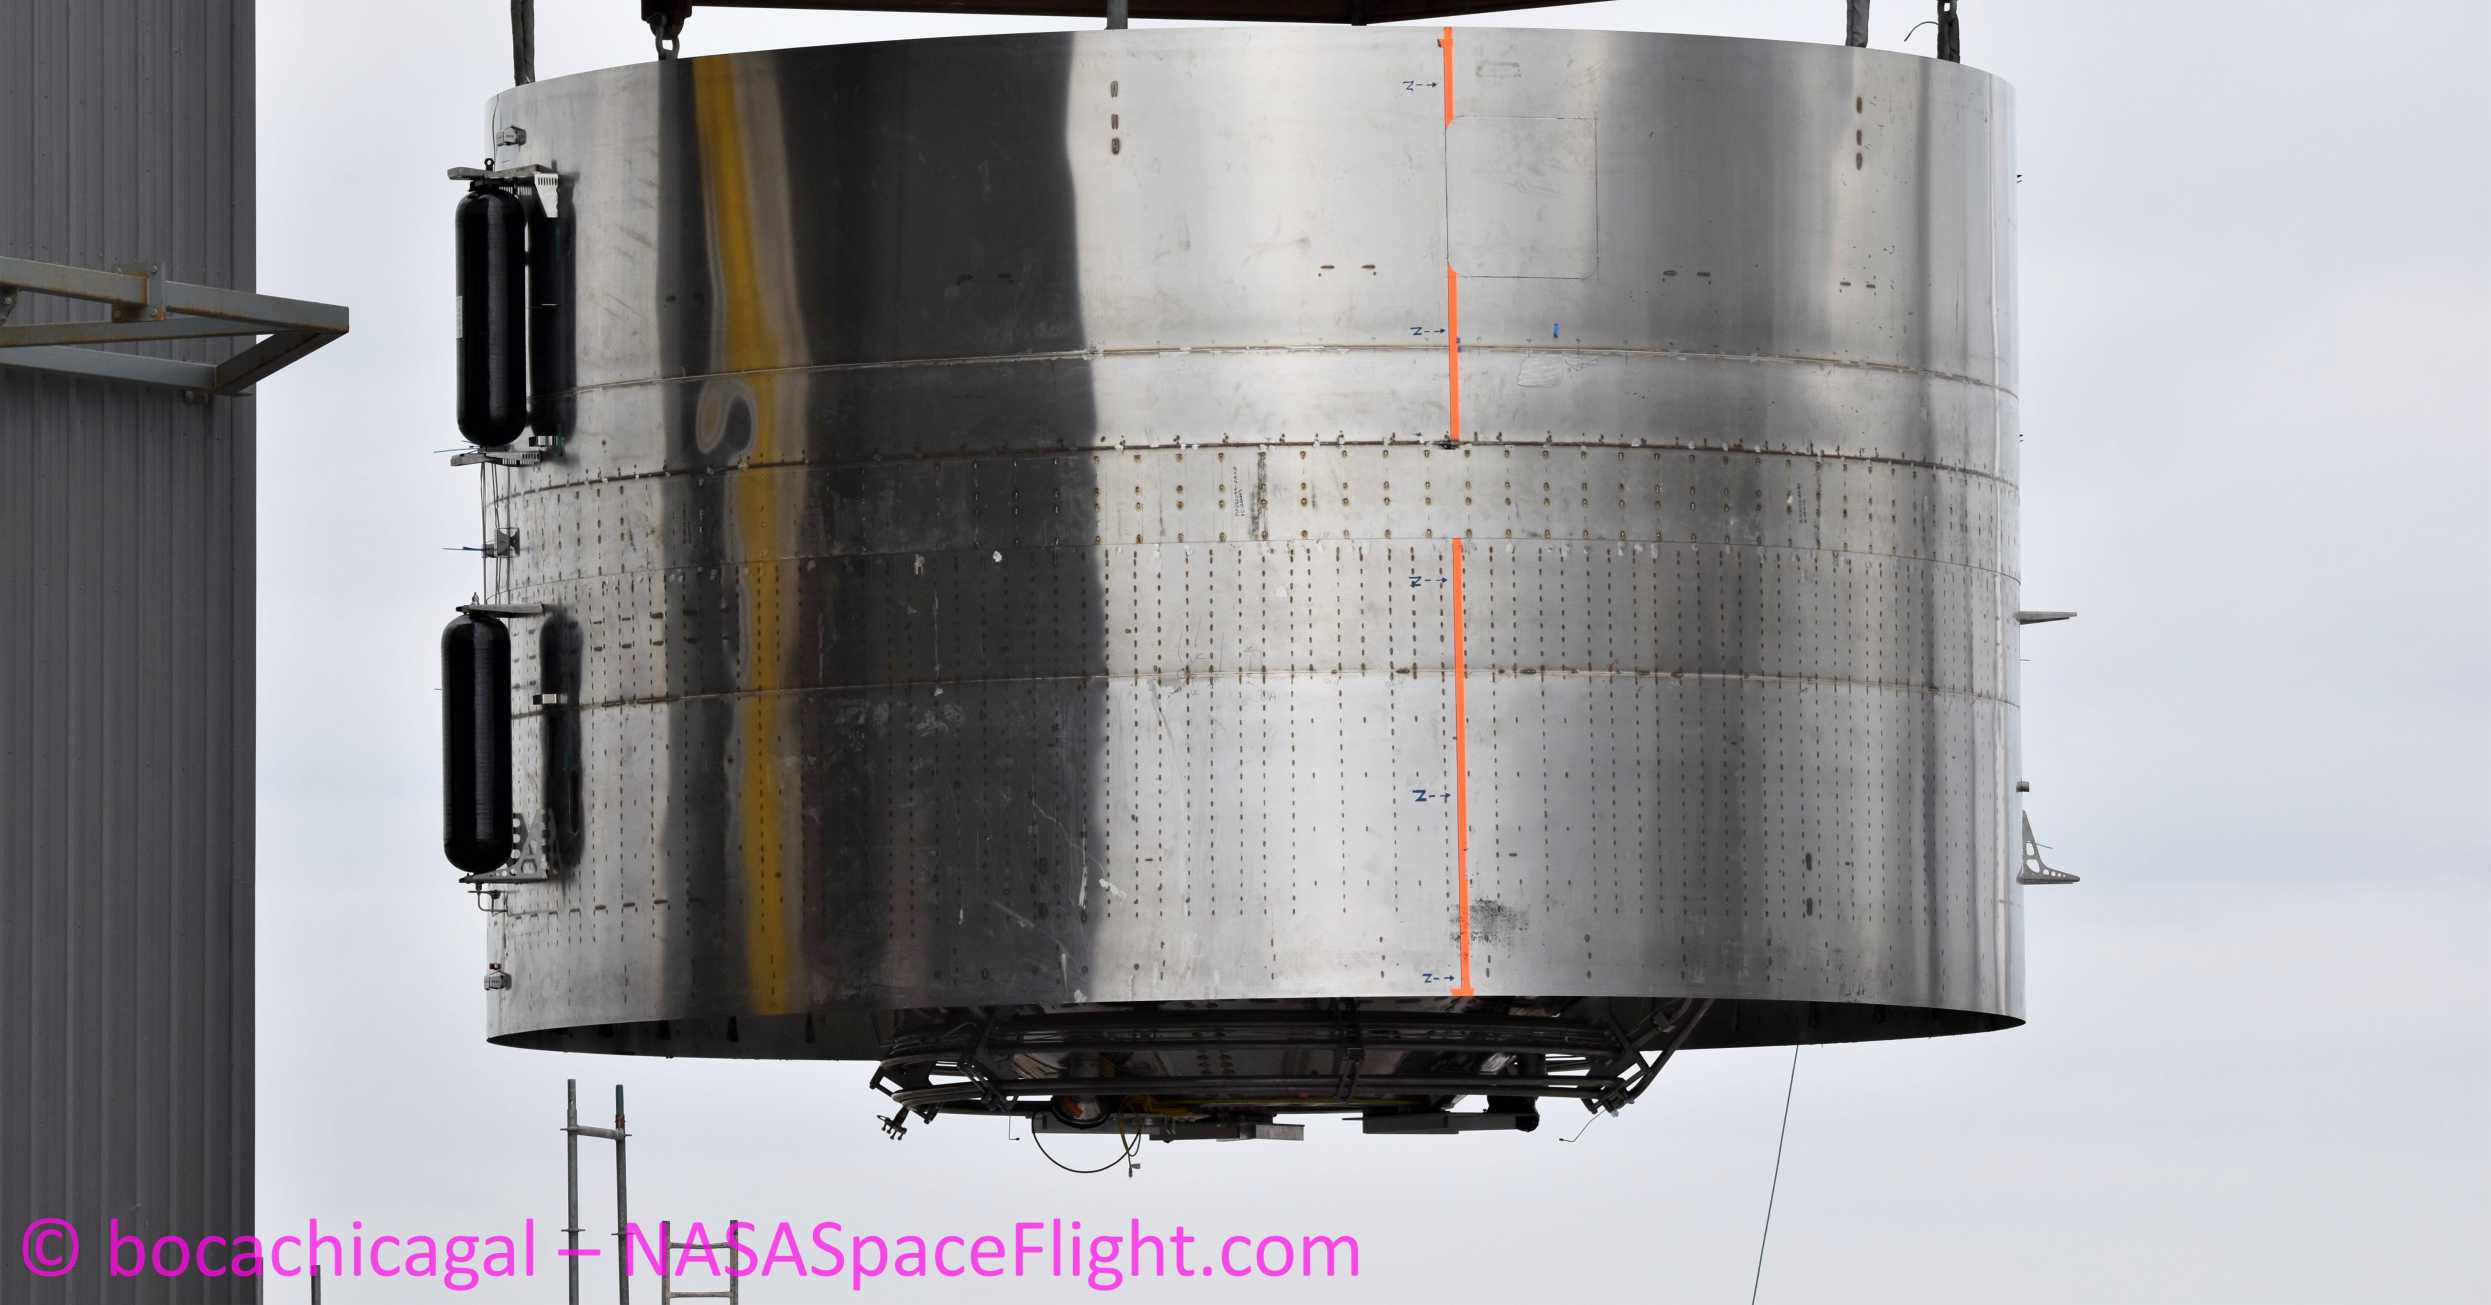
Depending on how initial tests go with Starship Serial Number 4 (SN4), likely days away from wrapping up production, Musk says that the first few suborbital Starship tests will likely involve short, low-velocity hops. Those flights will be slow enough that the ship (or ships) wont require aerodynamic control surfaces to complete them, instead relying entirely on smaller thrusters and the thrust vector control (TVC) provided by their three main Raptor engines.
If Starship SN4 testing – including wet dress rehearsals, Raptor static fires, and short hops – goes perfectly, Musk says that Starship SN5 could be the first new ship to have fully-functional flaps installed. If things don’t go quite as well, that milestone could shift to Starship SN6, while SN7 and beyond are obviously on the table in the event of even less forgiving SN4/SN5 testing scenarios. For now, Starship SN4 could be ready to move to the launch pad and kick off a series of critical proof tests a handful of days from now.


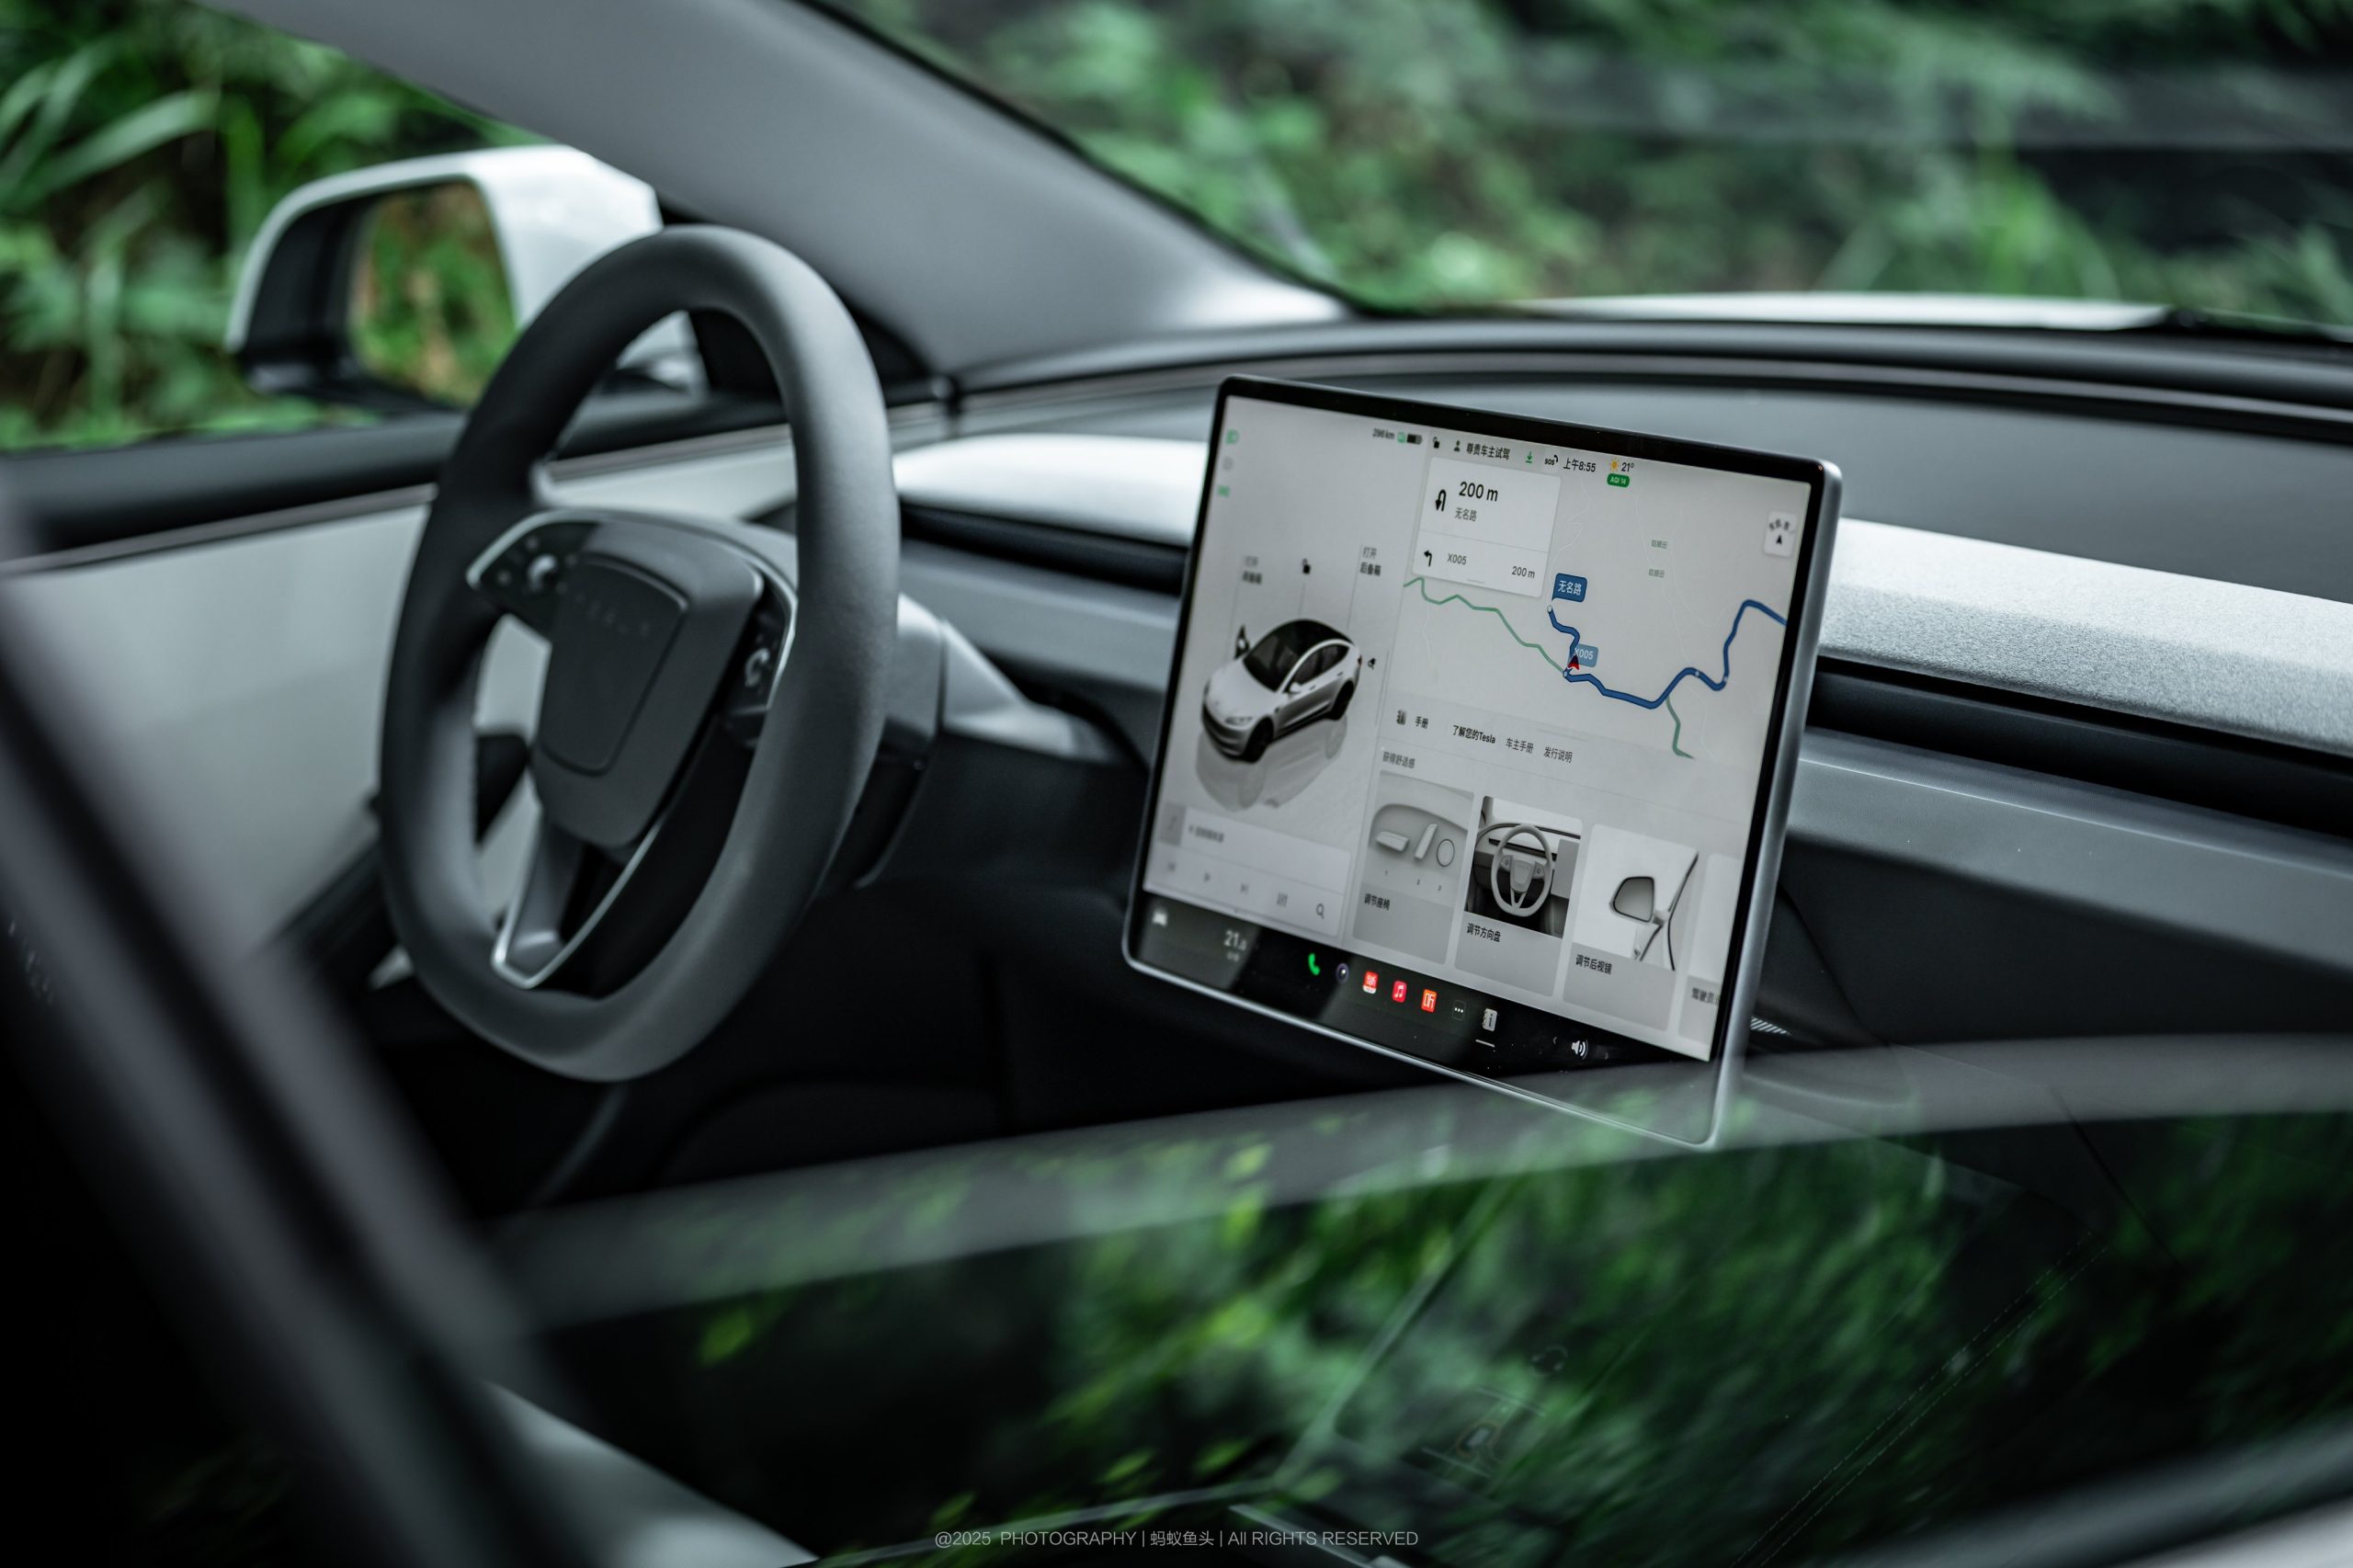
Tesla Full Self-Driving is really good. I have used it for over 76 percent of my driving since FSD v14 launched around this time last year, equating to about 76 percent of my miles using the suite. It’s truly the only way I prefer to travel, but admittedly I save some of the more fun drives for myself.
Even with all of the great things it has done for me, including saving me from being involved in an accident, there are still a handful of things that it needs to improve on. These issues recur from update to update, and while there have been some improvements, they still give me reasons to either soft or hard intervene.
A soft intervention means an adjustment that is needed without disengaging the suite, like manually using a turn signal to change lanes while the car still operates on FSD. What I’d consider to be a “hard intervention” is anything that requires me to disengage the suite altogether, like missing a turn or performing a maneuver I’m uncomfortable with. Of course, some hard interventions will be subjective.
Here are the five things I’d like to see Tesla really focus on through the final versions of v14 and hope to see completely improved with v15.
Speed Limit Recognition and Adjustment
There are entirely too many instances of FSD traveling at a speed that is just totally outrageous. While some of these events can occur on Hurry Mode, I’ve even had issues with it on Standard from time to time, and despite wanting more aggressive maneuvers or a slight bit of urgency, I don’t want to worry about getting a ticket while doing it.
The two areas I notice it the most are in school zones and on local roads. When a Speed Limit changes from 45 to 35, FSD does not always slow down in a way that would appease local law enforcement. On Hurry, 52-55 is pretty standard for a rate of travel in a 45 MPH zone. When it changes to 35, FSD shows zero urgency to slow down to an appropriate speed.
School Zones have been a true pain point, and as recently as last week, I had an issue with it:
Threw FSD into Sloth to see how it handled this school zone. You can see well before I enter it, the car is traveling 34 MPH, one MPH under the limit.
Still not slowing down nearly enough.@Tesla_AI, not 25, not 30…15 MPH in School Zones https://t.co/YQuQ8ydhKh
— TESLARATI (@Teslarati) September 29, 2026
Realistically, most Speed Limit issues are a soft intervention, as I simply scroll into a slower Speed Profile to get the car to slow down. School Zones are a hard intervention, as they require me to completely take over and travel at the posted 15 MPH limit. Even on Sloth, it simply does not get down to a low enough speed.
Parking
Parking is one thing that has really improved over time, but there are still some pretty considerable hoops Tesla needs to jump through to get it to a point where it can be unsupervised.
Parking preferences seem to be where a lot of these issues will be resolved, as most of my complaints come from the fact that the place FSD chooses to park are usually not where I would personally choose to park. This morning, for example, when I arrived at the gym, FSD chose to park next to a vehicle that was parked with its two tires in the spot that FSD picked.
This is a big reason Parking Preferences with Supervised FSD will be so valuable.
If possible, parking a little further away and being distant from people like this is worth it. https://t.co/3Ac71KQiQ3— TESLARATI (@Teslarati) June 7, 2026
There were three spots in between that car and the nearest car, so FSD could have chosen the spot that would have given a one-spot buffer between the two vehicles. In a parking lot full of empty spots, don’t be that guy who parks next to a car.
Generally, parking performance is vastly improved from where it was a year ago; I rarely am adjusting how it pulls or backs into a spot on v14.3.10, but in earlier versions, I definitely had my problems. It’s gotten really good since, and this version has been the best in terms of parking performance. It’s more about the places FSD choose to park, and not necessarily the parking itself.
There are also no options or map data to allow you to choose a charger at a place like a grocery store if it offers charging. These are things that are a bit more complex, but they will be needed for unsupervised FSD operation.
Navigation
Navigation was always going to be on this list, simply because it is one of the most inconsistent and mind-boggling things about FSD. Even after a year of intervening, sending voice notes, and overriding decisions, FSD still tries to take me out of my neighborhood the wrong way. You cannot turn left out of my neighborhood’s main entrance and exit, only right. Navigation still prompts a left turn out of my neighborhood’s main entrance and exit, instead of going around the neighborhood and exiting where a left turn is legal.
Tesla rolled out Preferred Routes with the Summer Update, and this has resolved some of the issues. I also found my own personal workaround:
🚨See if this cool Tesla Navigation Hack works for you!
I have used it to get out of my neighborhood legally with FSD, thus enabling completely hands-free drives! https://t.co/DlDsCQjxRI— TESLARATI (@Teslarati) July 16, 2026
Some of the more mind-boggling things that FSD used to do with Navigation have been remedied, but it is still a frequent complaint for me and many other owners. I’d just like to see it adopt those preferred routes more frequently and maybe learn them a little faster.
Certain Highway Behaviors
Highway travel is the most consistent and perhaps FSD’s best use case. There is nothing better than having FSD handle busy highway traffic or just long, monotonous, and boring drives. I love to use it for my trips to the Flight 93 Memorial where I volunteer. When I drove manually, I chose to get a hotel and stay overnight because it’s about a 2.5 hour drive. FSD lets me make the drive, put in a volunteering shift, and drive home, without much fatigue. I have found that this is where FSD is most valuable for me, personally.
However, there are a few things FSD does on the highway that are just weird.
One thing I’ve had issues with as of late is that there will be times when I’m about a mile from my exit, the car is in the left lane and is traveling faster than the traffic in the cruising late. Instead of completing a pass and then getting over with no traffic ahead, the car will sometimes drastically and suddenly slow down, switch to the slow lane, and get behind a vehicle — all with a mile until the exit. On average, I’ll have around one minute from the time I get to my exit if it’s a mile away, because in most cases, I’m traveling somewhere around 60 MPH on the highway.
There is no reason to not complete that last pass, then get into the right lane, and have an unobstructed path to the exit. This is one of the more strange behaviors I’ve seen it do, and it really does feel like a bug. Here’s an example of it from FSD v14.3.7:
🚨 Tesla FSD v14.3.7 did nearly the exact opposite — nearly 2.5 miles before the exit it got over into the slow lane and got behind much slower traffic.
Now, v14.3.8, anecdotally, waited til the last minute to get off the highway https://t.co/Lc9vAKDyQC— TESLARATI (@Teslarati) August 29, 2026
I ended up overriding the turn signal and using the accelerator to nudge the car to do what I wanted it to do. There was no reason to get in the left lane and add to the congestion in that lane.
Another thing that FSD does frequently is camps in the left lane, especially on Hurry. Cruising in the passing lane is illegal in Pennsylvania, and I know it is not a crime to do that everywhere. However, it is here, and I really wish the car was a little quicker to get over in the left lane when it’s cruising.
Here’s a pretty drastic example I had just a couple weeks back:
Recognizing Drastic Changes in Road Condition
I think anyone who has ever used FSD knows that potholes are a huge issue, but so are large bumps or sudden changes in road condition. At the intersection of Kreutz Creek Rd. and Rt. 462 in Hellam, PA the roads are nearly set up as a ramp, and going over it at a speed of over 35 MPH can send your head into the glass roof, your butt off your seat, and a brace for the sudden thud that is inevitably coming when you finally touch back down again.
You can see here I tried to change Speed Profiles quickly, but I did it a tad too late:
This is that big bounce that I mentioned in the quoted post.
It’s just a tad too drastic to take at the speed FSD wants to go over it. You can see me quickly swipe down into Sloth, but I intervened. https://t.co/81Oc82ZJcZ— TESLARATI (@Teslarati) August 2, 2026
There are other roads in my area that should not be taken at even the posted Speed Limit because of the damage it could do to your car. Here’s another, where I disengaged FSD altogether:
🚨 I’ve talked in the past about my struggles with FSD when large bumps or sudden changes in sloping are approaching.
Today I tried switching down into Sloth from Standard but I did it a tad too late and I had to take over. You can see this isn’t a bump you take at 35 MPH https://t.co/f4tK13hsz1— TESLARATI (@Teslarati) September 6, 2026
The recognition of these bumps is so crucial for two main reasons: they can cause injury, and they can cause damage to the car. These are reasons why the suite is supervised and drivers should remain attentive. I could not imagine going over that bump at an excessive speed if I had back issues, or if I were older.
Potholes are rarely recognized and usually require a lead car to avoid them. I had FSD use a lead car to avoid a pretty sizeable manhole cover a few weeks back:
🚨 Interesting observation on FSD v14.3.8 – Make note of the van in front of me as it swerves out of the way of a sewer cover
FSD followed this behavior, but interestingly did not swerve for the next sewer coverWhat do we make of this? https://t.co/RO19941AIP
— TESLARATI (@Teslarati) September 2, 2026
Tesla says that there are improvements coming for potholes, so hopefully that means these bumps will also be recognized consistently.
News
SpaceX just locked up a NASA record no other U.S. spacecraft can touch
SpaceX’s Crew-13 Dragon reached the ISS in under eight hours, and NASA confirmed a record.

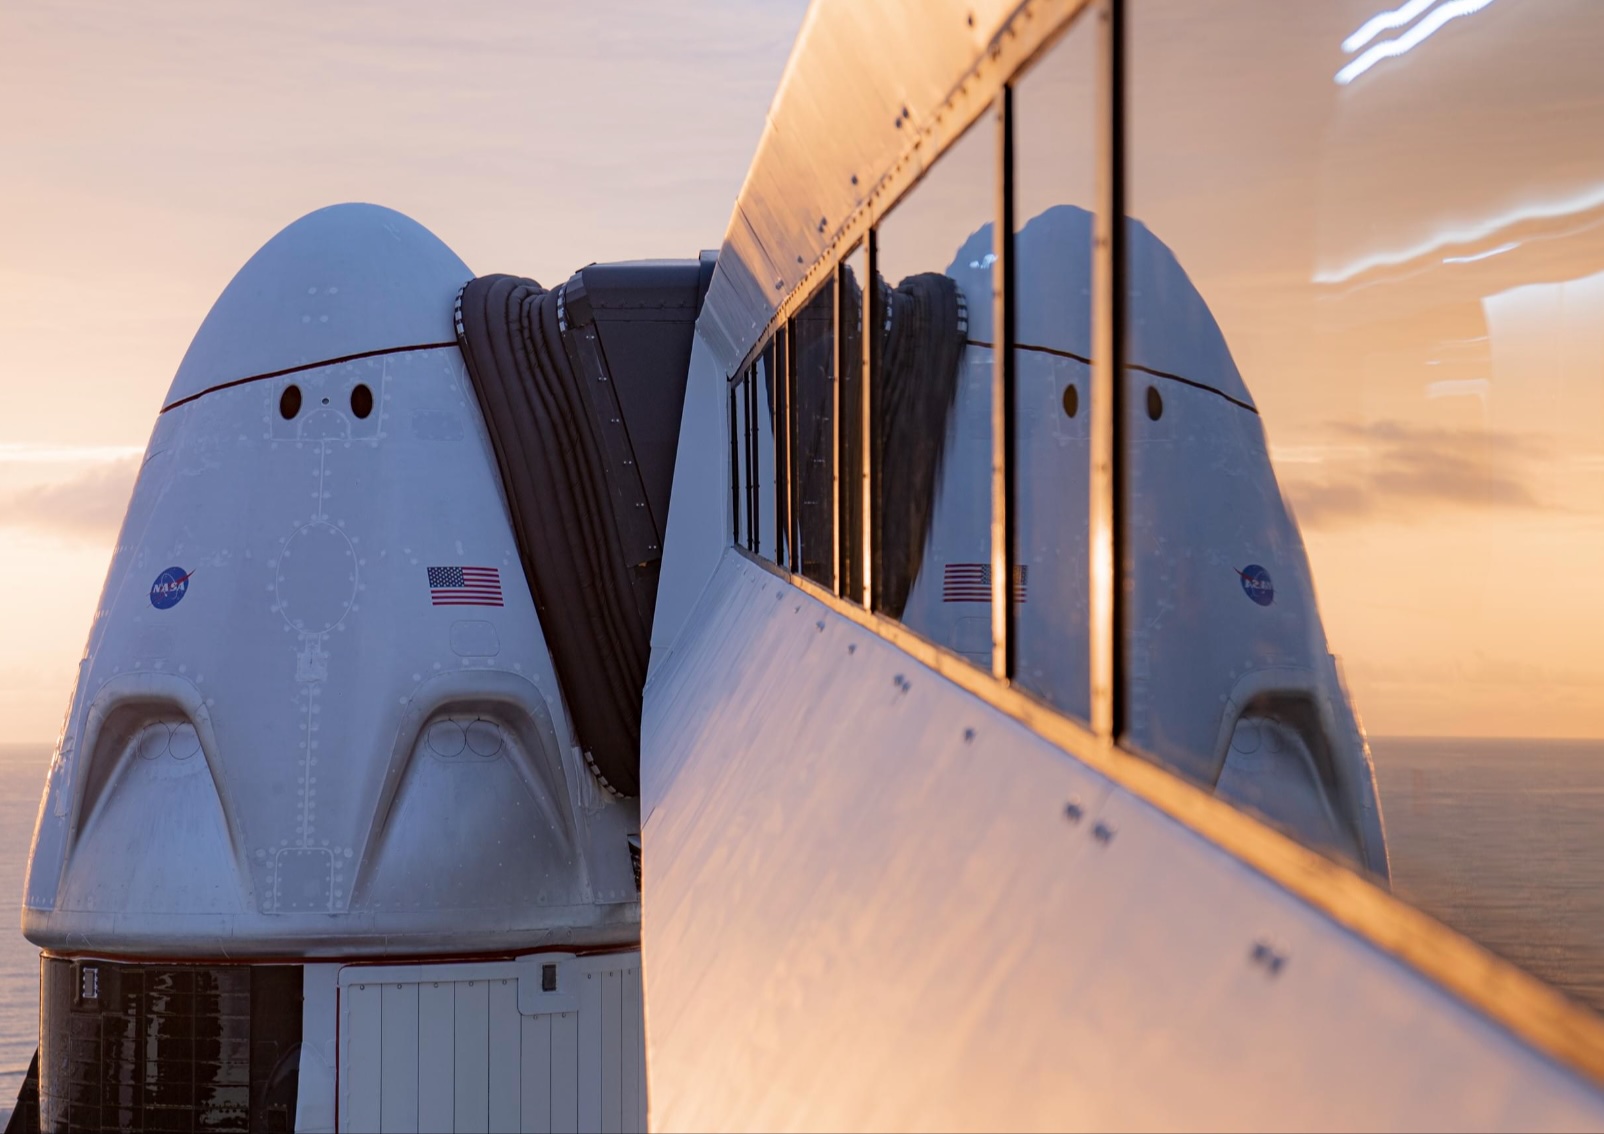
SpaceX now owns every spot on the list of the five fastest trips a U.S. spacecraft has ever made to the International Space Station, and its newest entry beat the old mark by more than four hours.
Crew Dragon Grace docked to the forward port of the station’s Harmony module at 7:05 p.m. ET on October 1, just 7 hours and 55 minutes after lifting off from Space Launch Complex 40 at Cape Canaveral. NASA confirmed the milestone in a space station blog update, writing that the flight “marked the fastest launch‑to‑docking of a U.S. spacecraft in the history of the International Space Station.”
The previous U.S. record also belonged to Dragon. SpaceX’s uncrewed CRS-31 cargo mission reached the station in a little over 12 hours in November 2024. The fastest crewed trip before last week was Crew-11, which took 14 hours and 43 minutes in August 2025, according to Space.com.
A post that Elon Musk reposted on Monday filled out the rest of the ranking. Behind Crew-13, CRS-31 and Crew-11 sit Axiom’s Ax-2 mission at 15 hours and 35 minutes and NASA’s Crew-4 at 15 hours and 44 minutes. All five flew on Dragon.
SpaceX turned a heralding moment for Starship into its greatest
Crew-13 carried NASA astronauts Jessica Watkins and Luke Delaney, Canadian Space Agency astronaut Joshua Kutryk, and Roscosmos cosmonaut Sergey Teteryatnikov. NASA had projected a docking around 8 p.m. ET, as Teslarati reported the day before launch, and Dragon arrived nearly an hour early. Our launch day coverage noted that the flight was lined up to be the quickest Crew Dragon transit yet.
The speed came from timing more than hardware. SpaceX’s Julianna Scheiman said the station “was in an opportune spot in space,” which let Dragon start closing the gap almost immediately after reaching orbit. “This is close to the fastest it could be,” she added. Most Crew Dragon flights still take close to a day, using a series of Draco thruster burns to raise and phase their orbit before arrival.
Dragon’s next job at the station is a departure. NASA said Monday it is targeting 8:05 a.m. ET on Wednesday, October 7, for Crew-12 to undock, setting up a splashdown off the coast of California around 11:34 a.m. on Thursday. Clearing that port makes room for CRS-35, a cargo Dragon carrying the final set of iROSA solar arrays.
Dragon remains NASA’s only operational ride to the station while Boeing’s Starliner stays grounded, and the agency recently added Crew-15, Crew-16 and Crew-17 to SpaceX’s contract in a $946 million modification.

Elon Musk has acknowledged that early discussions with Taiwan Semiconductor Manufacturing Company (TSMC) could bring the company into his ambitious Terafab semiconductor project, signaling a possible partnership with the world’s leading contract chipmaker.
Musk confirmed that early talks are underway, but as of right now, they are “just discussions.” There is no confirmation of a deal nor dismissal of the possibility of one, leaving open the prospect of one of the largest advanced-chip collaborations under discussion in the U.S.
@wholemars Just discussions, but something may come of it
— Elon Musk (@elonmusk) October 3, 2026
The report that speculated on potential discussions between Terafab and TSMC comes from Tim Culpan, who outlined a few ways the collaboration could operate. One is TSMC using the project as an “anchor customer” for future facilities in Texas, potentially contributing process expertise, operational know-how, or capacity while Terafab provides capital, long-term purchase commitments, or both.
Tesla and SpaceX jointly developed the Terafab project, with Intel already participating on the tech side. Elon Musk announced the project in March, and it intends to produce more than one terawatt of AI compute capacity annually once fully built.
Company statements place the first phase at approximately $16.8 billion in cost, with later filings pointing to a total that could reach well into the tens of billions across multiple stages.
Intel joined the effort in April 2026 and is expected to supply its 14A manufacturing process for the full-scale plant.
Musk has said existing suppliers, including Samsung and TSMC, remain important for near-term needs; Tesla already has production arrangements with Samsung for AI5 and AI6 chips, but that future demand from Optimus robots, Cybercab vehicles, and planned space-based data centers will eventually exceed what the global industry can currently deliver.
Terafab is positioned as the long-term answer to that projected shortfall, and Tesla did something similar during COVID to avoid a chip shortage. This is just a much larger-scale solution.
If the partnership were to materialize, it would add TSMC’s industry-leading strategies to a project that already combines Tesla’s and SpaceX’s capital and offtake with Intel’s process technology. For now, the only public confirmation is Musk’s brief acknowledgement that conversations are occurring.

Tesla Full Self-Driving: five things that are keeping FSD supervised

SpaceX just locked up a NASA record no other U.S. spacecraft can touch


