
News
Rivian’s full self-driving suite is designed to ignore an inattentive driver’s input

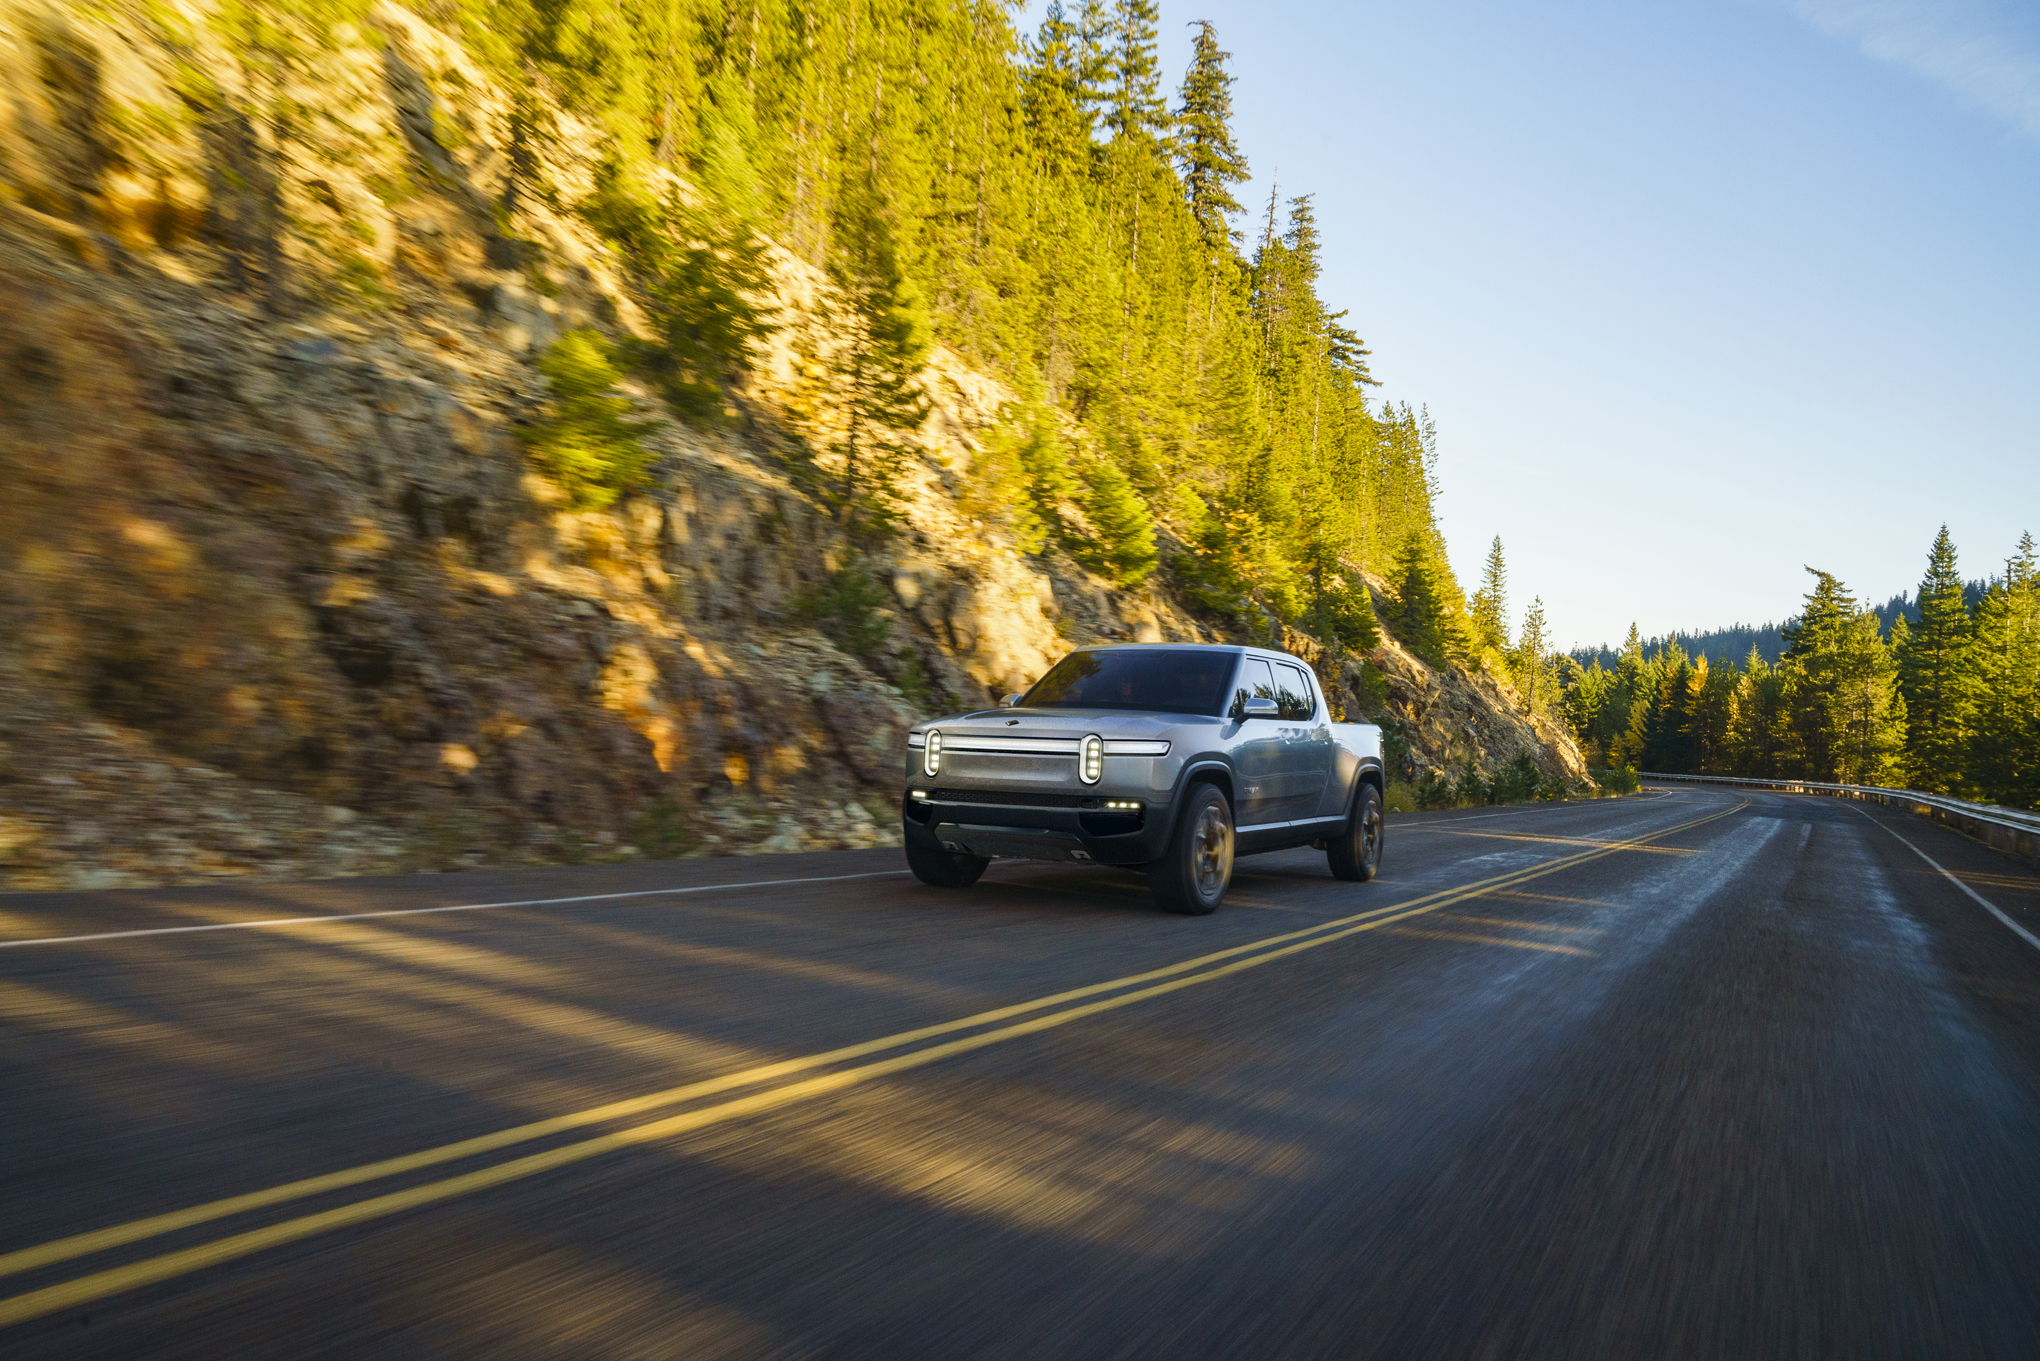
Rivian’s CEO RJ Scaringe has teased Jurassic Park-style self-driving tours with the company’s all-electric R1T pickup truck and R1S SUV several times now, but specific details on the car maker’s autonomy approach have been few and far between. Oliver Jeromin, Rivian’s Associate Director of Self-Driving, recently shed some light on the matter during an interview with TechCrunch.
“We want to embrace the challenge,” Jeromin said in response to a question over Rivian’s goal of bringing Level 3 autonomous driving to its vehicles versus other approaches. “There are mobility companies that are working on Level 4, and they’re looking at it kind of from the top down, coming from 4 or 5 for more fleet applications possibly… We want to get a feature into our customers hands sooner than possibly some of those other systems might be fully vetted,” he said.
Rivian’s electric lineup will enable this type of self-driving capability using a suite of cameras, radar, ultrasonic sensors, high-precision GPS technologies, and two cleverly-placed LiDAR. Such features are similar to those found in Tesla’s cars for the same purpose; however, where the two companies differ at the moment is notable. Rivian’s system is being developed to have a two-part monitoring system determining its full self-driving suite’s behavior based on driver input rather than a single requirement for hands to be on the steering wheel.
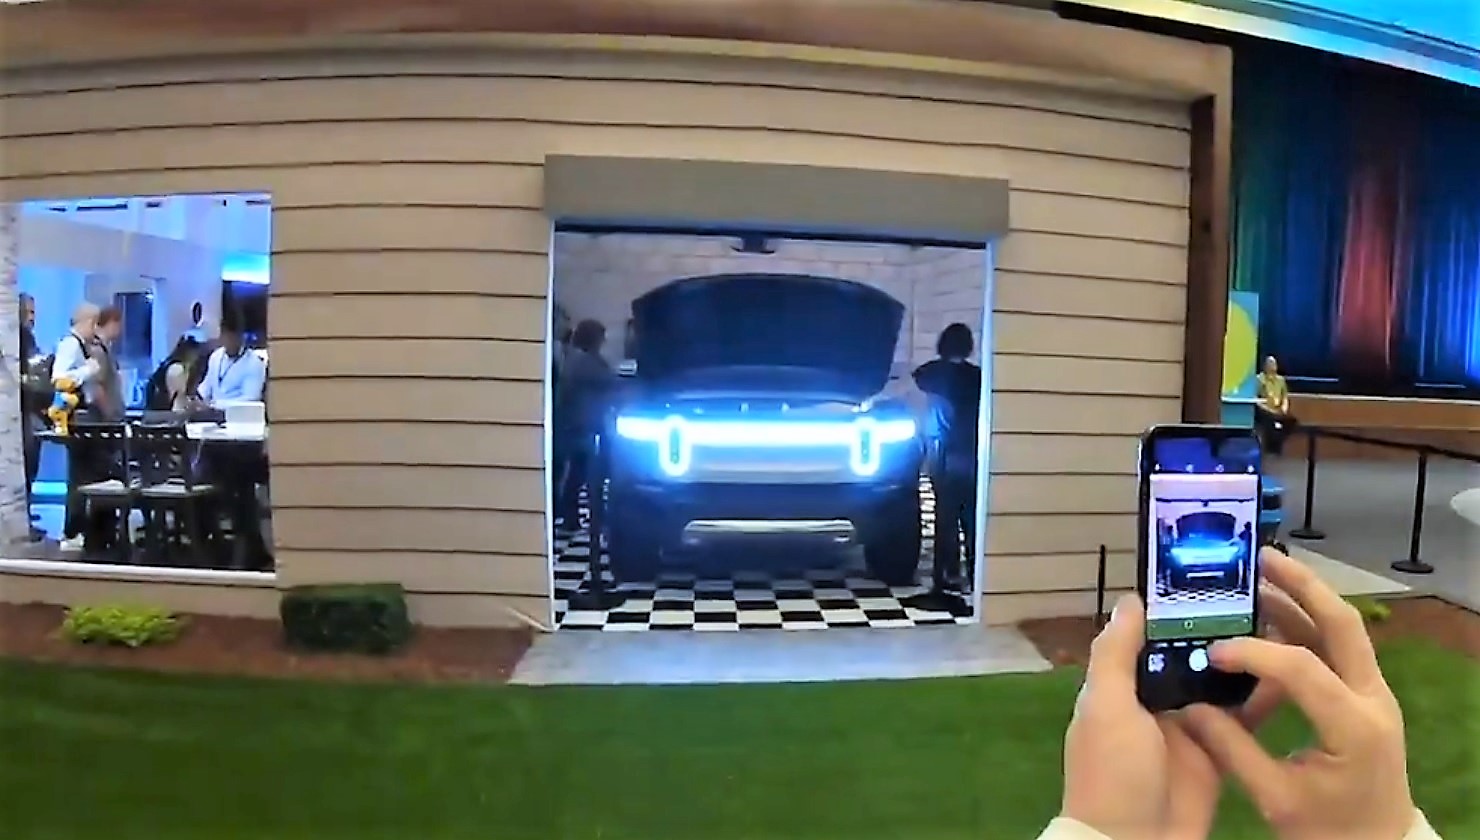
“We’re building a driver-monitoring system so it’s not just one sensor like a torque input sensor – like if a driver actually wants to disengage the longitudinal and lateral controller,” Jeromin explained. “There going to be a driver-monitoring camera, and there’s also going to be hands-on wheel sensors.”
In other words, Rivian’s full self-driving system will ignore driver input unless it is determined to be intentional. A Level 3 self-driving system can handle most aspects of driving, so if a driver wants their vehicle to behave differently than its programming is carrying out, the car will use the camera and sensors in the cabin to determine whether to proceed. If, say, the wheel is bumped from the driver shifting around in their seat for some reason, the safety procedures will know it was an accident.
“It’s really trying to determine the driver’s intention because if…you inadvertently give the steering input to the steering controller…the driver monitoring camera will see that you’re not looking at the road, and you also don’t have both hands on the wheel,” Jeromin clarified. “So, we’ll have to ignore that input from the human to understand that they’re not intending to change lanes. They’re actually just doing something else while the vehicle is in control.”
Tesla has also installed cameras to monitor activity in vehicle cabins, but the purpose isn’t exactly to monitor the driver’s intentions. Rather, Tesla Network passengers will be recorded to ensure any damages caused can be remedied. “It’s there for when we start competing with Uber/Lyft & people allow their car to earn money for them as part of the Tesla shared autonomy fleet. In case someone messes up your car, you can check the video,” CEO Elon Musk replied on Twitter to a Tesla owner’s inquiry about the tiny camera inside the rear view mirror. “Also, it can be used to supplement cameras on outside of vehicle, as it can see through 2nd side windows & rear window…Only external cameras are being used right now, so internal is not enabled. When it is enabled, we’ll add a setting to disable internal camera.”
As Rivian continues to develop its manufacturing process to bring the R1S and R1T to market, it will be interesting to also see what differences and similarities the car maker will have with other companies working on full self-driving vehicle software. Tesla has billions of miles in Autopilot-driven customer data to use for training of its self-driving program, so perhaps Rivian will eventually share its plan to close the gap.
Watch TechCrunch’s full interview with Rivian’s staff below:


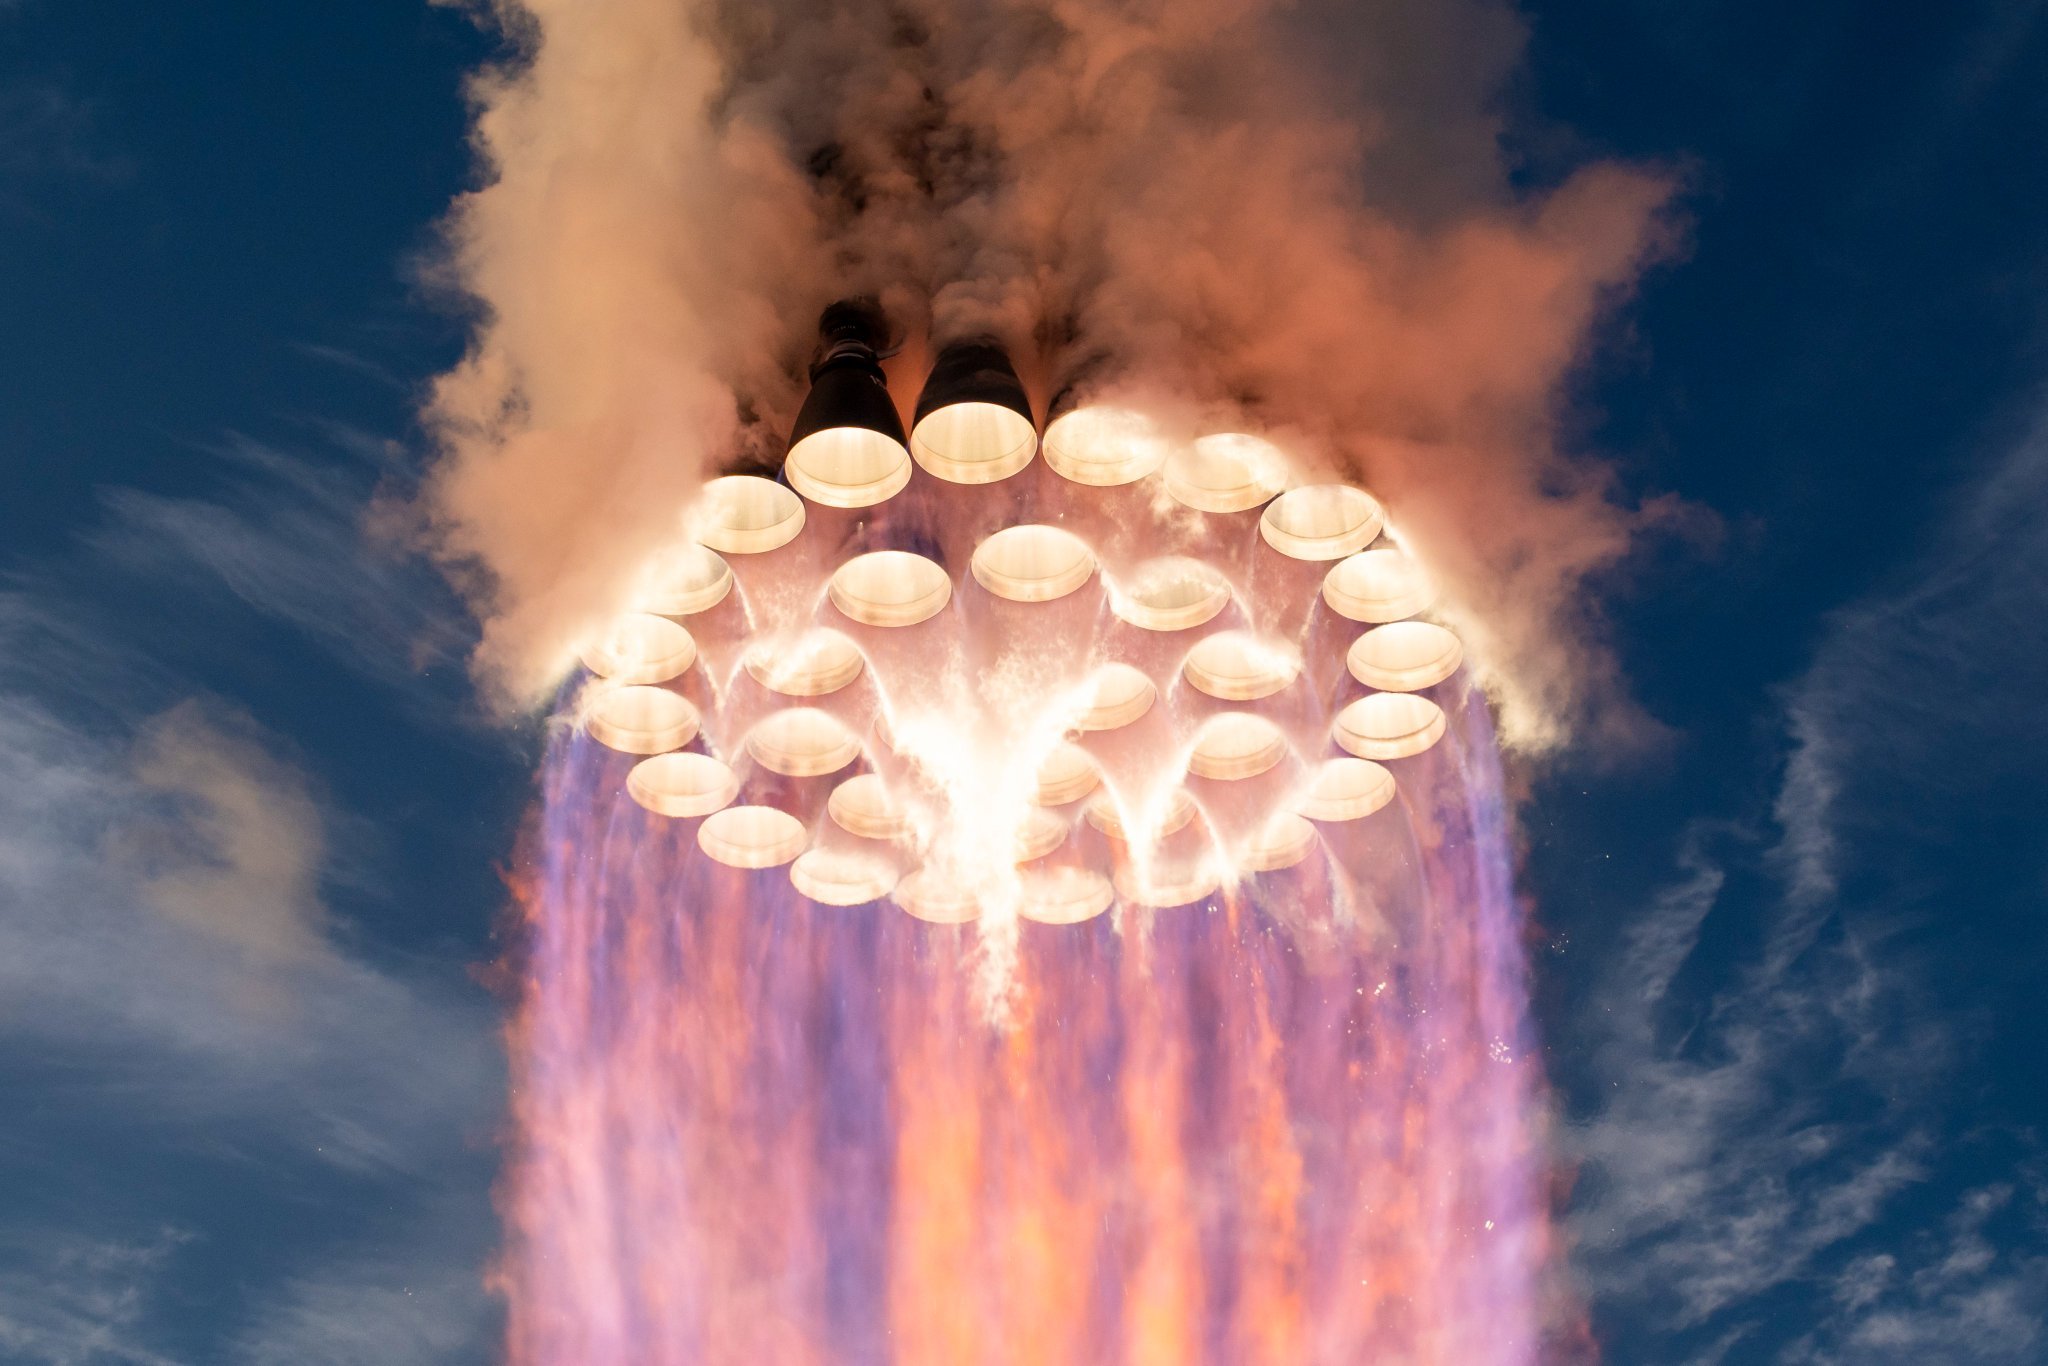
SpaceX’s Raptor engine family has steadily increased sea-level thrust while simultaneously reducing mass, turning iterative engineering gains into substantially higher performance for the Super Heavy booster. CEO Elon Musk shed more light on how powerful Raptor 4 will be, and it’s pretty crazy.
Raptor 1 delivered 185 metric tons of thrust at roughly 2,080 kilograms, while Raptor 2 raised that to 230 tons while cutting mass to about 1,630 kilograms. SpaceX data for Raptor 3 lists a target of 280 tons at 1,525 kilograms (with further reductions in associated vehicle hardware), while operational flight ratings have been cited near 250 tons.
This morning, Elon Musk stated that Raptor 4 is expected to reach 300 tons of sea-level thrust at roughly the same mass as Raptor 3. Across these versions, thrust has risen by more than 60 percent from the first engines while engine mass has fallen, producing a sharp improvement in thrust-to-weight ratio. This is a true testament to how great SpaceX engineering has been:
🚀 Elon says Raptor 4 will make 300 tons of thrust at sea level at roughly the same mass as Raptor 3.
How far Raptor has come:
Raptor 1: 185 tf, 2,080 kg
Raptor 2: 230 tf, 1,630 kg
Raptor 3: 250 tf, 1,525 kg
Raptor 4: 300 tf33 on Super Heavy = ~9,900 tf, nearly 3x Saturn V https://t.co/HQDswZhyvL
— TESLARATI (@Teslarati) October 26, 2026
With 33 engines on SuperHeavy, the jump from earlier versions to a 300-ton Raptor 4 would produce roughly 9,900 metric tons of total liftoff thrust, nearly three times the Saturn V’s approximately 3,400 metric tons from its five F-1 engines.
This is not just a larger number on a data sheet, either, as sea-level thrust is the force available the moment the vehicle leaves the pad. This is when it is heaviest and still deep in Earth’s gravity well and dense atmosphere.
Higher levels of sea-level thrust directly improves the initial thrust-to-weight ratio of the full stack. A higher ratio produces faster acceleration off the pad, which shortens the time the rocket has to spend fighting gravity, and gravity losses during the first minute or two of the flight are a major drain on total available delta-v. Every second shaved off of that early climb preserves more propellant energy for reaching orbital velocity or for carrying extra payload.
Because Super Heavy’s engine count is constrained by vehicle diameter and packing density, increasing thrust per engine is the most straightforward way to raise total liftoff performance without redesigning the booster structure or design.
The same-mass target for Raptor 4 is equally important. Holding engine mass roughly constant while raising thrust improves the engine’s own thrust-to-weight ratio and reduces the structural and propellant mass fraction that must be carried solely to support the engines.
Earlier Raptor iterations also simplified or eliminated extensive vehicle-side hardware such as heat shields. These gains compound: more force for less installed mass leaves additional capacity for propellant, payload, or operational margins such as engine-out capability.
For Starship’s architecture, the practical effects are large. Greater liftoff thrust supports heavier vehicles, larger propellant loads, and higher payloads to low Earth orbit, figures SpaceX has targeted in the 100-plus-ton reusable range. That capacity underpins orbital refueling, lunar missions, and eventual Mars cargo and crew flights.
Continued growth in sea-level thrust therefore tightens the gap between theoretical rocket performance and the high flight rates and reusability needed to make large-scale space transport practical.
Tesla has expanded its Tesla Assisted Driving (TAD) suite to its tenth European country, as Latvia joined a growing list of European Union member states authorizing the company’s advanced driver assistance technology.
Tesla Europe announced this morning that the system is now approved in Latvia, with a software rollout to begin soon.
The approval and rollout follow recognition of a provisional European type approval originally granted by the Netherlands’ RDW authority on April 10.
🚨 Latvia has just received approval for Tesla Full Self-Driving (Supervised)
This is the 10th country in the EU to gain approval:
1. Netherlands — 10 April 2026 (original RDW approval)
2. Lithuania — 20 May 2026
3. Estonia — 29 May 2026
4. Denmark — 9 June 2026
5. Belgium — 10 June 2026
6. Slovenia — 7 September 2026
7. Czechia — 21 September 2026
8. Croatia — 29 September 2026
9. Slovakia — 16 October 2026— TESLARATI (@Teslarati) October 26, 2026
Latvia’s Road Traffic Safety Directorate (CSDD) evaluated the Dutch documentation, coordinated with the other national authorities, and reviewed updates from Tesla. These included tightened limits on speed offsets, automatic resets of any manual speed adjustments after each trip, and stronger driver monitoring.
In Europe, the feature is marketed as Tesla Assisted Driving after a recent rule change that labeled the name “Full Self-Driving” as misleading.
The system remains an SAE Level 2 driver assistance tool, not unsupervised autonomy. It can control speed, steering, braking, lane changes, and intersections while following a navigation route. Drivers need not keep their hands on the wheel at all times, yet they must continuously monitor the road and be prepared to intervene immediately.
The sequence of EU recognitions began with the Netherlands in April and continued through Lithuania, Estonia, Denmark, Belgium, Slovenia, Czechia, Croatia, and Slovakia. Most have relied on mutual recognition of the single Dutch provisional approval rather than independent national testing.
These national clearances do not yet constitute bloc-wide authorization. An EU-wide decision requires a qualified majority in the Technical Committee on Motor Vehicles: at least 15 of 27 member states representing 65 percent of the EU population. Larger markets, like Germany, France, and Italy, remain under review, and a vote is expected this December.
However, for Latvian Tesla owners with compatible vehicles and software, the imminent rollout expands access to the supervised system while underscoring that attentive human oversight remains essential.
Tesla expanded its Robotaxi geofence in Houston, Texas, today, enlarging the service area and drawing a new rocket-shaped boundary across the city’s northwestern and central parts.
Although CEO Elon Musk said it was just a coincidence, the expansion seems to be an ode to SpaceX and its potential merger with Tesla.
🚨 Tesla has just expanded its Robotaxi geofence in Houston
It looks a lot like a rocket — we all remember the shape in Austin 🤣 https://t.co/cFOPEuiJ4u
— TESLARATI (@Teslarati) October 26, 2026
The official Tesla Robotaxi account announced the change with the lines “Houston, we have liftoff” and “Bigger service area now live,” pairing them with a map overlay.
The prior white geofence, roughly 25 square miles covering Jersey Village, Harvest Bend, and the Willowbrook corridor along U.S. 290 and State Highway 249, now sits inside a larger blue zone that stretches southeast toward Bellair and closer to central Houston.
Houston’s Robotaxi service launched on April 18, 2026, the same day as Dallas, as Tesla’s first unsupervised public expansion beyond Austin. From the start, the vehicles were Model Ys running without anyone in the front seats, booked through the dedicated Tesla Robotaxi app and open to the public inside the geofence.
Trackers measured the initial zone at about 25 square miles; by late September it had not grown substantially. Community and registry data indicated a modest local fleet of unsupervised Model Ys, while dozens to nearly 200 Cybercabs, the purpose-built, steering-wheel-free two-seaters, have been spotted staging and testing in Houston lots, though public Cybercab rides remain limited to Austin for now.
Across the broader Robotaxi program, Tesla began public Robotaxi rides in Austin in June 2025, as a small geofence and vehicles with safety monitors became available for a ride-hailing service. Later on, Tesla removed the monitors and steadily expanded the service area until it covered most of the Austin metro area.
Unsupervised Robotaxi services now run in six cities: Austin, Dallas, Houston, Miami, Orlando, and Tampa. Cumulative driverless miles reported by the company have reached several million. The Cybercab entered public service in Austin in early September 2026 and has scaled rapidly there. The company has also said that Dallas is next for Cybercab rides in November, with further cities and 24/7 hours targeted by year-end, plus fleet-operator sales of the vehicle.
Waymo also operates a fully driverless service in Houston, which has been open to the public since August of this year.
The Houston expansion continues Tesla’s pattern of starting with tightly controlled validation zones before widening coverage as real-world data accumulates, while the rocket motif on the map underscores the company’s habit of injecting visual flair into its autonomy rollout.
Riders inside the new boundary can request unsupervised Model Y trips in the Robotaxi app; exact operating hours and further Cybercab availability remain subject to app updates and company statements.

How SpaceX Is raising Raptor’s sea-level thrust while holding engine mass steady

Tesla Assisted Driving expands to tenth EU country


