News
SpaceX Crew-1 launch set for Sunday, ULA successfully launches spy satellite

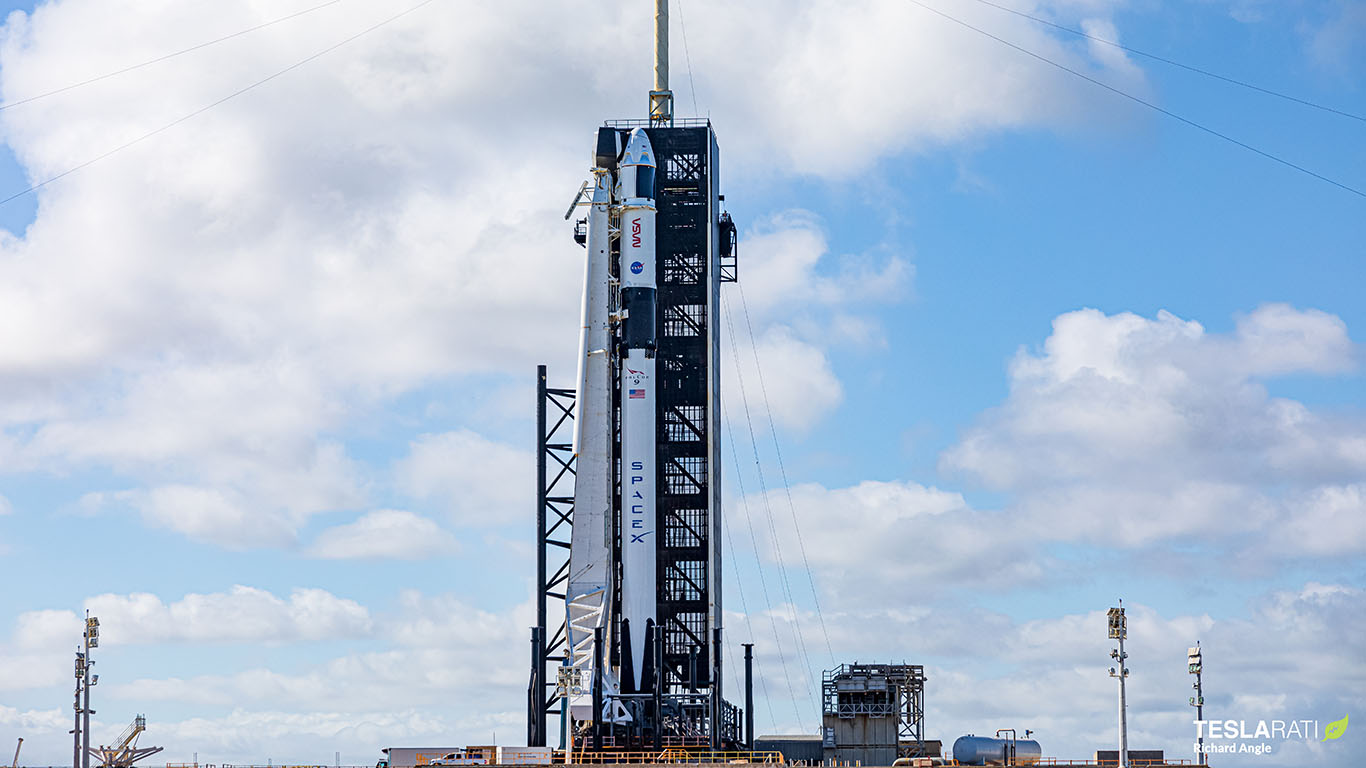
On Friday evening, Nov. 13, NASA and SpaceX announced that the first operational Commercial Crew Program mission of the Crew Dragon would be delayed 24 hours to Sunday, Nov. 15, at 7:27 pm EST (0027 GMT 11/16). During a Crew-1 pre-launch news conference, SpaceX’s senior director of the Human Spaceflight Programs, Benji Reed, stated that the delay was driven by impacts on recovery efforts caused by tropical storm Eta, which had plagued Florida for days.
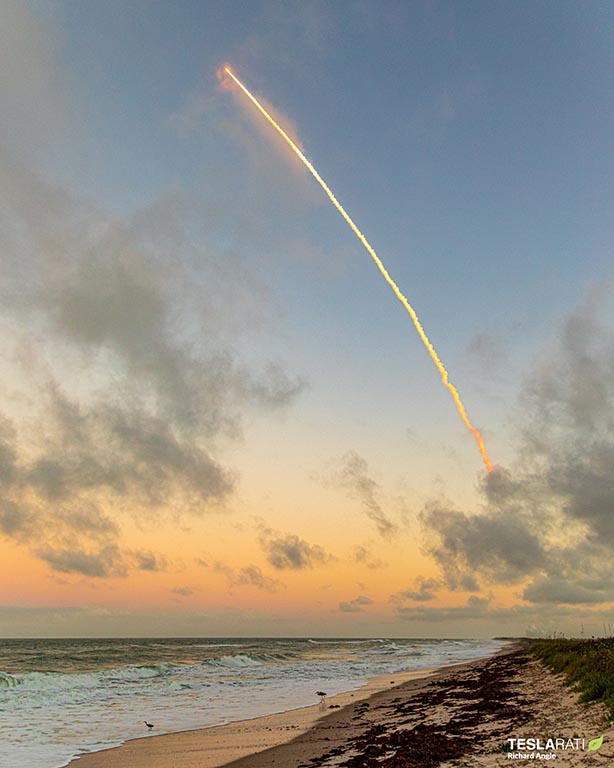
Just prior to the news conference, United Launch Alliance(ULA) successfully launched its Atlas V rocket after suffering delays of its own earlier in the week. The NROL-101 mission carried a classified payload for the National Reconnaissance Office of the U.S. government and successfully launched from Space Launch Complex 41 (SLC-41) at Cape Canaveral Air Force Station at 5:32 pm EST.
Florida weather caused multiple launch delays
Weather, especially that caused by tropical storm Eta, has caused a domino effect of delays for SpaceX and ULA over the last few weeks. The ULA Atlas V 531 rocket stacked with the secretive NROL-101 payload, initially set to liftoff on Nov. 3, was first delayed by damage sustained to environmental control system hardware of the upper stage.
According to company CEO, Tory Bruno, as the rocket was transported from ULA’s vertical integration facility (VIF) to the launchpad of SLC-41, very high winds caused damage to a duct that controlled the flow rate of an upper payload environmental control system. As a result, the rocket was returned to the VIF to have the duct replaced. A launch attempt scheduled for the following day on Wednesday, Nov. 4, was called off due to an unrelated problem with ground support equipment.
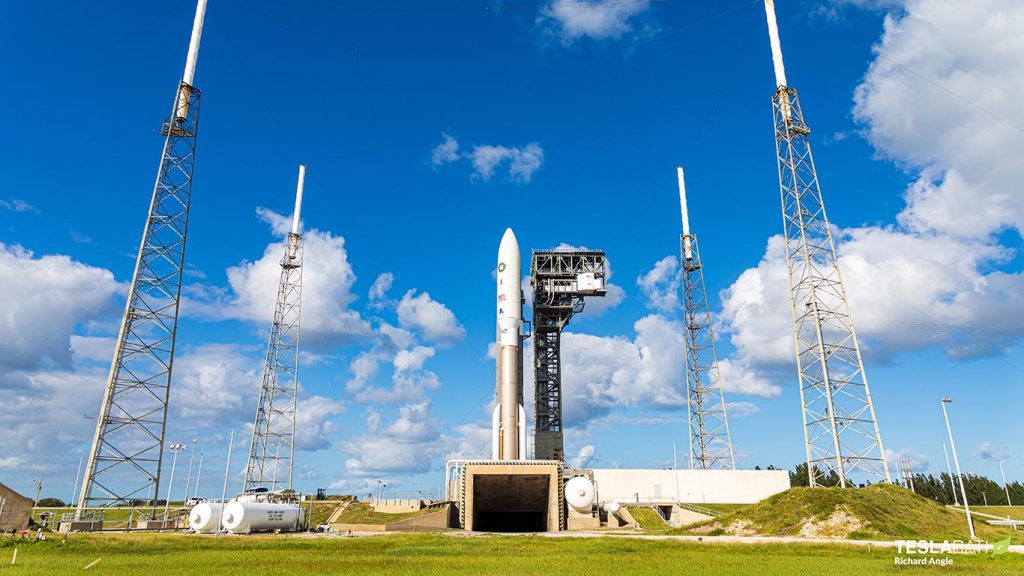
The NROL-101 mission was then set to launch on Sunday, Nov. 8, but that attempt was eventually called off due to the impending weather that would be brought across the Florida peninsula by then hurricane Eta. On Friday, Nov. 6, the Atlas V 531 rocket and payload for the National Reconnaissance Office was once again returned to the VIF for protection from the storm.
A final launch attempt was identified for Friday, Nov. 13, just 22 hours before the scheduled launch of the SpaceX, NASA Crew-1 mission from nearby Launch Complex 39A at the Kennedy Space Center. Fortunately, the weather held out long enough for the ULA Atlas V 531 rocket to liftoff. Following liftoff and successful payload deployment the mission was later declared a full success by ULA.
Florida weather also caused offshore recovery delays, impacting crewed launch
Similarly, the SpaceX and NASA Crew-1 mission has also suffered setbacks due to inclement weather, although not at the launch site. Following the successful launch and landing of the B1062 Falcon 9 of the recent GPSII-SV04 mission on Thursday, Nov. 5, SpaceX recovery teams battled unsettled seas to return the booster and the recovery droneship, Of Course I Still Love You (OCISLY), safely back to Port Canaveral.
After securing B1062 safely aboard OCISLY, the SpaceX recovery vessel GO Quest took refuge at the Port of Morehead City in North Carolina. The recovery crew would wait there to assist with the recovery of the B1061 Falcon 9 of the Crew-1 mission, rather than return to Port Canaveral in Florida. The droneship Just Read The Instructions (JRTI) was intended to meet the crew of GO Quest at the Crew-1 booster recovery zone prior to the end of the week.
Due to high winds and rough seas churned up by tropical storm Eta, the OCISLY droneship took an exceptionally tedious 7-day journey hugging the eastern coast of the United States to return to Port Canaveral. The delay caused the crew transfer process from OCISLY to JRTI to be delayed which in turn hindered the departure of the JRTI droneship.
As tropical storm Eta moved out and away from Florida the waters of the Atlantic remained too rough for the JRTI droneship to make up for the lost time. Following the conclusion of SpaceX’s Crew-1 preflight launch readiness review on Friday, Nov. 13, it was announced that the delay in getting the recovery droneship to the B1061 landing zone would delay the Crew-1 launch attempt by 24 hours.
Recovering the Falcon 9 booster, of any mission, is a secondary mission objective. However, the recovery of the Crew-1, B1061 Falcon 9 is important to both NASA and SpaceX – enough so to delay a launch attempt. NASA and SpaceX have already designated this booster to be reused on the next Crew Dragon mission, Crew-2, targeted for no earlier than March 30, 2021. In order to reuse a booster to save on launch costs, it must first be successfully recovered.
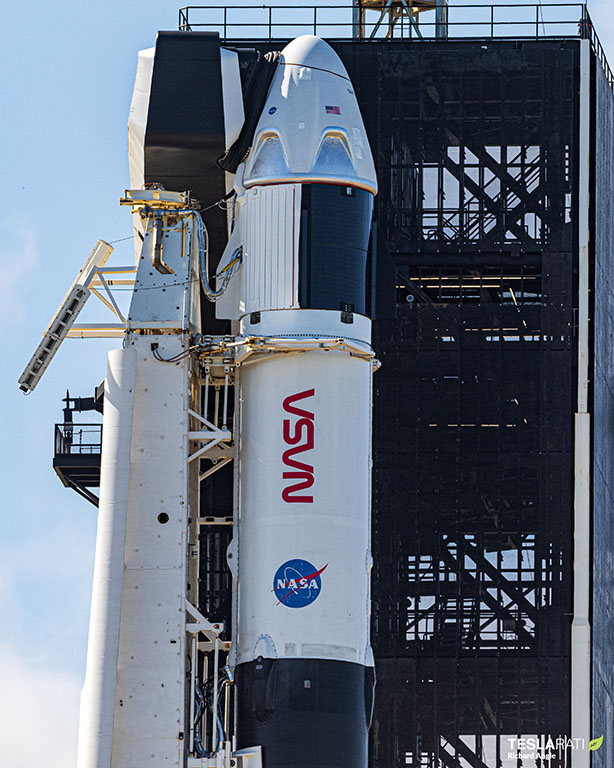
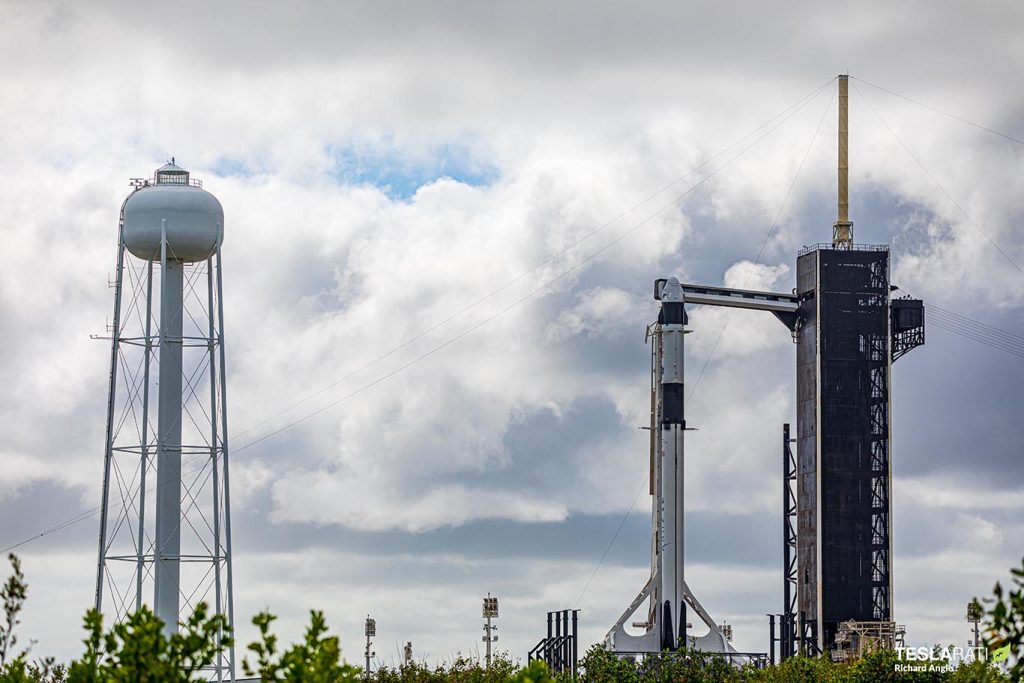
If all goes to plan, three NASA astronauts and one astronaut from the Japan Aerospace Exploration Agency will climb aboard the Crew Dragon Resilience on Sunday, Nov. 15, and blast off to the International Space Station precisely at 7:27 pm EST (0027 11/16) from LC-39A at the Kennedy Space Center.
NASA and SpaceX will provide a hosted live broadcast of all Crew-1 events beginning at 3:15 pm EST on Sunday, Nov. 15, on NASA TV and on the SpaceX website.
Check out Teslarati’s newsletters for prompt updates, on-the-ground perspectives, and unique glimpses of SpaceX’s rocket launch and recovery processes.


Tesla is now starting to ship a “Halloween Mode” that is filled with some creepy and fun features; the company says, “This spooky update turns your Tesla into a haunted house on wheels.”
The update is just the latest in a series of updates that Tesla typically ships out in a seasonal fashion. The Spring and Summer Updates provided some fun novelty items while also packing some cool features that are actually useful for the ownership experience.
This one seems to be more fun-forward, and there are not any updates to the Full Self-Driving suite or overall operation of the vehicle. Instead, these novelty features are geared toward getting you in the mood for the Fall and Halloween.
Halloween Mode now rolling out 🎃
This spooky update turns your Tesla into a haunted house on wheels
– Ghost costume on your car’s avatar
– Enable Trick or Treat to play spooky sounds & flicker the lights when visitors approach
– New haunting light show, wraps & lock sound
– A rather chilling Photobooth
– Frighten people remotely by speaking through the app…your car will say it in a voice of its own
Side effects may include neighborhood notoriety
— Tesla (@Tesla) October 6, 2026
New Ghost Costume on Car Avatar
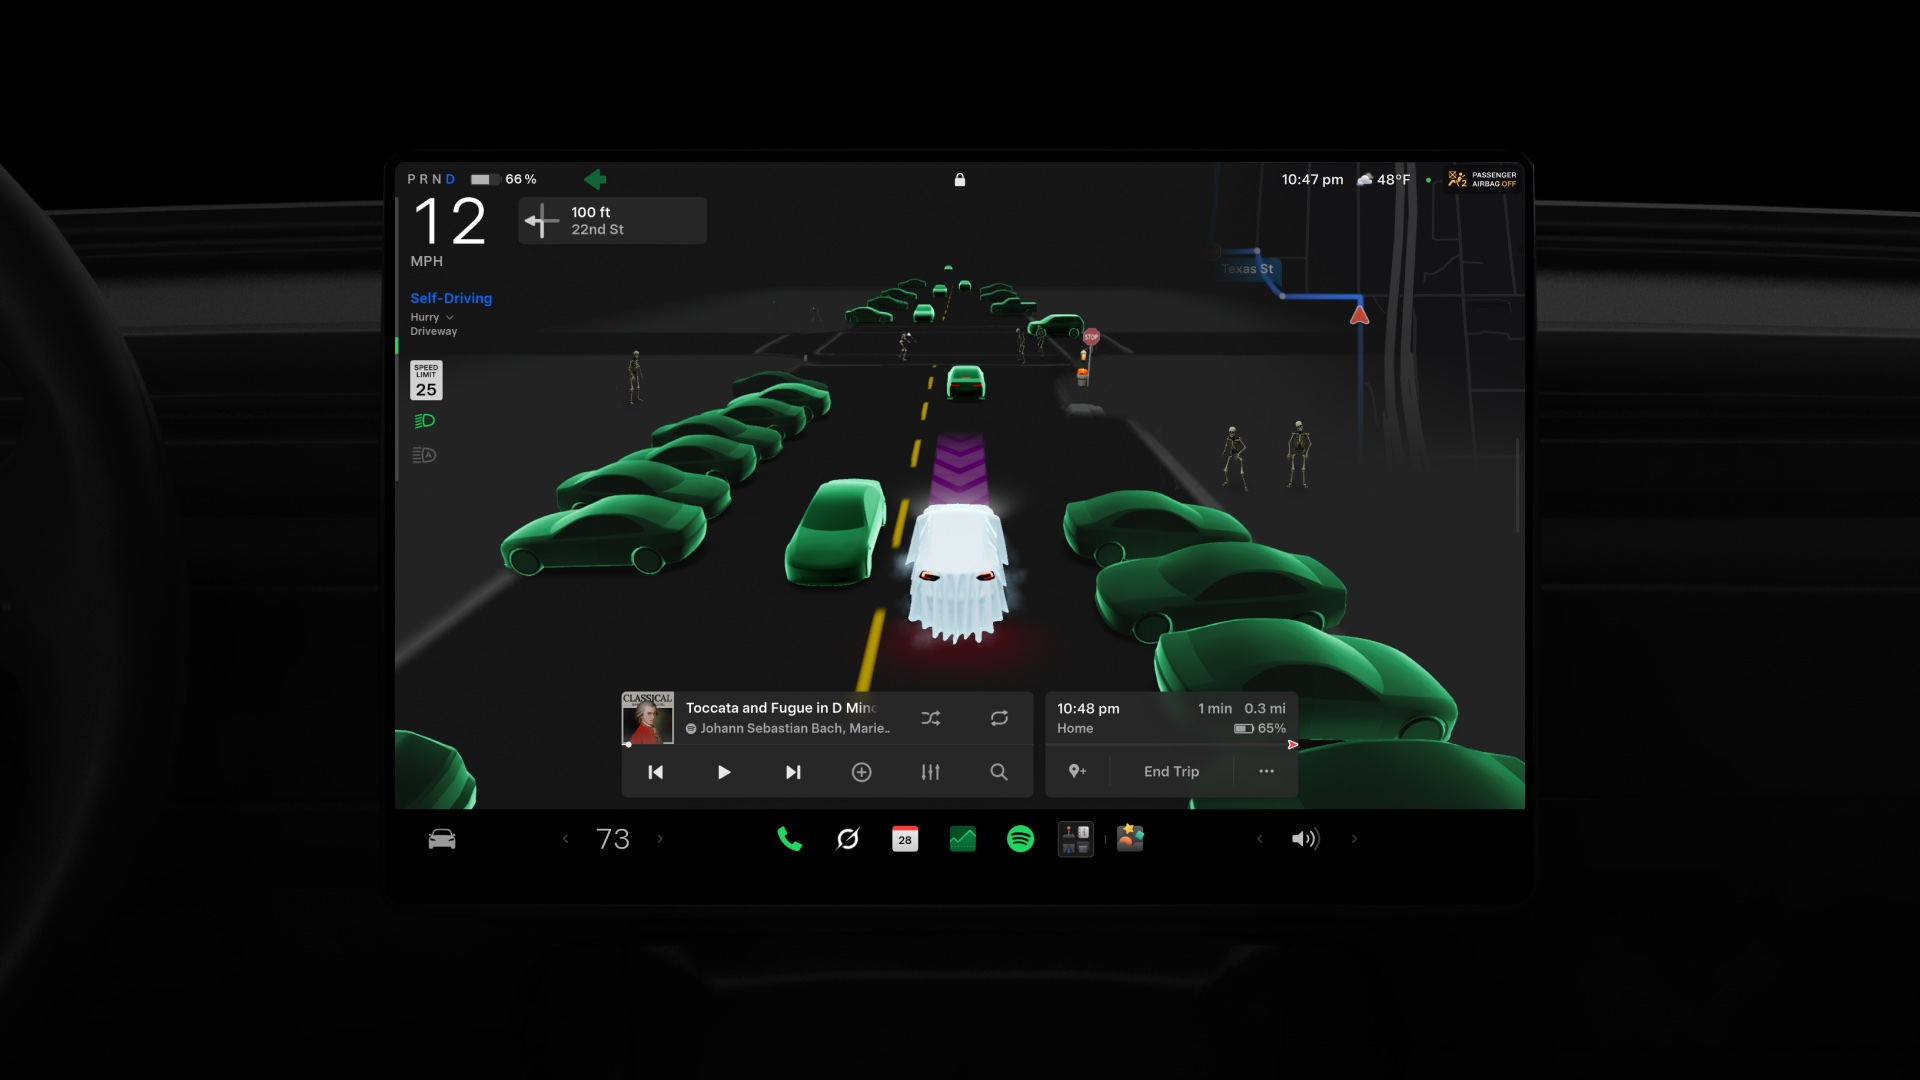
Driver Visualization will now show your vehicle as a ghost, as an all-white sheet is draped over the vehicle. Pedestrians are turned into mummies or skeletons, and other vehicles are all a spooky green:
Credit: Tesla
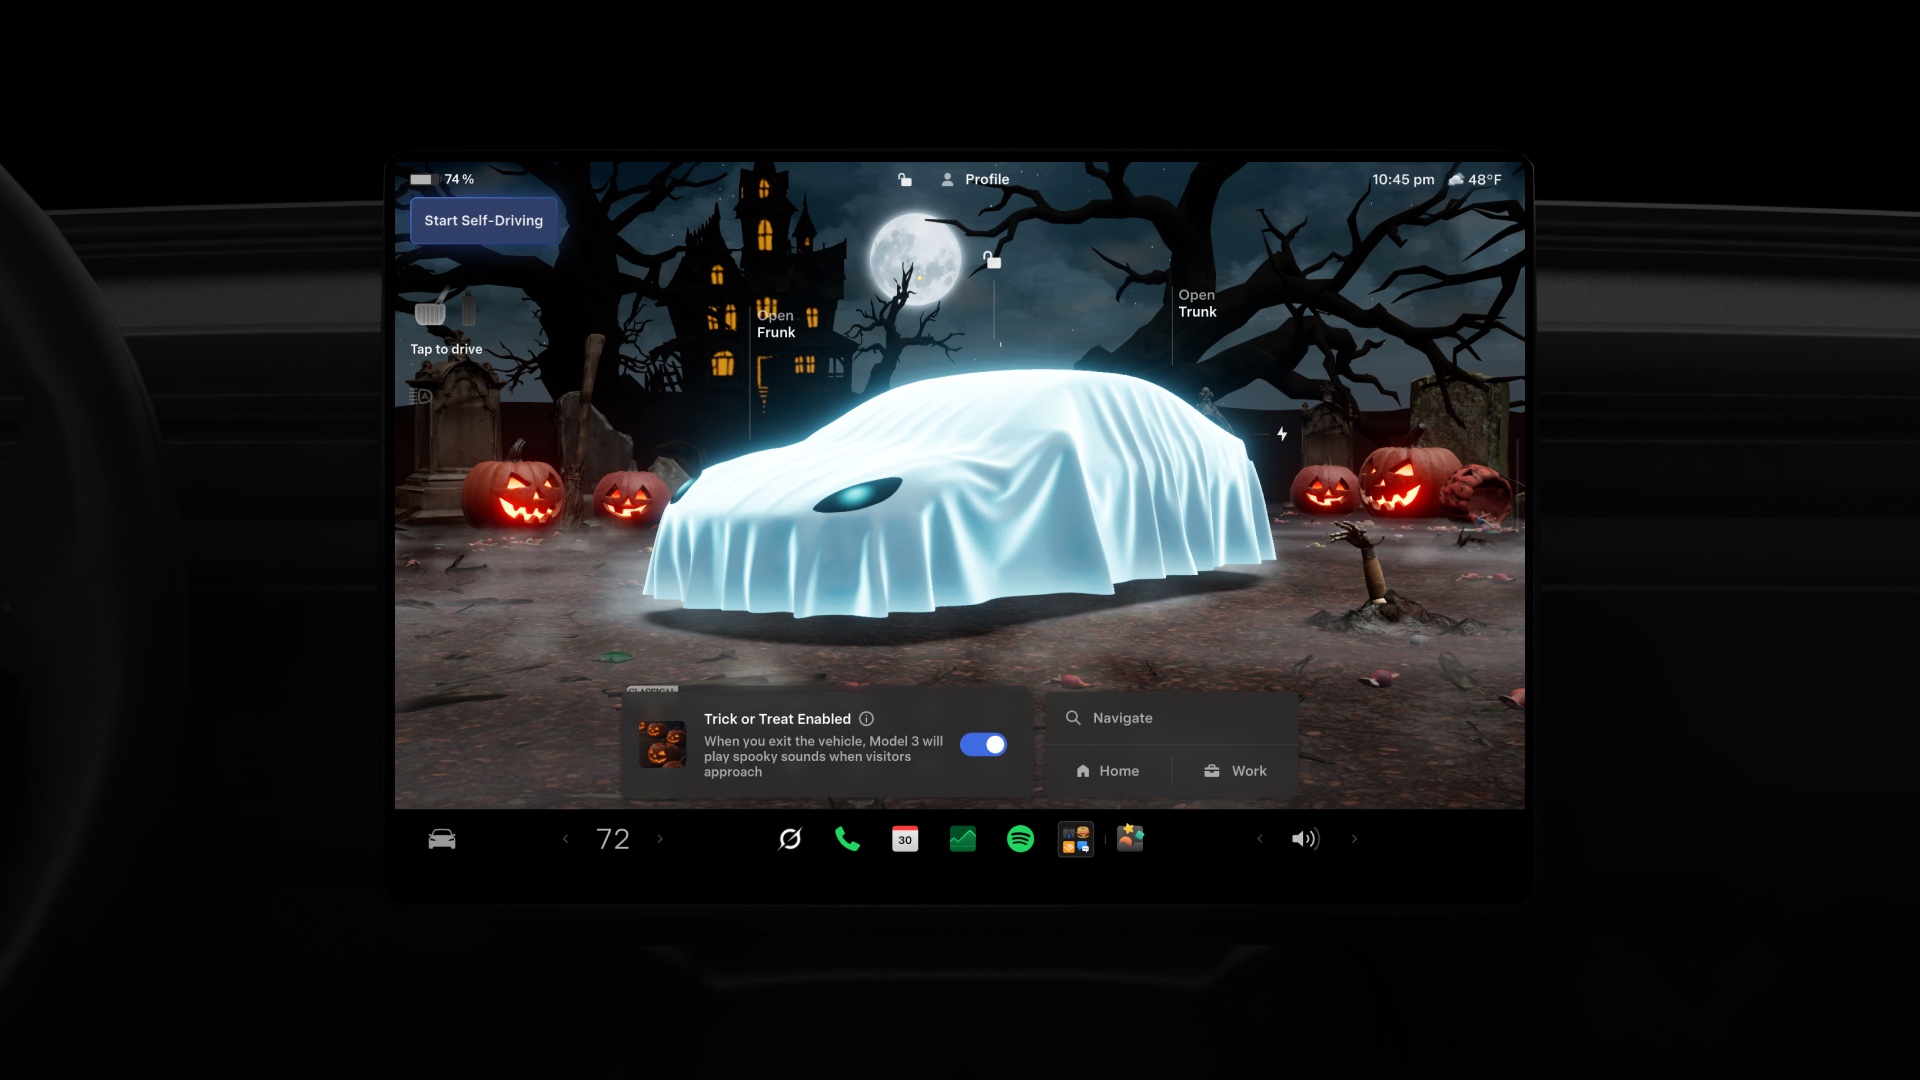
Additionally, the Park Scene with your Tesla now displays that ghost costume draped over your vehicle in the foreground of a scary backdrop with Jack-o-Lanterns and a haunted house:
Credit: Tesla
Trick or Treat Mode
Trick or Treat Mode will enable the vehicle to play spooky sounds and flicker the lights as visitors approach. This might be a nice touch for when you’re handing out candy to kids on Halloween Night.
Other Features
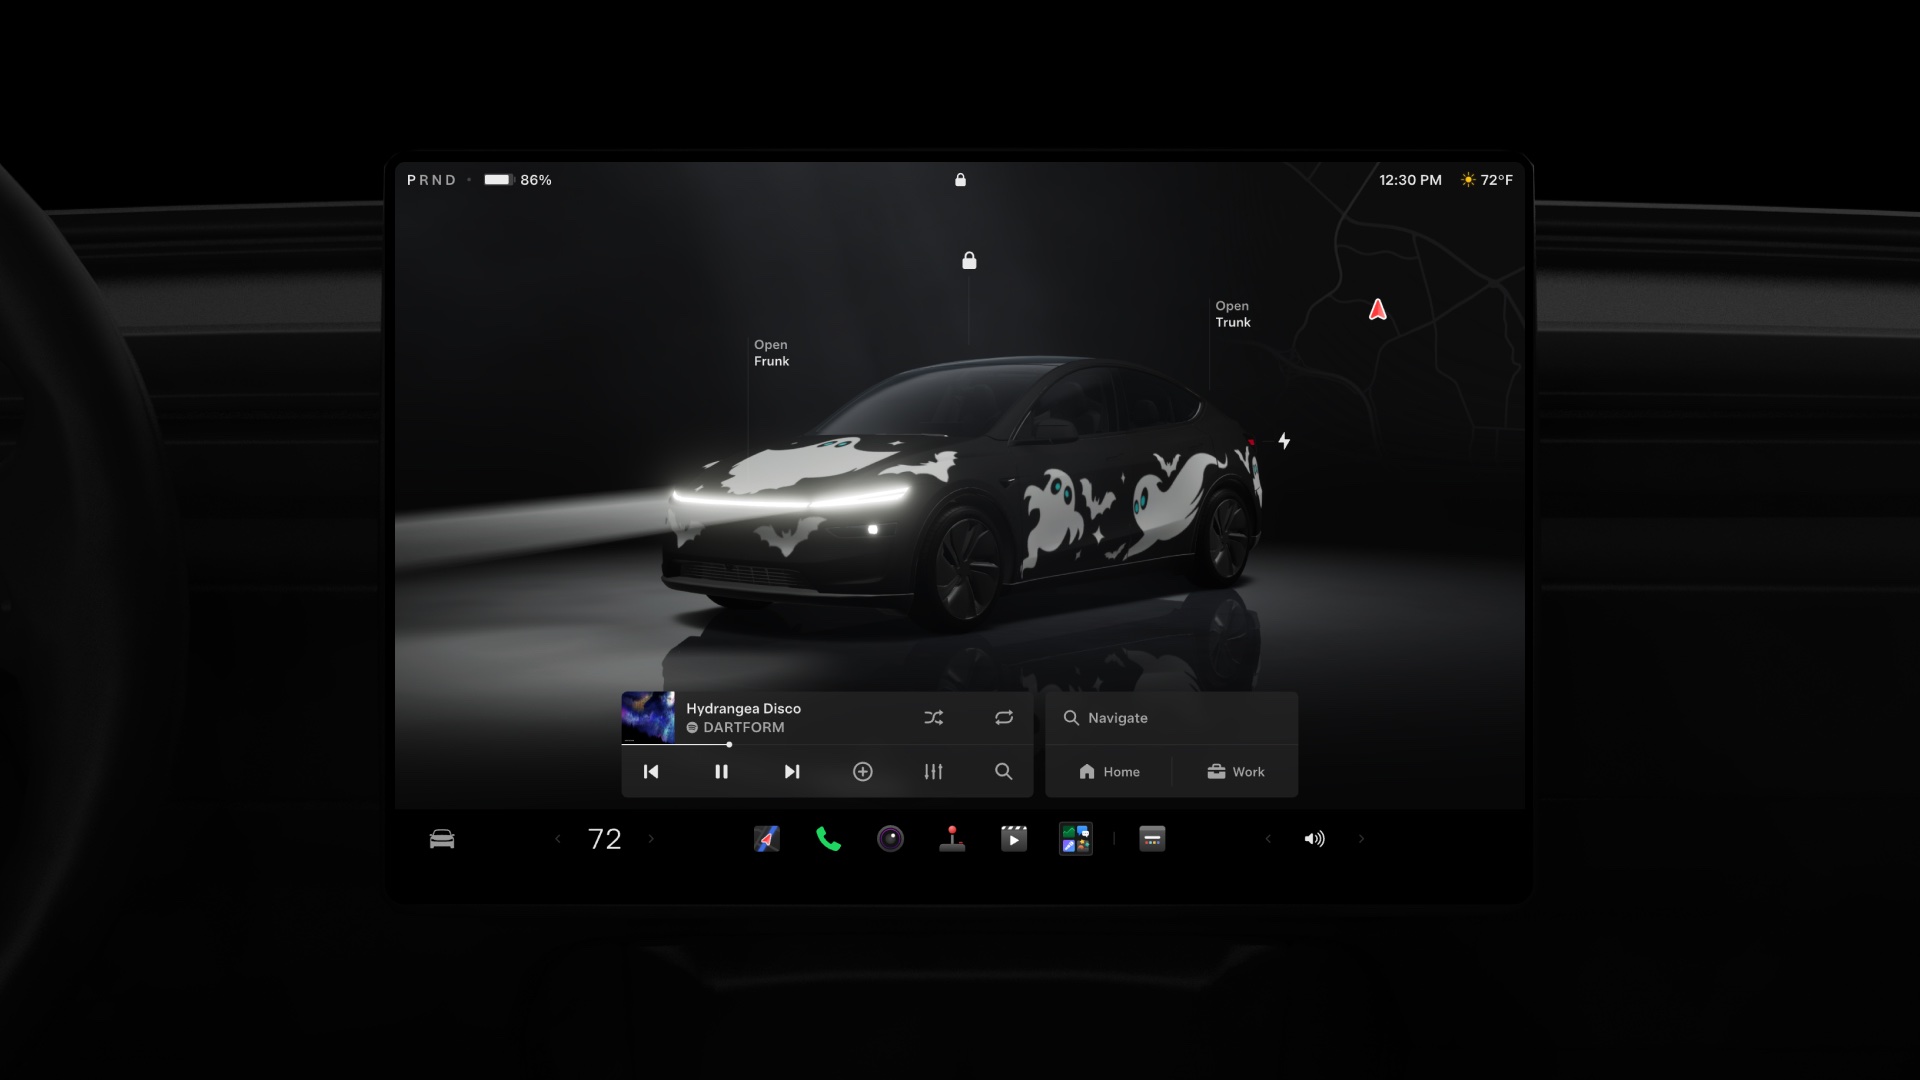
Tesla is also adding a new Light Show, new Wrap Options, and a new Lock Sound with this update.
Credit: Tesla
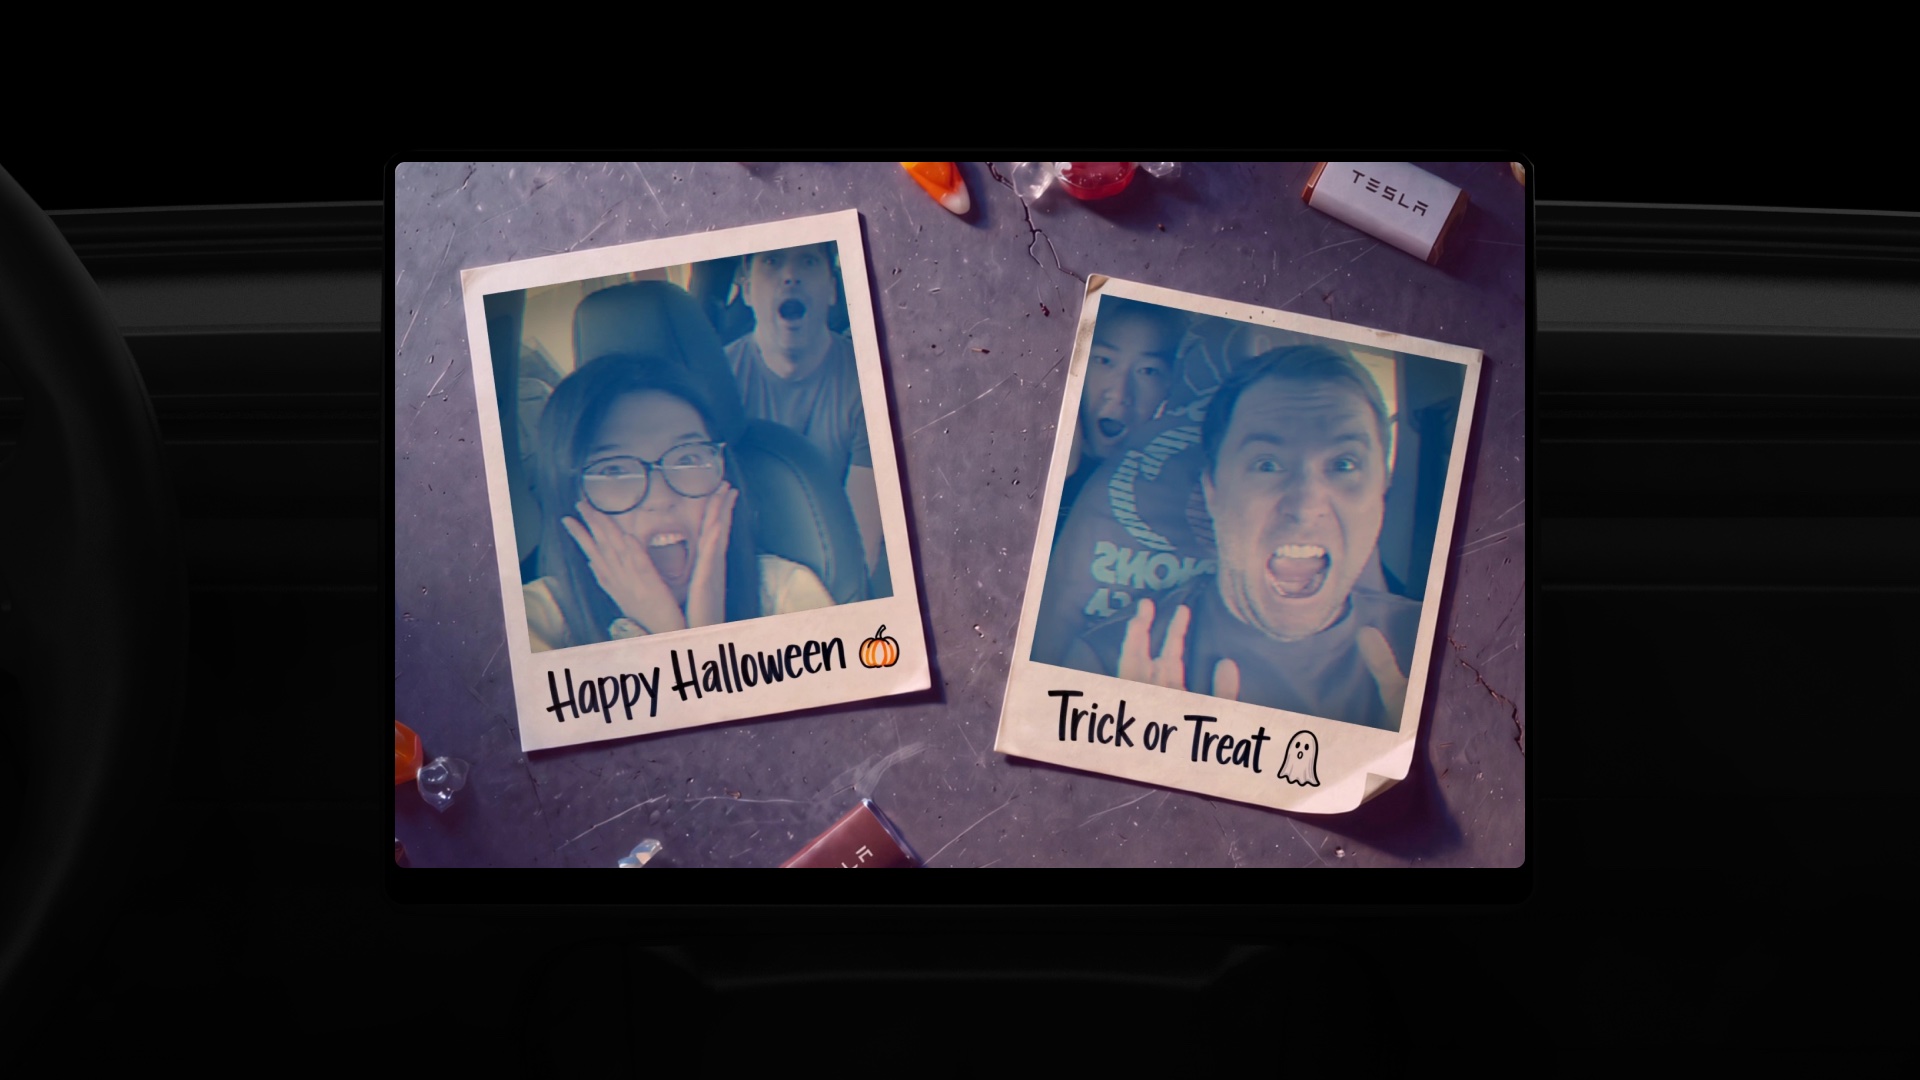
Additionally, Photobooth has a new Halloween option:
Credit: Tesla
You will also be able to speak remotely through the app and transmit your voice to people outside, which is not a new feature, but the car will say it in a voice of its own, which is a new feature with that bullhorn-like feature.
Investor's Corner
SpaceX reveals how its 1 Million AI satellite network will work and prevent space collisions
SpaceX reveals plans for one million Starmind AI satellites and calls out operators hiding maneuvers.

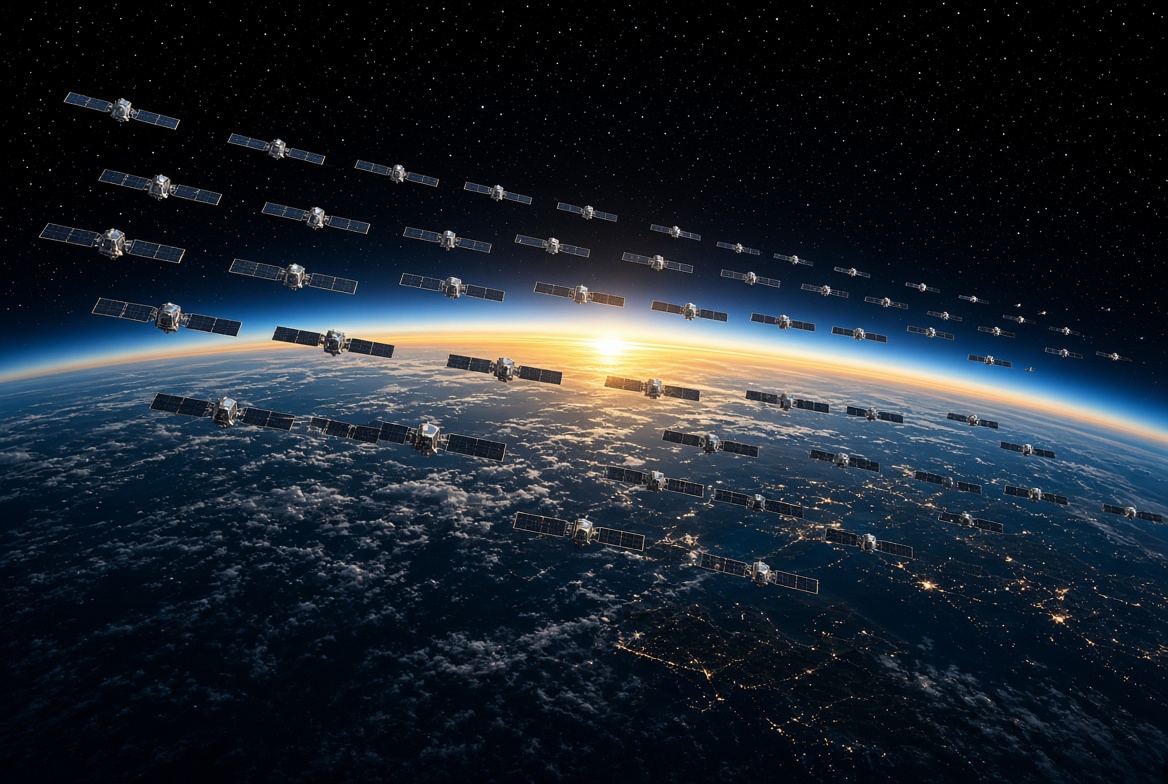
SpaceX has put the largest satellite count it has ever published into writing, and it says that plan only works if every other operator in orbit starts sharing what it knows.
In a new Space Safety page highlighted Tuesday morning by Sawyer Merritt on X, SpaceX said it “plans to operate up to 100,000 Starlink satellites and up to 1 million Starmind AI satellites to meet the growing demand for broadband and supercompute.” Starlink has a little over 11,000 satellites in orbit today, so the target alone implies roughly a ninefold expansion of the broadband network.
Starmind is SpaceX’s orbital AI compute constellation. Elon Musk confirmed the Starmind name in June after an xAI trademark filing surfaced, and in August SpaceX said it was working with Nvidia on the compute payload. The FCC accepted the filing for up to one million satellites back in February.
FCC accepts SpaceX filing for 1 million orbital data center plan
SpaceX also released a new render of what a full Starmind constellation could look like. Alongside it, SpaceX VP Michael Nicolls explained why the satellites will not operate on their own. “We need to operate clusters of satellites in tight formation to get enough coherent compute to run AI models efficiently,” Nicolls said. “A cluster will be 10-ish satellites connected with 10 terabits or so of bandwidth between them, and interconnected to the broader constellation.”
That is the most specific detail SpaceX has given on how Starmind will be built. Instead of a million independent servers, the network would work as tightly packed groups of about 10 satellites acting as one compute unit, with Starlink’s laser links carrying results back to Earth.
There is a bright and exciting future for humanity ahead – and space is fundamental to that future.
To achieve this, space safety must be done right. We encourage every operator to not only share ephemeris data proactively the same way Starlink already does, but to also adopt the high standards of space safety that SpaceX and Starlink use every day → https://t.co/QizAkQZvEm
— Starlink (@Starlink) October 6, 2026
Packing satellites that close together, at that scale, makes collision avoidance the central problem, and most of the Space Safety page is aimed at other operators. SpaceX said Starlink encountered collision risks with about 650 unique maneuvering third party satellites in 2026, and only about half of them shared data. Over six months, Starlink recorded roughly 164,000 more collision risks where the closest approach came within four hours of an unannounced maneuver.
Some operators keep maneuver plans private over proprietary concerns, while others cannot get government permission to share them. SpaceX called those policies “counterproductive,” saying they “largely only serve to create preventable collision risk between satellites.” Starlink is also offering a free ephemeris sharing and screening platform that returns risk results within a minute, backed by its Stargaze network of 30,000 optical sensors.
The push comes as the Starmind application draws opposition from astronomers and environmental groups. In a September filing with the FCC, SpaceX said each Starmind satellite could weigh up to 4,000 kg, nearly seven times the mass of a Starlink V2 Mini. Musk has brushed off crowding concerns before, telling viewers in June that “space is enormous” and that SpaceX already knows how to run very large constellations safely.
SpaceX’s Starmind page says its Gigasat factory in Bastrop, Texas, is designed to produce AI satellites at scale, with deployment of thousands of units starting as soon as late 2027.
Tesla Full Self-Driving is really good. I have used it for over 76 percent of my driving since FSD v14 launched around this time last year, equating to about 76 percent of my miles using the suite. It’s truly the only way I prefer to travel, but admittedly I save some of the more fun drives for myself.
Even with all of the great things it has done for me, including saving me from being involved in an accident, there are still a handful of things that it needs to improve on. These issues recur from update to update, and while there have been some improvements, they still give me reasons to either soft or hard intervene.
A soft intervention means an adjustment that is needed without disengaging the suite, like manually using a turn signal to change lanes while the car still operates on FSD. What I’d consider to be a “hard intervention” is anything that requires me to disengage the suite altogether, like missing a turn or performing a maneuver I’m uncomfortable with. Of course, some hard interventions will be subjective.
Here are the five things I’d like to see Tesla really focus on through the final versions of v14 and hope to see completely improved with v15.
Speed Limit Recognition and Adjustment
There are entirely too many instances of FSD traveling at a speed that is just totally outrageous. While some of these events can occur on Hurry Mode, I’ve even had issues with it on Standard from time to time, and despite wanting more aggressive maneuvers or a slight bit of urgency, I don’t want to worry about getting a ticket while doing it.
The two areas I notice it the most are in school zones and on local roads. When a Speed Limit changes from 45 to 35, FSD does not always slow down in a way that would appease local law enforcement. On Hurry, 52-55 is pretty standard for a rate of travel in a 45 MPH zone. When it changes to 35, FSD shows zero urgency to slow down to an appropriate speed.
School Zones have been a true pain point, and as recently as last week, I had an issue with it:
Threw FSD into Sloth to see how it handled this school zone. You can see well before I enter it, the car is traveling 34 MPH, one MPH under the limit.
Still not slowing down nearly enough.@Tesla_AI, not 25, not 30…15 MPH in School Zones https://t.co/YQuQ8ydhKh
— TESLARATI (@Teslarati) September 29, 2026
Realistically, most Speed Limit issues are a soft intervention, as I simply scroll into a slower Speed Profile to get the car to slow down. School Zones are a hard intervention, as they require me to completely take over and travel at the posted 15 MPH limit. Even on Sloth, it simply does not get down to a low enough speed.
Parking
Parking is one thing that has really improved over time, but there are still some pretty considerable hoops Tesla needs to jump through to get it to a point where it can be unsupervised.
Parking preferences seem to be where a lot of these issues will be resolved, as most of my complaints come from the fact that the place FSD chooses to park are usually not where I would personally choose to park. This morning, for example, when I arrived at the gym, FSD chose to park next to a vehicle that was parked with its two tires in the spot that FSD picked.
This is a big reason Parking Preferences with Supervised FSD will be so valuable.
If possible, parking a little further away and being distant from people like this is worth it. https://t.co/3Ac71KQiQ3— TESLARATI (@Teslarati) June 7, 2026
There were three spots in between that car and the nearest car, so FSD could have chosen the spot that would have given a one-spot buffer between the two vehicles. In a parking lot full of empty spots, don’t be that guy who parks next to a car.
Generally, parking performance is vastly improved from where it was a year ago; I rarely am adjusting how it pulls or backs into a spot on v14.3.10, but in earlier versions, I definitely had my problems. It’s gotten really good since, and this version has been the best in terms of parking performance. It’s more about the places FSD choose to park, and not necessarily the parking itself.
There are also no options or map data to allow you to choose a charger at a place like a grocery store if it offers charging. These are things that are a bit more complex, but they will be needed for unsupervised FSD operation.
Navigation
Navigation was always going to be on this list, simply because it is one of the most inconsistent and mind-boggling things about FSD. Even after a year of intervening, sending voice notes, and overriding decisions, FSD still tries to take me out of my neighborhood the wrong way. You cannot turn left out of my neighborhood’s main entrance and exit, only right. Navigation still prompts a left turn out of my neighborhood’s main entrance and exit, instead of going around the neighborhood and exiting where a left turn is legal.
Tesla rolled out Preferred Routes with the Summer Update, and this has resolved some of the issues. I also found my own personal workaround:
🚨See if this cool Tesla Navigation Hack works for you!
I have used it to get out of my neighborhood legally with FSD, thus enabling completely hands-free drives! https://t.co/DlDsCQjxRI— TESLARATI (@Teslarati) July 16, 2026
Some of the more mind-boggling things that FSD used to do with Navigation have been remedied, but it is still a frequent complaint for me and many other owners. I’d just like to see it adopt those preferred routes more frequently and maybe learn them a little faster.
Certain Highway Behaviors
Highway travel is the most consistent and perhaps FSD’s best use case. There is nothing better than having FSD handle busy highway traffic or just long, monotonous, and boring drives. I love to use it for my trips to the Flight 93 Memorial where I volunteer. When I drove manually, I chose to get a hotel and stay overnight because it’s about a 2.5 hour drive. FSD lets me make the drive, put in a volunteering shift, and drive home, without much fatigue. I have found that this is where FSD is most valuable for me, personally.
However, there are a few things FSD does on the highway that are just weird.
One thing I’ve had issues with as of late is that there will be times when I’m about a mile from my exit, the car is in the left lane and is traveling faster than the traffic in the cruising late. Instead of completing a pass and then getting over with no traffic ahead, the car will sometimes drastically and suddenly slow down, switch to the slow lane, and get behind a vehicle — all with a mile until the exit. On average, I’ll have around one minute from the time I get to my exit if it’s a mile away, because in most cases, I’m traveling somewhere around 60 MPH on the highway.
There is no reason to not complete that last pass, then get into the right lane, and have an unobstructed path to the exit. This is one of the more strange behaviors I’ve seen it do, and it really does feel like a bug. Here’s an example of it from FSD v14.3.7:
🚨 Tesla FSD v14.3.7 did nearly the exact opposite — nearly 2.5 miles before the exit it got over into the slow lane and got behind much slower traffic.
Now, v14.3.8, anecdotally, waited til the last minute to get off the highway https://t.co/Lc9vAKDyQC— TESLARATI (@Teslarati) August 29, 2026
I ended up overriding the turn signal and using the accelerator to nudge the car to do what I wanted it to do. There was no reason to get in the left lane and add to the congestion in that lane.
Another thing that FSD does frequently is camps in the left lane, especially on Hurry. Cruising in the passing lane is illegal in Pennsylvania, and I know it is not a crime to do that everywhere. However, it is here, and I really wish the car was a little quicker to get over in the left lane when it’s cruising.
Here’s a pretty drastic example I had just a couple weeks back:
Recognizing Drastic Changes in Road Condition
I think anyone who has ever used FSD knows that potholes are a huge issue, but so are large bumps or sudden changes in road condition. At the intersection of Kreutz Creek Rd. and Rt. 462 in Hellam, PA the roads are nearly set up as a ramp, and going over it at a speed of over 35 MPH can send your head into the glass roof, your butt off your seat, and a brace for the sudden thud that is inevitably coming when you finally touch back down again.
You can see here I tried to change Speed Profiles quickly, but I did it a tad too late:
This is that big bounce that I mentioned in the quoted post.
It’s just a tad too drastic to take at the speed FSD wants to go over it. You can see me quickly swipe down into Sloth, but I intervened. https://t.co/81Oc82ZJcZ— TESLARATI (@Teslarati) August 2, 2026
There are other roads in my area that should not be taken at even the posted Speed Limit because of the damage it could do to your car. Here’s another, where I disengaged FSD altogether:
🚨 I’ve talked in the past about my struggles with FSD when large bumps or sudden changes in sloping are approaching.
Today I tried switching down into Sloth from Standard but I did it a tad too late and I had to take over. You can see this isn’t a bump you take at 35 MPH https://t.co/f4tK13hsz1— TESLARATI (@Teslarati) September 6, 2026
The recognition of these bumps is so crucial for two main reasons: they can cause injury, and they can cause damage to the car. These are reasons why the suite is supervised and drivers should remain attentive. I could not imagine going over that bump at an excessive speed if I had back issues, or if I were older.
Potholes are rarely recognized and usually require a lead car to avoid them. I had FSD use a lead car to avoid a pretty sizeable manhole cover a few weeks back:
🚨 Interesting observation on FSD v14.3.8 – Make note of the van in front of me as it swerves out of the way of a sewer cover
FSD followed this behavior, but interestingly did not swerve for the next sewer coverWhat do we make of this? https://t.co/RO19941AIP
— TESLARATI (@Teslarati) September 2, 2026
Tesla says that there are improvements coming for potholes, so hopefully that means these bumps will also be recognized consistently.

Tesla ships ‘spooky’ Halloween Mode with creepy and fun features

SpaceX reveals how its 1 Million AI satellite network will work and prevent space collisions


