News
Stanford studies human impact when self-driving car returns control to driver

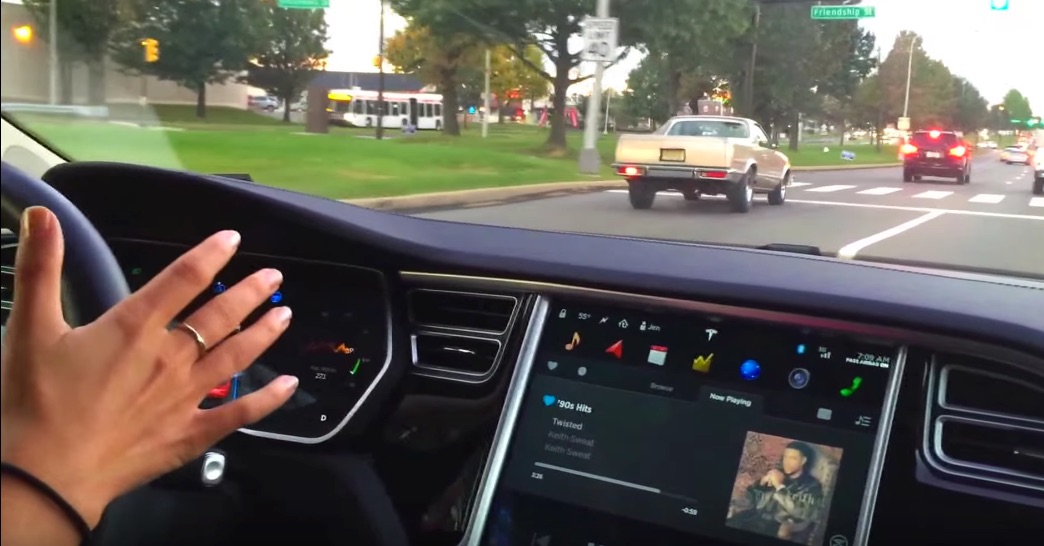
Researchers involved with the Stanford University Dynamic Design Lab have completed a study that examines how human drivers respond when an autonomous driving system returns control of a car to them. The Lab’s mission, according to its website, is to “study the design and control of motion, especially as it relates to cars and vehicle safety. Our research blends analytical approaches to vehicle dynamics and control together with experiments in a variety of test vehicles and a healthy appreciation for the talents and demands of human drivers.” The results of the study were published on December 6 in the first edition of the journal Science Robotics.
Holly Russell, lead author of study and former graduate student at the Dynamic Design Lab says, “Many people have been doing research on paying attention and situation awareness. That’s very important. But, in addition, there is this physical change and we need to acknowledge that people’s performance might not be at its peak if they haven’t actively been participating in the driving.”
The report emphasizes that the DDL’s autonomous driving program is its own proprietary system and is not intended to mimic any particular autonomous driving system currently available from any automobile manufacturer, such as Tesla’s Autopilot.
The study found that the period of time known as “the handoff” — when the computer returns control of a car to a human driver — can be an especially risky period, especially if the speed of the vehicle has changed since the last time the person had direct control of the car. The amount of steering input required to accurately control a vehicle varies according to speed. Greater input is needed at slower speeds while less movement of the wheel is required at higher speeds.
People learn over time how to steer accurately at all speeds based on experience. But when some time elapses during which the driver is not directly involved in steering the car, the researchers found that drivers require a brief period of adjustment before they can accurately steer the car again. The greater the speed change while the computer is in control, the more erratic the human drivers were in their steering inputs upon resuming control.
“Even knowing about the change, being able to make a plan and do some explicit motor planning for how to compensate, you still saw a very different steering behavior and compromised performance,” said Lene Harbott, co-author of the research and a research associate in the Revs Program at Stanford.
Handoff From Computer to Human
The testing was done on a closed course. The participants drove for 15 seconds on a course that included a straightaway and a lane change. Then they took their hands off the wheel and the car took over, bringing them back to the start. After familiarizing themselves with the course four times, the researchers altered the steering ratio of the cars at the beginning of the next lap. The changes were designed to mimic the different steering inputs required at different speeds. The drivers then went around the course 10 more times.
Even though they were notified of the changes to the steering ratio, the drivers’ steering maneuvers differed significantly from their paths previous to the modifications during those ten laps. At the end, the steering ratios were returned to the original settings and the drivers drove 6 more laps around the course. Again the researchers found the drivers needed a period of adjustment to accurately steer the cars.
The DDL experiment is very similar to a classic neuroscience experiment that assesses motor adaptation. In one version, participants use a hand control to move a cursor on a screen to specific points. The way the cursor moves in response to their control is adjusted during the experiment and they, in turn, change their movements to make the cursor go where they want it to go.
Just as in the driving test, people who take part in the experiment have to adjust to changes in how the controller moves the cursor. They also must adjust a second time if the original response relationship is restored. People can performed this experiment themselves by adjusting the speed of the cursor on their personal computers.
“Even though there are really substantial differences between these classic experiments and the car trials, you can see this basic phenomena of adaptation and then after-effect of adaptation,” says IIana Nisky, another co-author of the study and a senior lecturer at Ben-Gurion University in Israel “What we learn in the laboratory studies of adaptation in neuroscience actually extends to real life.”
In neuroscience this is explained as a difference between explicit and implicit learning, Nisky explains. Even when a person is aware of a change, their implicit motor control is unaware of what that change means and can only figure out how to react through experience.
Federal and state regulators are currently working on guidelines that will apply to Level 5 autonomous cars. What the Stanford research shows is that until full autonomy becomes a reality, the “hand off” moment will represent a period of special risk, not because of any failing on the part of computers but rather because of limitations inherent in the brains of human drivers.
The best way to protect ourselves from that period of risk is to eliminate the “hand off” period entirely by ceding total control of driving to computers as soon as possible.

News
Tesla exec hints at a wild fix for Robotaxi’s biggest weather problem
Tesla VP Lars Moravy says focused lasers could keep robotaxi cameras clear instead of wipers.

Tesla may one day use lasers instead of wiper blades to keep its robotaxi cameras clear. Lars Moravy, Tesla’s Vice President of Vehicle Engineering, floated the idea in a new episode of Jay Leno’s Garage released Monday, where he and design chief Franz von Holzhausen walked Leno through the Model Y L.
“If you fire them in a focused area, you can clean the sheet of water and create a barrier,” Moravy said. “When you think about autonomy, it might be a good solution to only clean the area where the camera is.” He added that clearing an entire windshield would take too many lasers to be practical.
🚨 Jay Leno has released a new episode breaking down the Model Y L. You can watch it here: https://t.co/umMp85UEaB — TESLARATI (@Teslarati) November 9, 2026
The comment brings back one of Tesla’s stranger patents. The company filed for “Pulsed Laser Cleaning of Debris Accumulated on Glass Articles in Vehicles and Photovoltaic Assemblies” in May 2019, and the U.S. Patent Office granted it in September 2021. An updated divisional version was granted on March 31, 2026. The system detects debris on the glass, identifies what it is, and pulses the laser at a calibrated rate so the beam never penetrates deeper than the glass itself. The filing names windshields, side windows, camera lenses and solar panels as possible targets.
Lasers were once rumored for the Cybertruck, which appeared at its November 2019 unveiling with no wipers at all. Tesla eventually settled on a single oversized blade, and Elon Musk admitted the wiper was the part of the truck that troubled him the most. That production line is now scheduled to shut down around mid 2027 to make room for more Cybercab output.
What has changed since then is who is in the vehicle. A privately owned car has a driver who can notice a smeared windshield and do something about it. A Cybercab heading to its next pickup has nobody on board to check. Tesla has been chipping away at that problem with conventional hardware. Model Y Robotaxis in Austin were spotted with washers on their side repeater cameras in January, and a lens cleaning patent granted in May describes a fluid and wiper assembly for vehicle cameras and Optimus’ eyes. A laser would remove the fluid and the blades, both of which need regular replacement across a fleet.
The same episode gave Leno his first ride on Full Self-Driving (Supervised). The Model Y L pulled over on its own when an ambulance approached with its sirens on. “We got it on self-driving mode! I’m not touching anything,” Leno said. Moravy and von Holzhausen also explained that owners remain responsible while using FSD (Supervised), while Tesla takes responsibility for Robotaxi rides because it acts as the operator. Tesla launched the Model Y L in the U.S. in July at $61,990.
Moravy gave no timeline, and he described the laser setup as something Tesla is considering rather than a confirmed feature. The fleet it would serve keeps getting bigger, though. Tesla launched unsupervised Robotaxi service in San Antonio on Monday, its eighth city, and expanded its Austin service area to roughly 443 square miles on the same day. Several of those markets, including Houston, Miami and Tampa, see heavy seasonal rain.

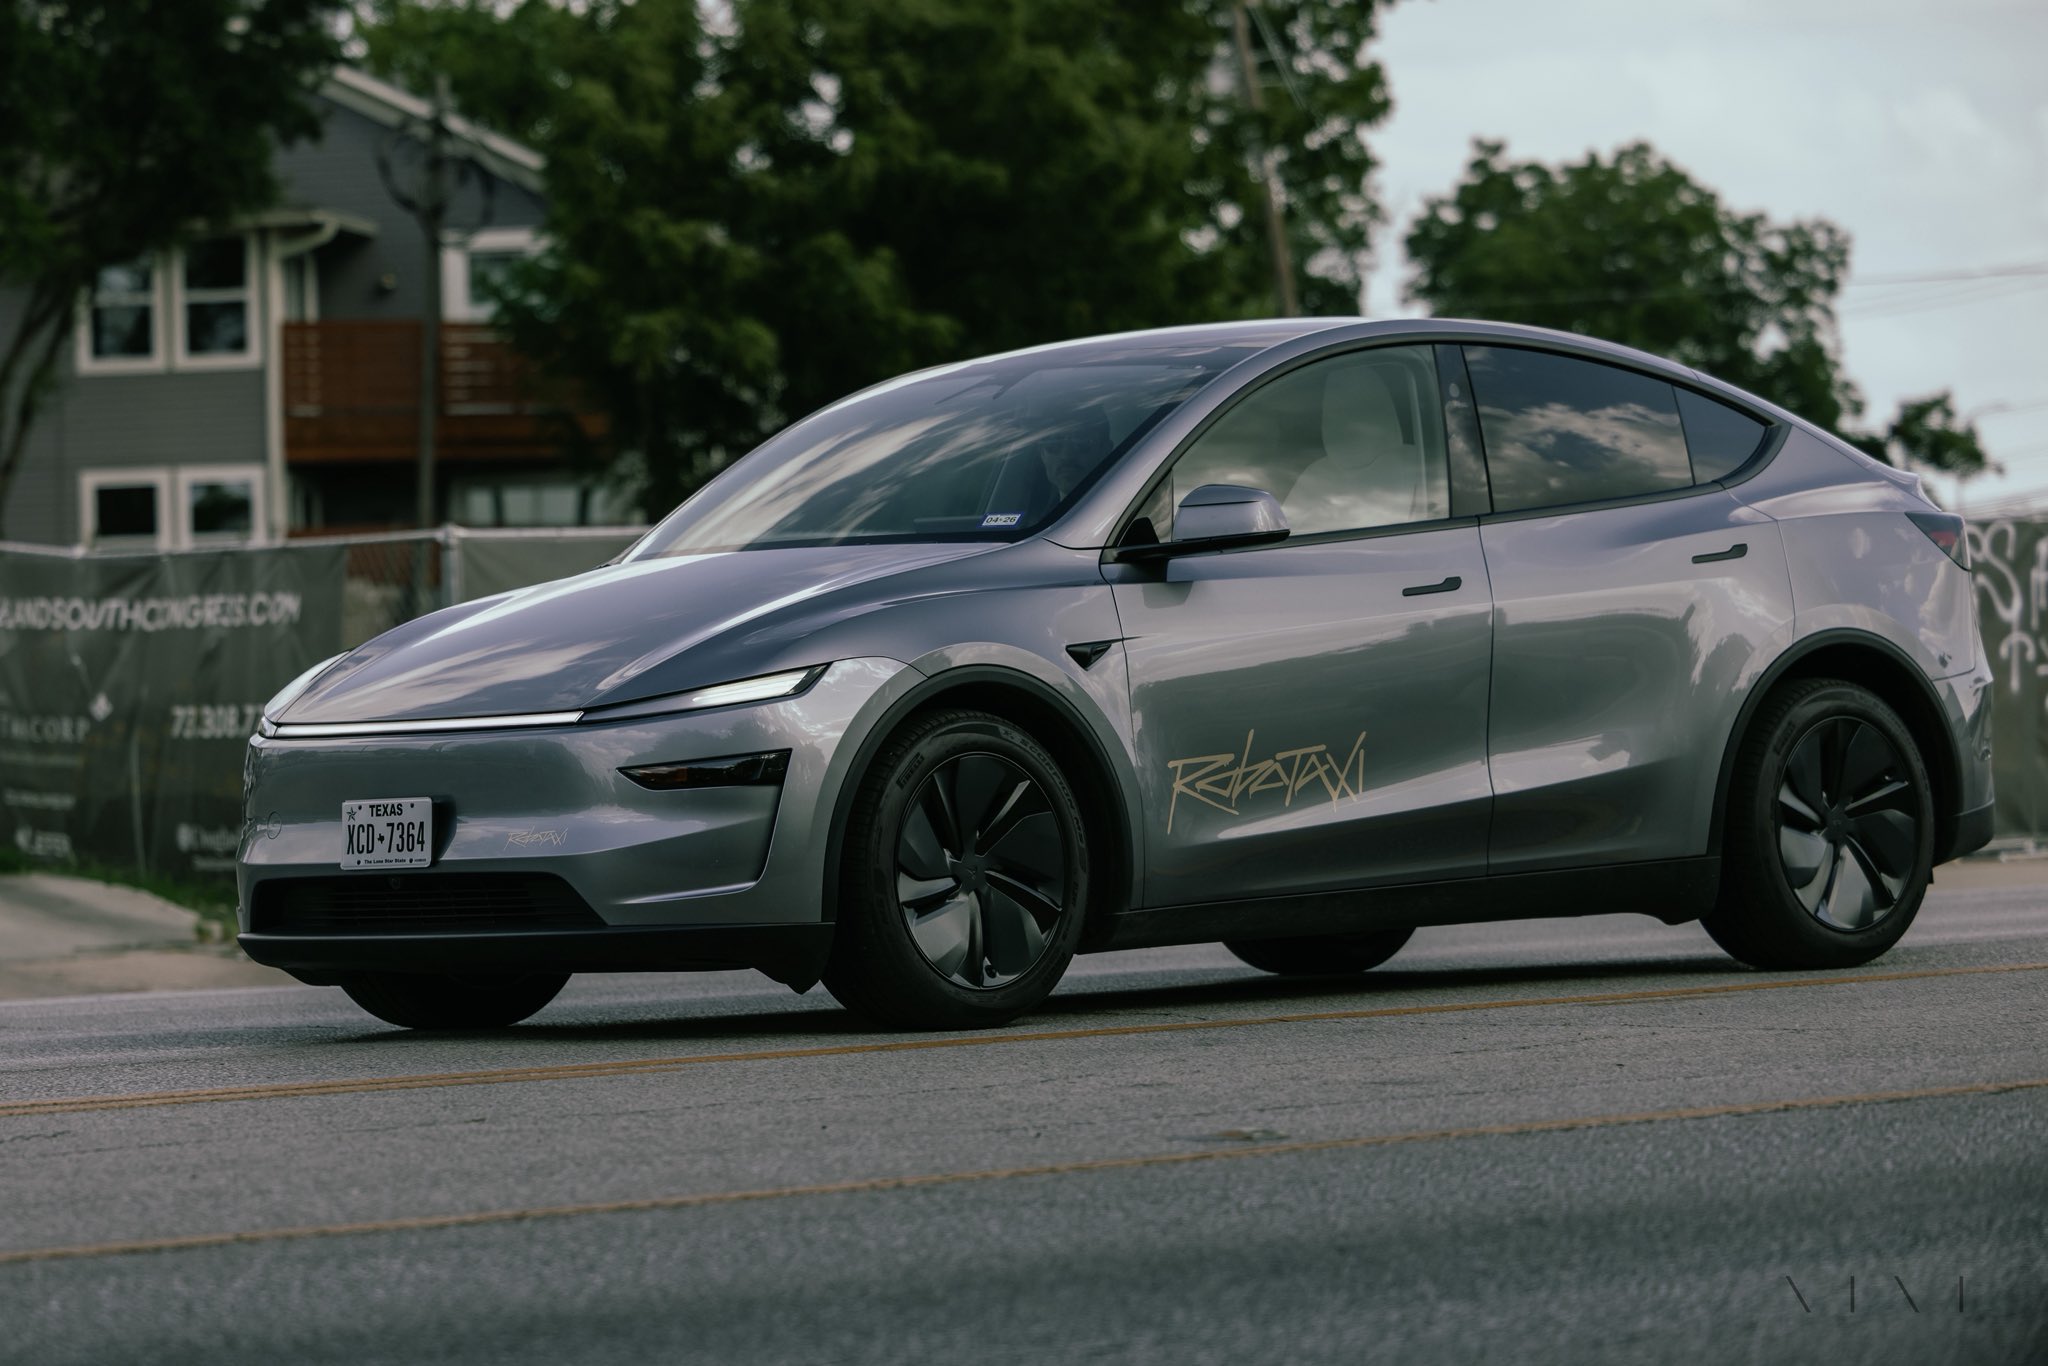
Tesla launched unsupervised Robotaxi service in San Antonio, Texas, on November 9, 2026, with the first rides beginning at 5 a.m. local time.
The company’s official Robotaxi account on X posted the announcement just after midnight, sharing a map that outlines a large operational zone covering much of the city. The geofence is roughly 274 to 275 square miles, making it Tesla’s largest day-one Robotaxi service area to date.
🚨 Tesla just announced that Robotaxi is available in San Antonio, TX
First rides at 5am local time! https://t.co/azck6NlD8H
— TESLARATI (@Teslarati) November 9, 2026
The zone centers on downtown, covers nearly everything inside Loop 410, and extends north to Loop 1604 between Interstate 10 and U.S. 281, with further reach west past State Highway 151, east beyond I-35, and south toward I-37. This area encompasses about one million residents and hundreds of thousands of jobs.
San Antonio International Airport lies inside the geofence, though Tesla is not currently offering airport pickups or drop-offs. This hopefully will happen soon, as ride-sharing to and from the airport can be expensive.
The launch makes San Antonio Tesla’s eighth unsupervised Robotaxi city and its fifth in Texas, joining Austin, Houston, Dallas, and Fort Worth. Florida markets in Miami, Orlando, and Tampa are also live.
🚨 Here’s every active geofence, by size (not including the Bay Area geofence):
• Austin: 435 sq mi (first ride Jun 22, 2025) · Cybercabs live, expanded today • San Antonio: ~275 sq mi (first ride Nov 9, 2026) • Houston: 254 sq mi (Apr 18, 2026) • Fort Worth: 143 sq mi (Nov 2, 2026) • Dallas: 81 sq mi (Apr 18, 2026) • Miami: 31 sq mi (Jul 3, 2026) • Orlando: 26 sq mi (Jul 21, 2026) • Tampa: 24 sq mi (Jul 21, 2026)
— TESLARATI (@Teslarati) November 9, 2026
Service uses modified Model Y vehicles operating without a safety driver in the vehicle, consistent with recent unsupervised expansions. Cybercab two-seaters remain limited primarily to Austin for now. It’s worth noting that Dept. of Transportation officials in Texas have already ok’d the Cybercab’s operation in Austin, and one official called it “a tangible example of how quickly our transportation system is evolving.”
San Antonio was previously listed among near-term targets in Tesla’s October 2026 Robotaxi safety materials, alongside Las Vegas, Phoenix, and Jacksonville. The rapid Texas rollout follows Fort Worth’s unsupervised debut on November 2 and builds on Austin’s original launch in June 2025.
The 274-square-mile debut remains substantially larger than Waymo’s local footprint and marks continued progress in Tesla’s unsupervised autonomy efforts after starting the year with no such rides. The company has stated ambitions for broader 24/7 operations by the end of 2026 as vehicle counts and software reliability improve.
Tesla has started to perform earthworks engineering on the roughly 3,000-acre site in Fort Bend County, Texas, advancing the massive $10 billion Project Crystal Sun plan to build a vertically integrated solar manufacturing complex.
Flyover drone footage from S.E. Robinson, Jr. released this morning shows the location under development. Tesla has crews on site performing large clearings, but you can also see equipment staging areas, the use of an existing homestead, and active leveling across a substantial portion of the property.
Tesla has started construction on Project Crystal Sun, its $10B vertically integrated solar factory near Houston, Texas.
The plant will make everything from silicon ingots and wafers to finished cells and panels, with operations targeted for Q1 2029.
@SERobinsonJr with a great flyover of the facility:
— TESLARATI (@Teslarati) November 9, 2026
Public filings first submitted in July under Texas’s Jobs, Energy, Technology and Innovation Act describe a plant that would manufacture the full solar chain: everything from silicon ingots, wafers, coated cells, and finished modules.
Tesla projects 9,712 permanent jobs by 2033, ramping from roughly 1,900 positions in the first year of operations, plus a peak of about 1,147 construction jobs. Construction is targeted for 2026–2028, with commercial production beginning in the first quarter of 2029. An accompanying economic analysis estimates the project could add roughly $107 billion to Texas GDP over several decades.
Local incentives have cleared major hurdles. Lamar Consolidated Independent School District unanimously approved school-tax limitations in September, and Fort Bend County commissioners approved a package of abatements and related agreements in late October that could extend equipment tax breaks for as long as 35 years.
Tesla had previously indicated it was evaluating a competing out-of-state location.
The effort fits broader statements by Musk that Tesla and SpaceX are each working toward 100 gigawatts of annual U.S. solar manufacturing capacity. If built as described, Project Crystal Sun would stand as one of the largest domestic attempts to create a fully integrated solar supply chain on American soil.
While Tesla has not issued a formal groundbreaking announcement, the visible site preparation and high-profile social media activity represent a concrete step forward for a project that has moved from confidential filings to active earthworks in a matter of months.

Tesla exec hints at a wild fix for Robotaxi’s biggest weather problem

Tesla Robotaxi enters its newest city, reaching San Antonio


