News
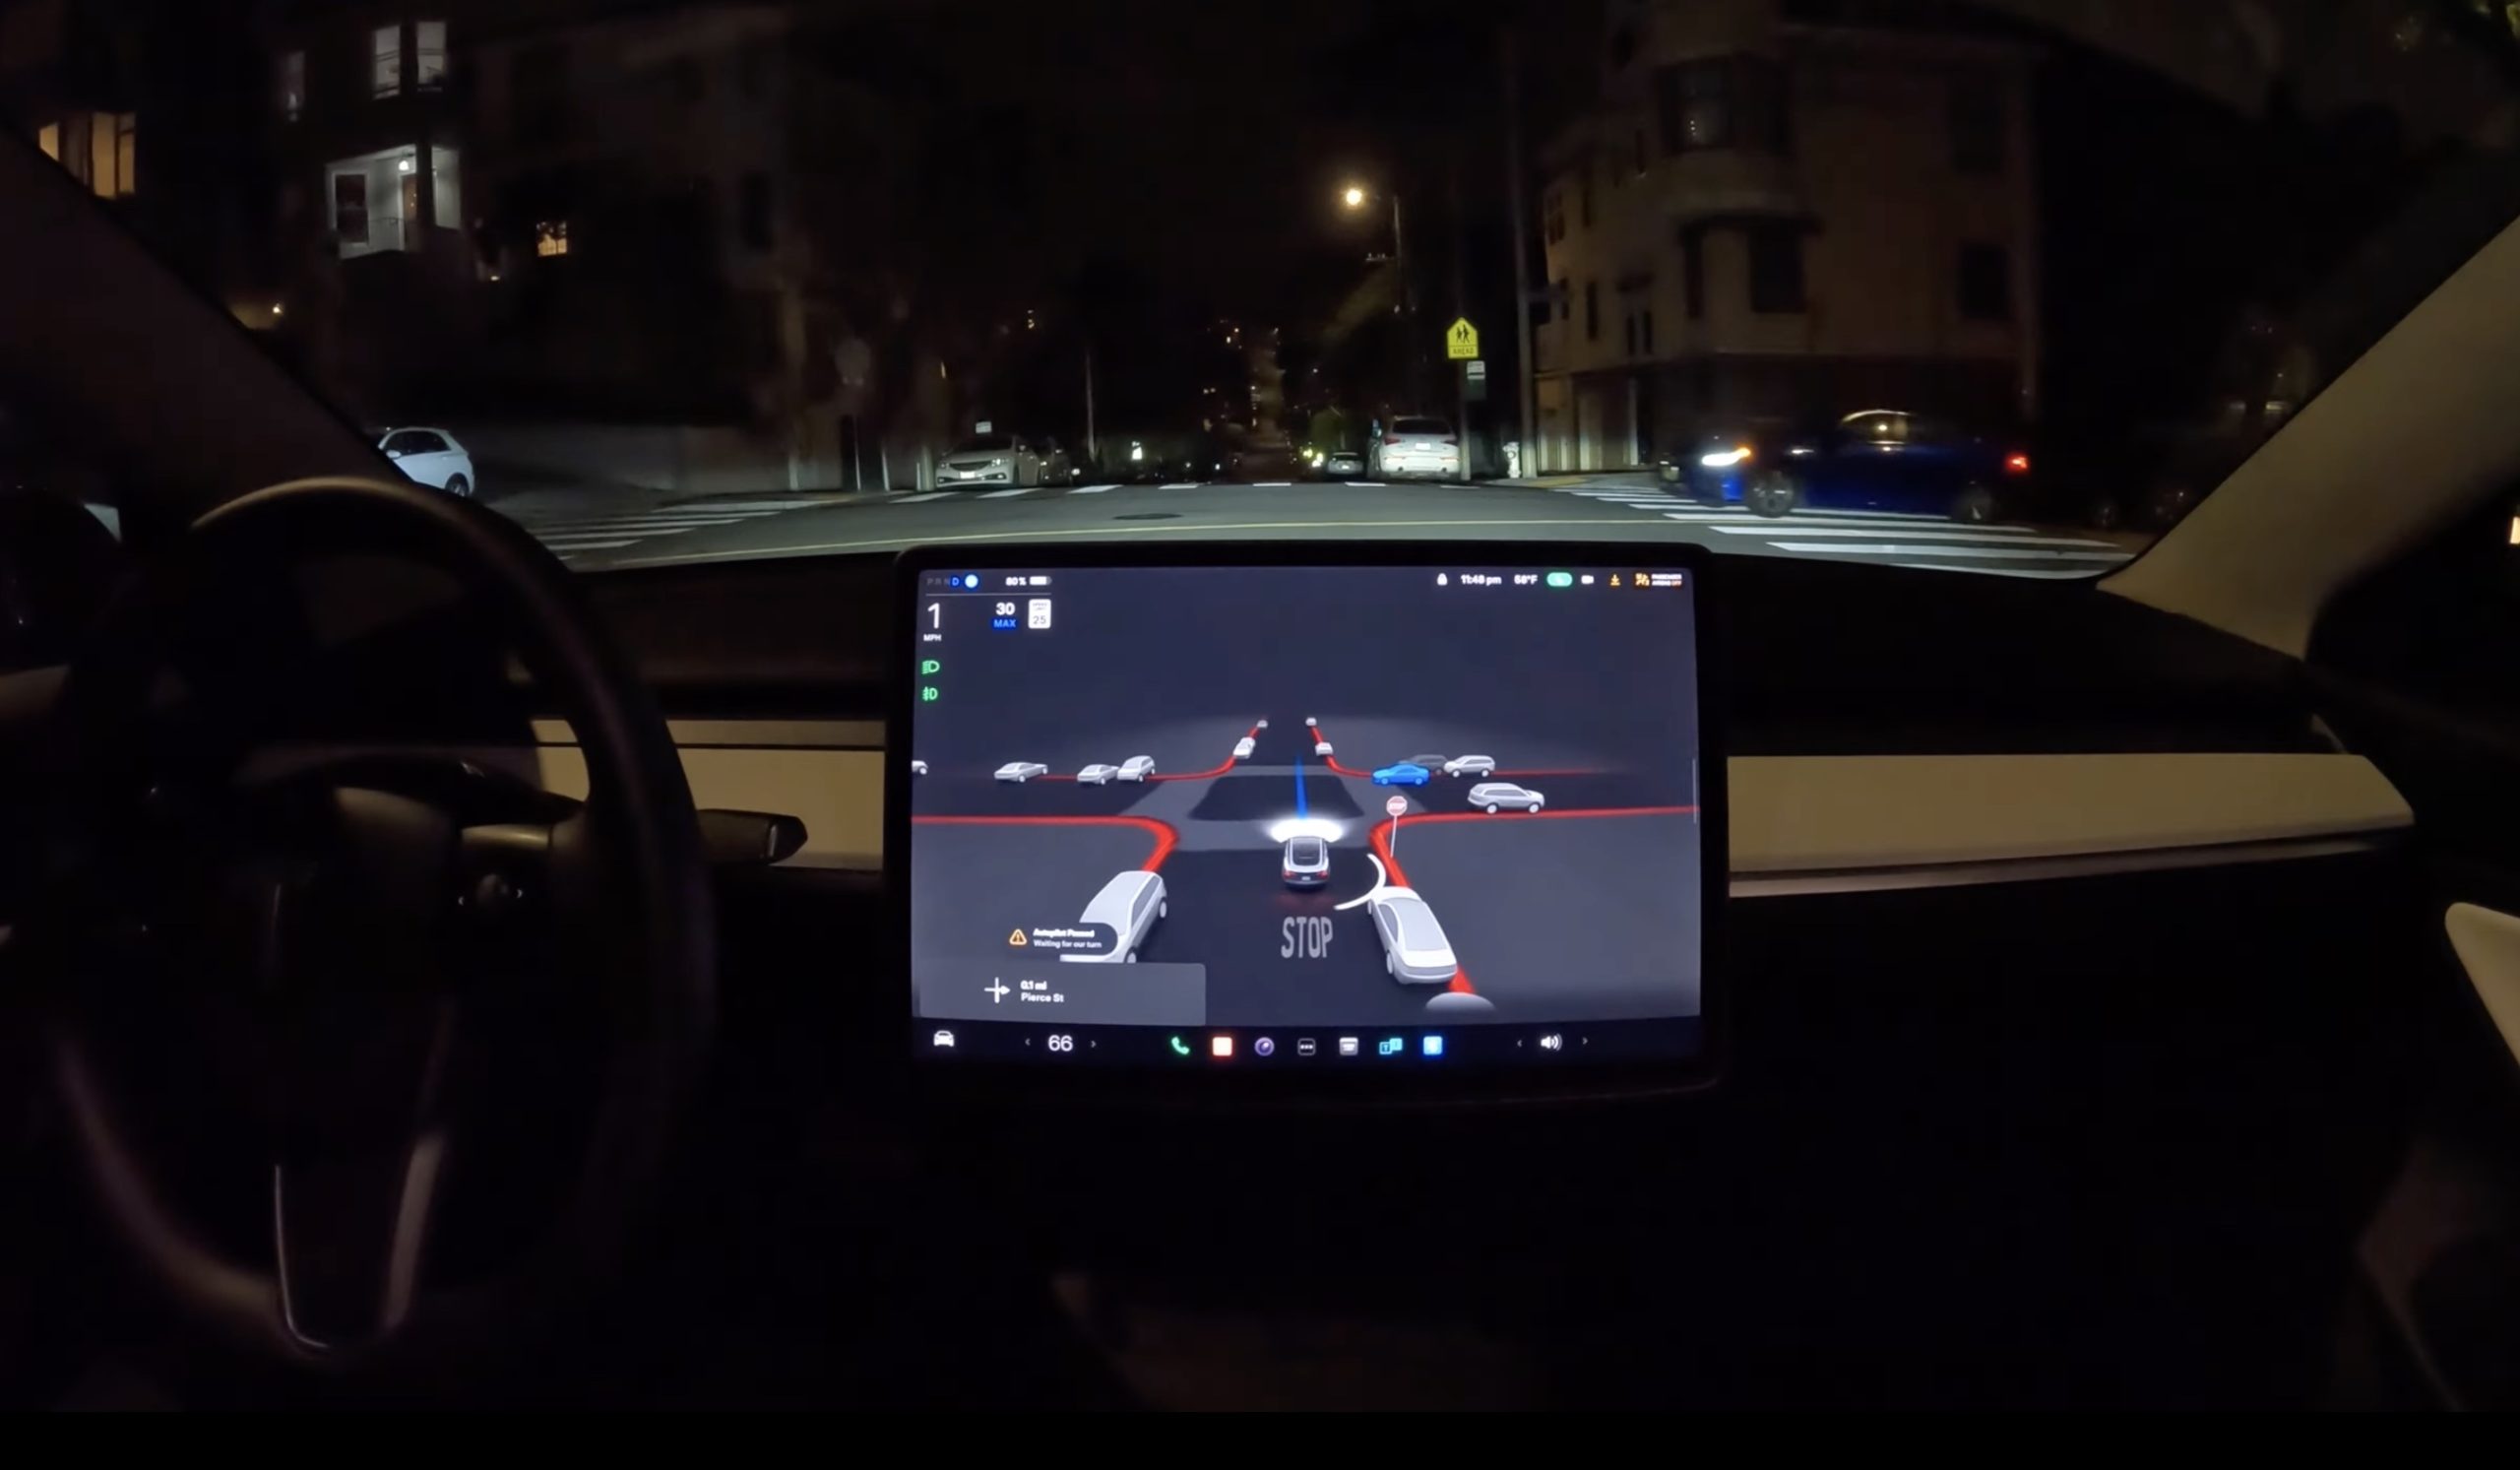
Tesla FSD Beta 10.69.2.2 extending to 160k owners in US and Canada: Elon Musk

It appears that after several iterations and adjustments, FSD Beta 10.69 is ready to roll out to the greater FSD Beta program. Elon Musk mentioned the update on Twitter, with the CEO stating that v10.69.2.2. should extend to 160,000 owners in the United States and Canada.
Similar to his other announcements about the FSD Beta program, Musk’s comments were posted on Twitter. “FSD Beta 10.69.2.1 looks good, extending to 160k owners in US & Canada,” Musk wrote before correcting himself and clarifying that he was talking about FSD Beta 10.69.2.2, not v10.69.2.1.
While Elon Musk has a known tendency to be extremely optimistic about FSD Beta-related statements, his comments about v10.69.2.2 do reflect observations from some of the program’s longtime members. Veteran FSD Beta tester @WholeMarsBlog, who does not shy away from criticizing the system if it does not work well, noted that his takeovers with v10.69.2.2 have been marginal. Fellow FSD Beta tester @GailAlfarATX reported similar observations.
Tesla definitely seems to be pushing to release FSD to its fleet. Recent comments from Tesla’s Senior Director of Investor Relations Martin Viecha during an invite-only Goldman Sachs tech conference have hinted that the electric vehicle maker is on track to release “supervised” FSD around the end of the year. That’s around the same time as Elon Musk’s estimate for FSD’s wide release.
It should be noted, of course, that even if Tesla manages to release “supervised” FSD to consumers by the end of the year, the version of the advanced driver-assist system would still require drivers to pay attention to the road and follow proper driving practices. With a feature-complete “supervised” FSD, however, Teslas would be able to navigate on their own regardless of whether they are in the highway or in inner-city streets. And that, ultimately, is a feature that will be extremely hard to beat.
Following are the release notes of FSD Beta v10.69.2.2, as retrieved by NotaTeslaApp:
– Added a new “deep lane guidance” module to the Vector Lanes neural network which fuses features extracted from the video streams with coarse map data, i.e. lane counts and lane connectivities. This architecture achieves a 44% lower error rate on lane topology compared to the previous model, enabling smoother control before lanes and their connectivities becomes visually apparent. This provides a way to make every Autopilot drive as good as someone driving their own commute, yet in a sufficiently general way that adapts for road changes.
– Improved overall driving smoothness, without sacrificing latency, through better modeling of system and actuation latency in trajectory planning. Trajectory planner now independently accounts for latency from steering commands to actual steering actuation, as well as acceleration and brake commands to actuation. This results in a trajectory that is a more accurate model of how the vehicle would drive. This allows better downstream controller tracking and smoothness while also allowing a more accurate response during harsh maneuvers.
– Improved unprotected left turns with more appropriate speed profile when approaching and exiting median crossover regions, in the presence of high speed cross traffic (“Chuck Cook style” unprotected left turns). This was done by allowing optimisable initial jerk, to mimic the harsh pedal press by a human, when required to go in front of high speed objects. Also improved lateral profile approaching such safety regions to allow for better pose that aligns well for exiting the region. Finally, improved interaction with objects that are entering or waiting inside the median crossover region with better modeling of their future intent.
– Added control for arbitrary low-speed moving volumes from Occupancy Network. This also enables finer control for more precise object shapes that cannot be easily represented by a cuboid primitive. This required predicting velocity at every 3D voxel. We may now control for slow-moving UFOs.
– Upgraded Occupancy Network to use video instead of images from single time step. This temporal context allows the network to be robust to temporary occlusions and enables prediction of occupancy flow. Also, improved ground truth with semantics-driven outlier rejection, hard example mining, and increasing the dataset size by 2.4x.
– Upgraded to a new two-stage architecture to produce object kinematics (e.g. velocity, acceleration, yaw rate) where network compute is allocated O(objects) instead of O(space). This improved velocity estimates for far away crossing vehicles by 20%, while using one tenth of the compute.
– Increased smoothness for protected right turns by improving the association of traffic lights with slip lanes vs yield signs with slip lanes. This reduces false slowdowns when there are no relevant objects present and also improves yielding position when they are present.
– Reduced false slowdowns near crosswalks. This was done with improved understanding of pedestrian and bicyclist intent based on their motion.
– Improved geometry error of ego-relevant lanes by 34% and crossing lanes by 21% with a full Vector Lanes neural network update. Information bottlenecks in the network architecture were eliminated by increasing the size of the per-camera feature extractors, video modules, internals of the autoregressive decoder, and by adding a hard attention mechanism which greatly improved the fine position of lanes.
– Made speed profile more comfortable when creeping for visibility, to allow for smoother stops when protecting for potentially occluded objects.
– Improved recall of animals by 34% by doubling the size of the auto-labeled training set.
– Enabled creeping for visibility at any intersection where objects might cross ego’s path, regardless of presence of traffic controls.
– Improved accuracy of stopping position in critical scenarios with crossing objects, by allowing dynamic resolution in trajectory optimization to focus more on areas where finer control is essential.
– Increased recall of forking lanes by 36% by having topological tokens participate in the attention operations of the autoregressive decoder and by increasing the loss applied to fork tokens during training.
– Improved velocity error for pedestrians and bicyclists by 17%, especially when ego is making a turn, by improving the onboard trajectory estimation used as input to the neural network.
– Improved recall of object detection, eliminating 26% of missing detections for far away crossing vehicles by tuning the loss function used during training and improving label quality.
– Improved object future path prediction in scenarios with high yaw rate by incorporating yaw rate and lateral motion into the likelihood estimation. This helps with objects turning into or away from ego’s lane, especially in intersections or cut-in scenarios.
– Improved speed when entering highway by better handling of upcoming map speed changes, which increases the confidence of merging onto the highway.
– Reduced latency when starting from a stop by accounting for lead vehicle jerk.
– Enabled faster identification of red light runners by evaluating their current kinematic state against their expected braking profile.
Press the “Video Record” button on the top bar UI to share your feedback. When pressed, your vehicle’s external cameras will share a short VIN-associated Autopilot Snapshot with the Tesla engineering team to help make improvements to FSD. You will not be able to view the clip.
Don’t hesitate to contact us with news tips. Just send a message to simon@teslarati.com to give us a heads up.

Give the gift of Tesla upgrades.
Shop for someone else or treat yourself. Get more shopping power with a Teslarati gift card.
Elon Musk
Elon Musk reveals Tesla’s next vehicle without a steering wheel
Elon Musk says Tesla plans a driverless Model Y for families too big for Cybercab.

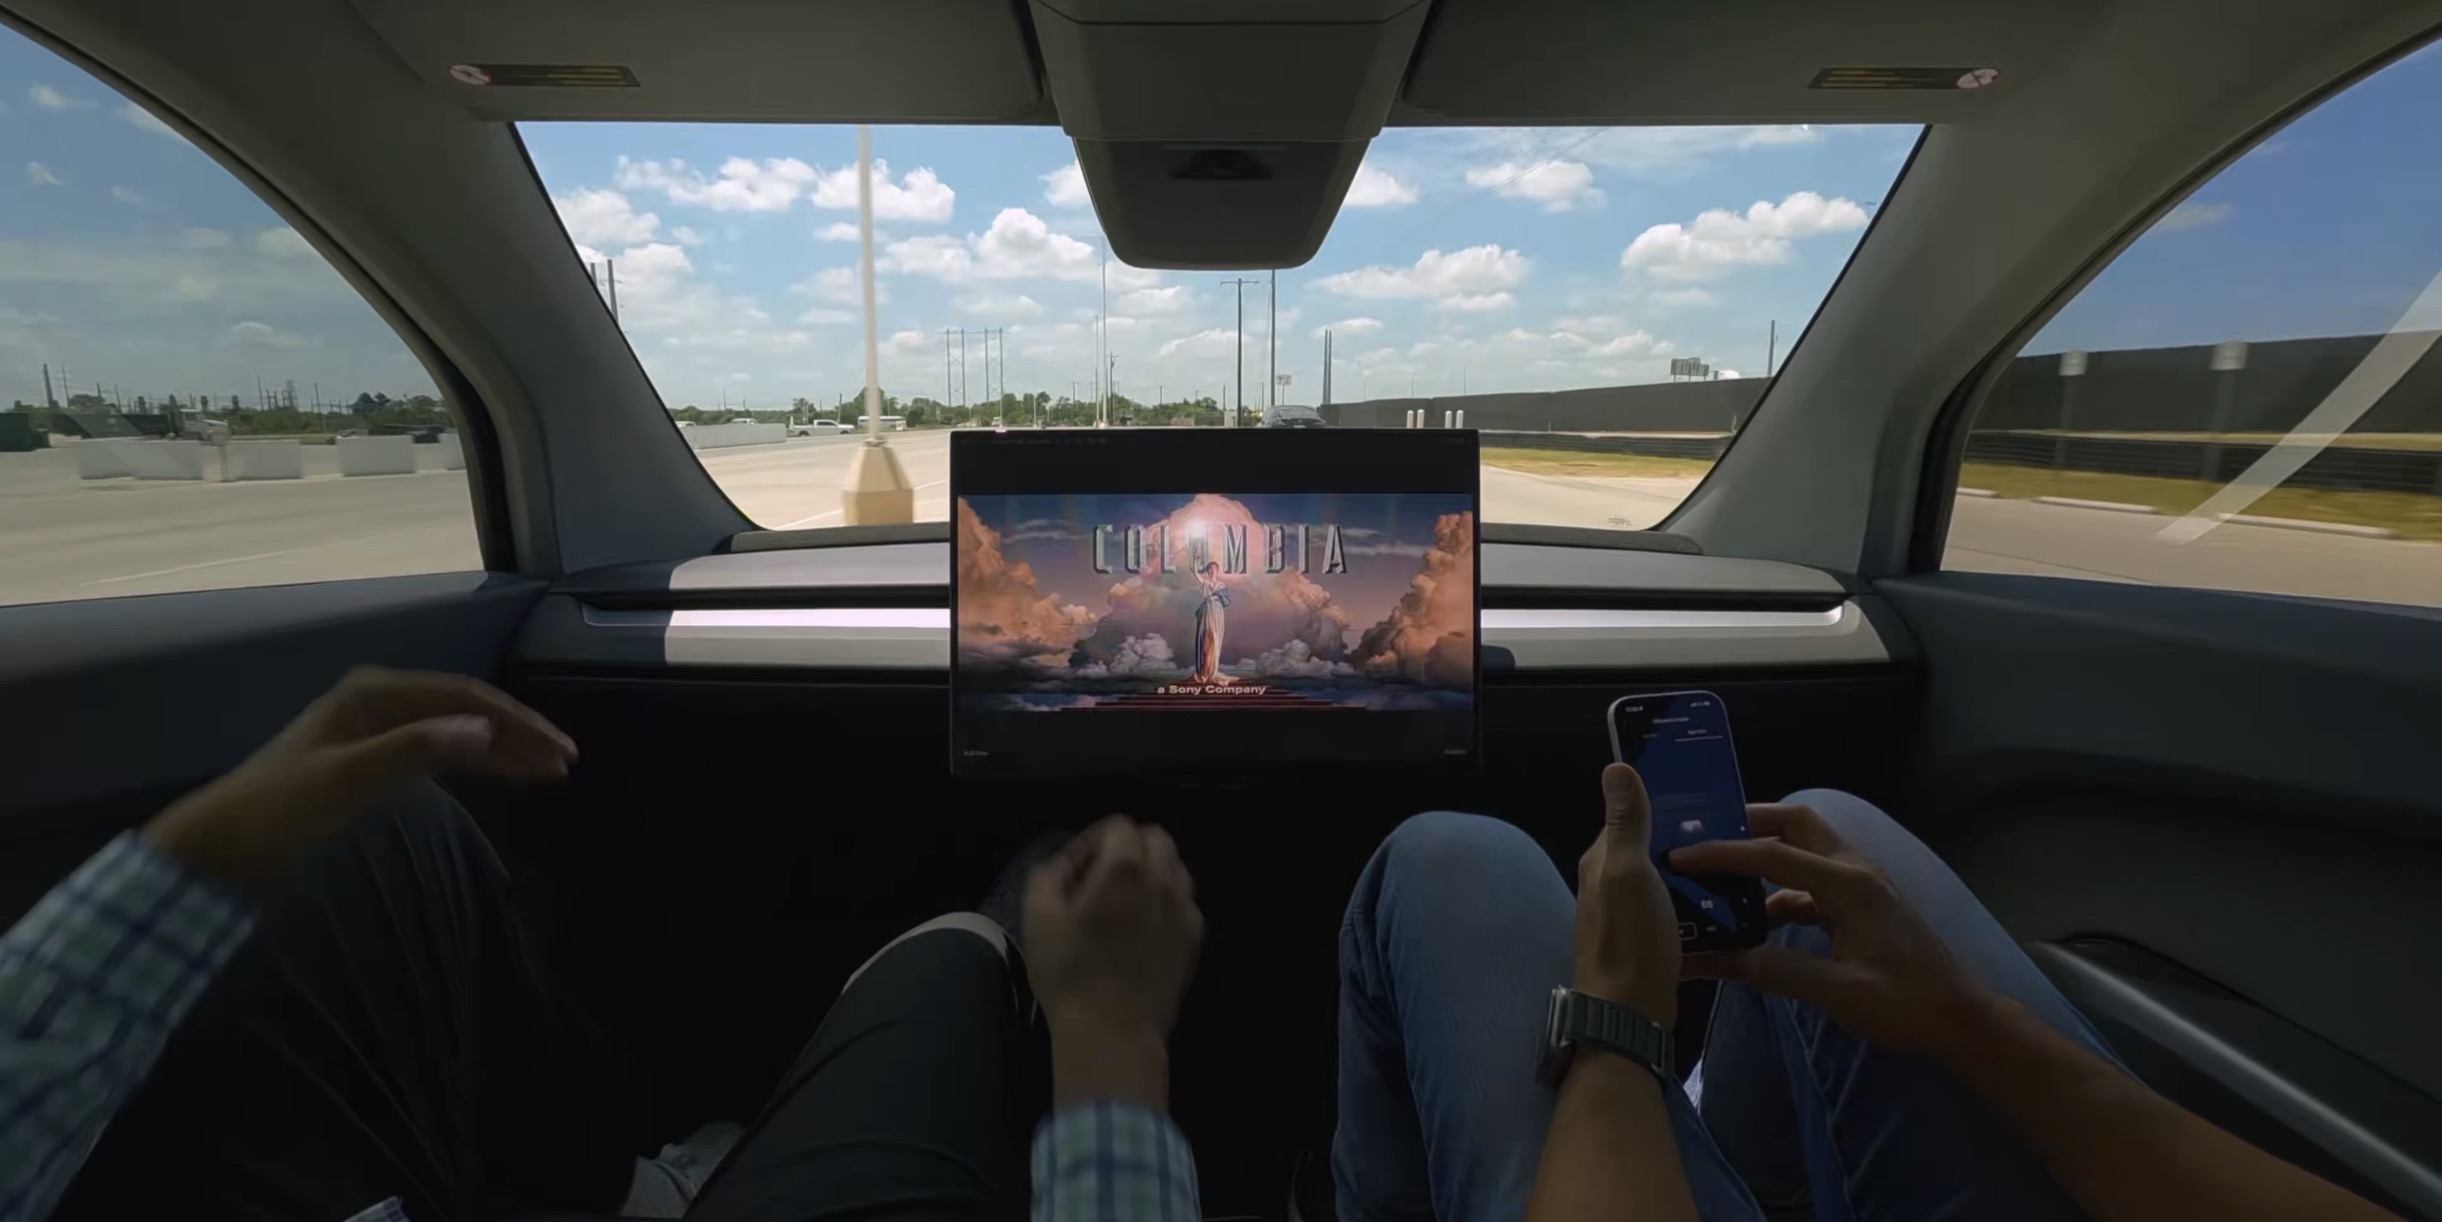
Tesla is planning a driverless version of the Model Y with room for six or seven people, Elon Musk said this week, giving families and groups an alternative to the two-seat Cybercab. Speaking remotely from China at the New York Times DealBook Summit on Wednesday, Musk said the vehicle would have no steering wheel or pedals. He did not give a launch date, price or production location.
The idea came up when Andrew Ross Sorkin asked whether Tesla would eventually stop selling conventional cars as it shifts Cybertruck capacity toward the Cybercab. Musk defended the two-seat design, saying average occupancy is about 1.2 people per car and that a two-seater covers roughly 90 percent of passenger miles. Bigger groups, he said, would be served by the larger autonomous Model Y.
Sorkin also mentioned he had ordered a Model Y L for his family and was still waiting on it. Musk called the six-seat, long-wheelbase SUV Tesla’s most popular car and suggested all Model Y production might need to move to the longer version. “It’s what most people seem to want,” Musk said, though he did not announce any change to Tesla’s production lines.
A driverless Model Y would add a third vehicle to Tesla’s autonomous lineup. Model Y Robotaxis already run 24 hours a day in eight cities, and Cybercab rides expanded to Dallas on Thursday after launching in Austin in September, as Teslarati reported. Tesla also began inviting select customers to buy a Cybercab for personal use last week at $29,990, with deliveries targeted for December.
Musk also addressed whether a Tesla and SpaceX merger should pay out under his compensation plan. Under the change in control terms of his 2025 CEO award, a deal could accelerate vesting, Electrek has noted. Musk said it should not. “I don’t think I should be compensated with any kind of award just for doing a merger. That would be unreasonable and not right,” he said. “You should keep your deals and stay true to your word.”
On the merger itself, Musk said the companies would “probably” be better together because of growing overlap in AI, chips and robotics, but stressed the decision rests with independent committees and shareholders, and that a Tesla vote “may or may not succeed.” Tesla holds its annual shareholder meeting on December 3, with merger talks reportedly progressing toward a possible announcement as soon as December.
Elon Musk
Elon Musk makes surprise stop at Giga Shanghai with a message for Tesla’s China team
Elon Musk flew overnight to Giga Shanghai to personally thank Tesla’s China and APAC teams.
Elon Musk made an overnight stop at Gigafactory Shanghai on Thursday, flying in from Shenzhen to thank Tesla’s China and Asia-Pacific teams in person during a 24-hour trip to China. Tesla vice president Grace Tao confirmed the visit in a Weibo post, saying Musk met employees face to face, praised the Shanghai team’s manufacturing capabilities and execution, and discussed progress on driver assistance and humanoid robots.
Photos from the visit show Musk at the center of a large group of factory workers. “Let’s make the future look like the future,” he told the team, according to posts from the event that Musk shared on X. Attendees also said he urged employees to spend their time and resources on becoming truly useful and building products that matter to humanity, rather than chasing short-term speculation.
The trip was tied to APEC Leaders’ Week in Shenzhen, where Musk traveled as part of President Trump’s Asia delegation. It is also why he joined Wednesday’s New York Times DealBook Summit remotely, writing beforehand, “I will be in China, so it will be digital me.”
Before arriving in Shanghai, Musk met in Shenzhen with Ren Hongbin, chairman of the China Council for the Promotion of International Trade. A CCTV-affiliated account reported that Musk pledged Tesla would keep increasing production in China, though it gave no target or timeline.
Giga Shanghai remains Tesla’s most productive factory. It shipped 810,889 Model 3 and Model Y vehicles in the first ten months of 2026, up 21.4 percent from a year earlier, according to figures cited by Reuters, and Tesla’s third quarter update lists its installed capacity at more than 950,000 vehicles a year.
Most of that output is now leaving China. Of the 67,829 vehicles Shanghai shipped in October, 59,012 were exports, leaving 8,817 for domestic buyers. Tesla’s China retail sales were down 66 percent from a year earlier that month, the lowest since July 2022, according to CnEVPost.
Musk’s comments on driver assistance will be watched closely by Chinese owners, who are still waiting on a full rollout of Tesla’s supervised self-driving software. Musk said a year ago he hoped for full approval in China around early 2026, but Tesla has not announced a launch date, as Teslarati has reported. The country is also a key test of Musk’s broader pitch: autonomy and Optimus are the businesses he has said will make up the vast majority of Tesla’s future value.

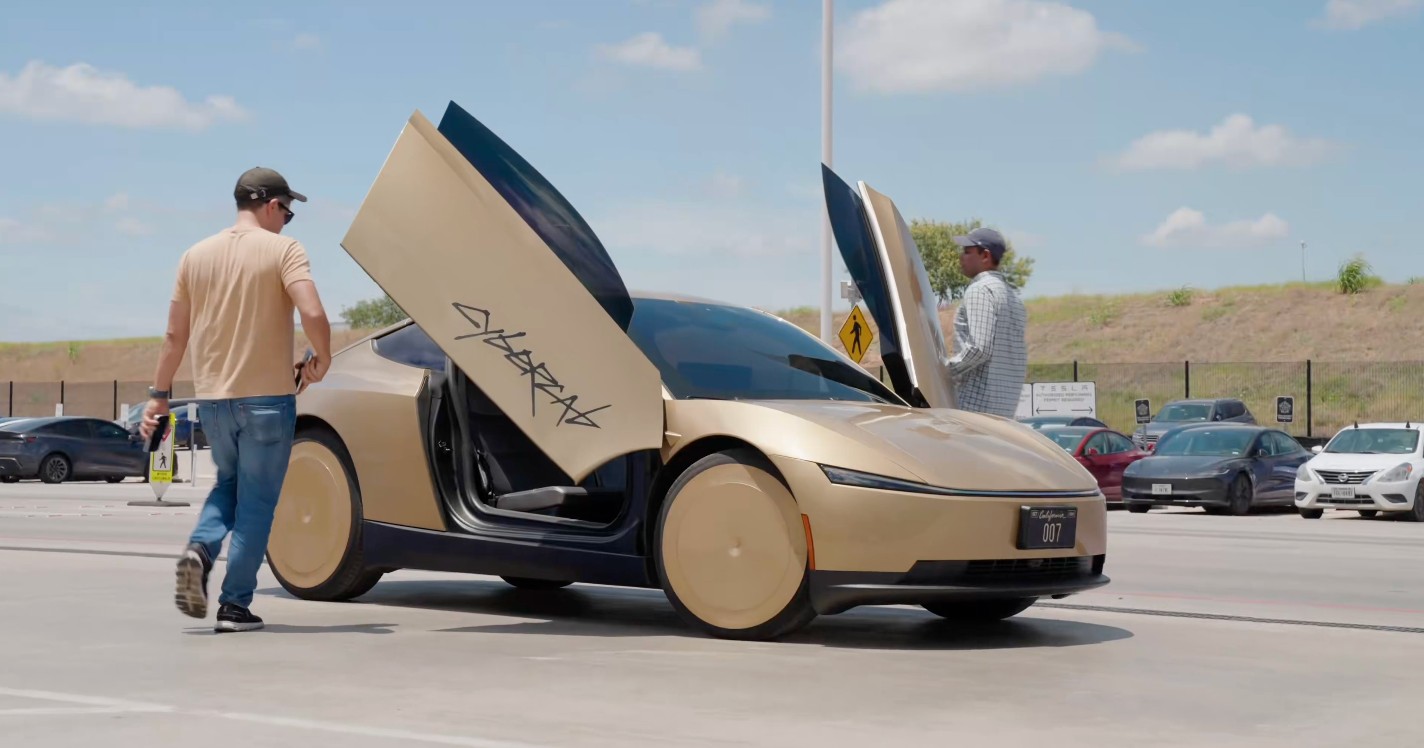
Tesla has opened public rides in its purpose-built Cybercab robotaxi in Dallas, the second U.S. city after Austin to receive the two-seat, steering-wheel-free vehicle.
On November 19, the company made it official with a post stating, “Howdy Dallas. Cybercab has arrived in your city.” Tesla has been teasing the expansion to Dallas for several weeks:
Howdy Dallas
Cybercab has arrived in your city https://t.co/4coXmRuIfz
— Robotaxi (@robotaxi) November 19, 2026
Riders can book through the Tesla Robotaxi app. Tesla had already been operating unsupervised Model Y Robotaxis in Dallas since April, the Cybercab addition brings its dedicated autonomous vehicle into the same network.
App notifications and the official post confirm the service is now available to the public, following a tease the day before and a commitment made on the October 21 Q3 2026 earnings call by AI software chief Ashok Elluswamy that Dallas would be next.
Cybercab rides first began in limited areas of Austin in early September 2026. After an invite-only event on September 3, public hailing started shortly thereafter. The Austin fleet grew rapidly, Musk later noted it had increased roughly tenfold in the first weeks, and the service has operated unsupervised, with hours expanding toward 24/7 coverage.
The vehicle, produced at Gigafactory Texas, features butterfly doors, no pedals or steering wheel, and relies entirely on Tesla’s unsupervised Full Self-Driving software.
Expanding Cybercab beyond Austin is a significant signal for several reasons. It shows Tesla moving from a concentrated pilot to multi-city deployment of its purpose-built robotaxi, validating that the software stack and vehicle-specific data accumulation can transfer to new environments.
Executives have described plans to reach additional cities by the end of 2026, using the same software alongside Model Y Robotaxis.
The move intensifies competition with Waymo, which operates larger unsupervised fleets across more markets, while reinforcing Tesla’s long-term bet on transportation-as-a-service as a core business. Most Cybercabs are expected to remain company-owned for the fleet rather than sold privately, allowing Tesla to control utilization and scale.
Your Tesla could be in the Robotaxi fleet next month, Elon Musk claims
Separately, Tesla has begun inviting select customers to purchase Cybercabs for personal use, with deliveries targeted for December.
Tesla priced the Cybercab $29,990 before taxes with a required $299 monthly Autonomy Subscription, and a $1,000 non-refundable deposit, with initial deliveries focused on Austin. Company leaders have emphasized that customer volumes will start small while the vast majority of vehicles stay in Tesla’s own Robotaxi network.

Elon Musk reveals Tesla’s next vehicle without a steering wheel

Elon Musk makes surprise stop at Giga Shanghai with a message for Tesla’s China team


