News
Tesla FSD Beta 10.13’s improvements to be (especially) evident for non-CA users

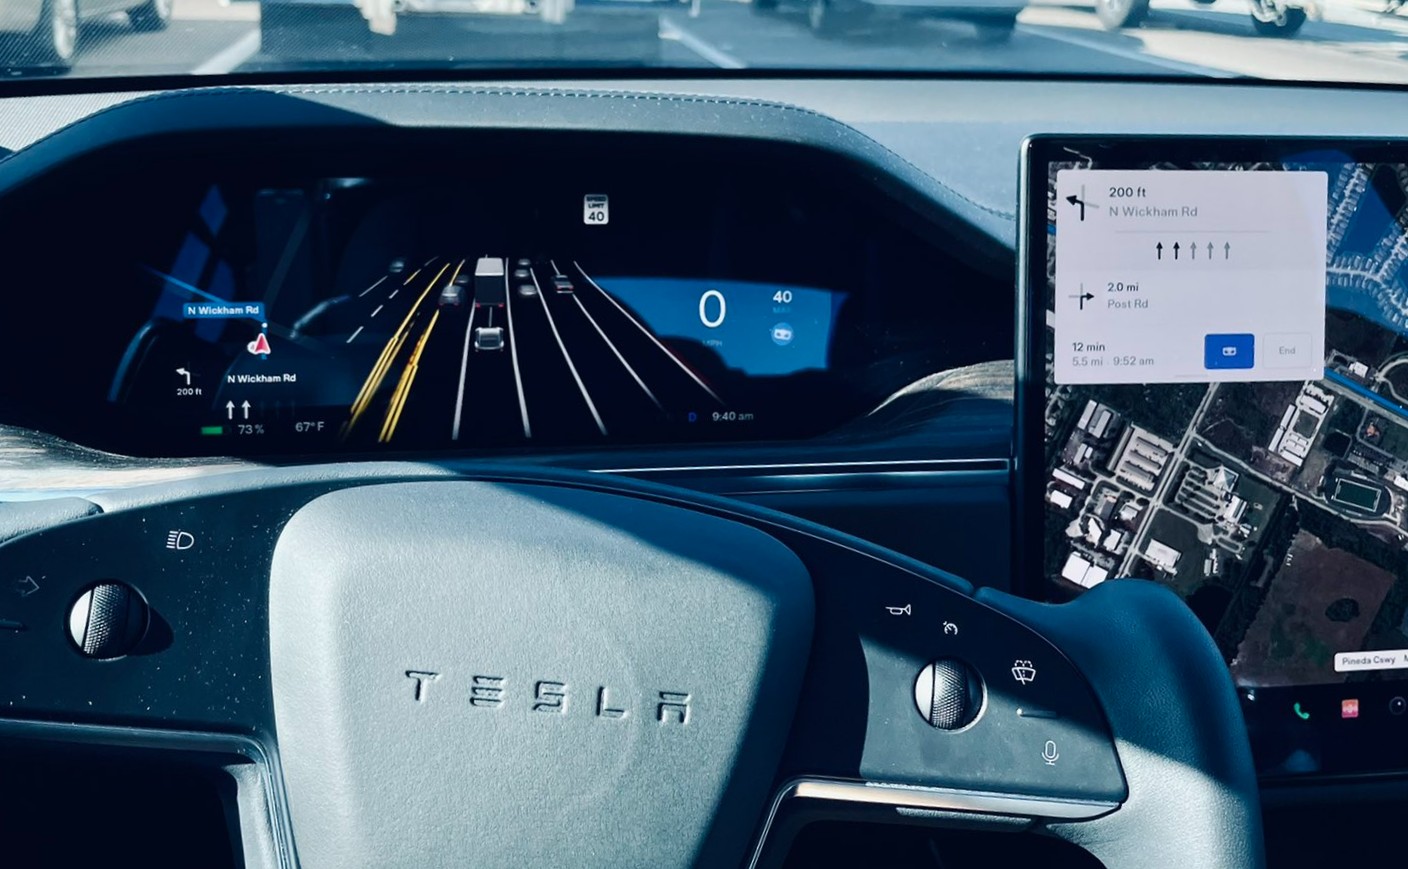
Elon Musk recently provided some updates on the wide rollout of FSD Beta 10.13. The latest iteration of the company’s advanced driver-assist system began its initial release earlier this month, but its wide release has not been initiated yet.
In a recent post on Twitter, Elon Musk admitted that while Tesla is working extremely hard on FSD Beta 10.13, the system itself is not ready for wide release just yet. He estimated that FSD Beta 10.13’s wide release would likely be a week or so away, but when it does, drivers outside California will experience some very notable improvements.
As noted by the Tesla CEO, users “outside of California will notice improvements the most.” This is an interesting comment, especially considering that Musk has admitted in the past that FSD Beta “seems to work better in California” than in other areas such as Rhode Island. Musk admitted to this last year, noting that FSD Beta has been overfitted to the Bay Area.
As noted in a Benzinga report, overfitting in statistics suggests that a model relates to a specific set of data points far too closely, which may not translate well with different data points. In the case of FSD Beta, this could result in the advanced driver assist system working very well in areas like San Francisco but not as well in other areas of the United States.
Release notes of FSD Beta 10.13 leaked earlier this month have revealed that the update includes a number of key performance improvements.
Following are the partial release notes of FSD Beta 10.13 that have been shared thus far:
- Improved decision making for unprotected left turns using better estimation of ego’s interaction with other objects through the maneuver.
- Improved stopping pose while yielding for crossing objects at “Chuck Cook style” unprotected left turns by utilizing the median safety regions.
- Made speed profile more comfortable when creeping for visibility, to allow for smoother stops when protecting for potentially occluded objects.
- Enabled creeping for visibility at any intersection where objects might cross ego’s path, regardless of presence of traffic controls.
- Improved lane position error by 5% and lane recall by 12%…
- Improved lane position error of crossing and merging lanes by 22% by adding long-range skip connections and a more powerful trunk to the network architecture.
- Improved pedestrian and bicyclist velocity error by 17%, especially when ego is making a turn, by improving the onboard trajectory estimation used as input to the neural network.
- Improved animal detection recall by 34% and decreased false positives by 8% by doubling the size of the auto-labeled training set.
- Improved detection recall of far away crossing vehicles by 4% by tuning the loss function used during training and improving label quality.
- Improved the “is parked” attribute for vehicles by 5% by adding 20% more examples to the training set.
- Upgraded the occupancy network to detect dynamic objects and improved performance by adding a video module, tuning the loss function, and adding 37k new clips to the training set.
- Reduced false slowdowns around crosswalks by better classification of pedestrians and bicyclists as not intending to interact with ego.
- Reduced false lane changes for cones or blockages by preferring gentle offsetting in-lane where appropriate.
- Improved in-lane positioning on wide residential roads.
- Improved object future path prediction in scenarios with high yaw rate.
- Improved speed limit sign accuracy on digital speed limits by 29%, on signs with difficult relevance by 23%, on 3-digit speeds by 39%, and on speed limit end signs by 62%. Neural network was trained with 84% more examples in the training set and with architectural changes which allocated more compute in the network head.
Don’t hesitate to contact us with news tips. Just send a message to simon@teslarati.com to give us a heads up.


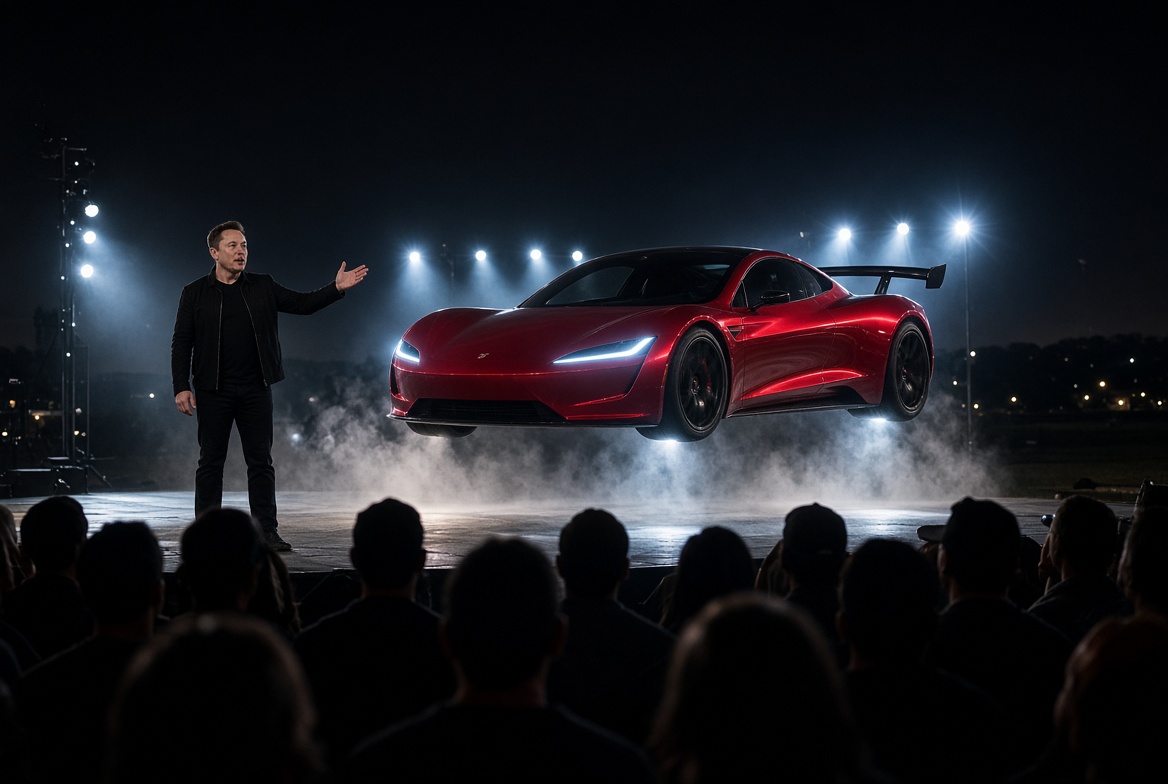
Tesla announced on Monday that the Roadster event scheduled for today would be postponed due to the need for it to be held outside.
Less than 24 hours later, CEO Elon Musk broadened that by stating it was due to high winds, immediately sending everyone into a frenzy over the Roadster’s potential ability to fly.
And realistically, it could definitely have to do with it flying, hovering, or hopping; whatever Tesla has in mind for this demonstration could not be impacted by wind. However, it might have nothing to do with the vehicle flying whatsoever, and instead could be a simple precaution, as the Roadster is a very unique vehicle with some already official specs that are just mind-blowing.
Tesla will very, very likely be showcasing both the acceleration rate and potentially even a top speed demo at the event in Waco. Both of these demonstrations, performed with a vehicle that has such incredibly fast metrics, could easily be impacted by wind as well.
Tesla Roadster event requires restricted airspace, and the FAA obliges
Top Speed Demo
At high speeds, aerodynamic forces are already overwhelmingly present. A crosswind or sudden gust adds a layer of sideways force that the tires must counter with slip angle. On a short demo course, that force can shove the car off the intended line, especially in a light car with a low frontal area and little mass to resist the push.
Electric cars, due to their battery packs, have an advantage of an extremely low center of gravity, giving them extra stability. However, the speeds at which the Roadster could travel at the demo could spell some issues if crosswinds are present.
Gusts are worse than a steady wind because the load changes faster than a driver can smoothly correct. That shows up as weaving or a late correction. Headwinds and tailwinds can also spell disaster. Headwinds cut a measured top speed but raise the power needed to get there or maintain it. Meanwhile, a tailwind can inflate the top speed, and downforce issues could become more noticeable.
Wind also loads the body unevenly. A low car can feel light on the upwind side or see a sudden change in downforce if the gust hits a wing or diffuser at an angle. Tire temperature and pressure might stay near a normal level, but lateral grip can be lost as the vehicle is spent fighting the wind.
Acceleration Demo
Launch and 0-60 MPH runs are shorter, so the car spends less time exposed to forces that could cause things to go awry. However, the first second is very sensitive, as a crosswind at launch could yaw the car before speed builds and prior to aerodynamic impact being too great. The driver will be required to correct traction control or manage how much the wheels are spinning, which will likely be corrected automatically by some sort of traction control system within the Roadster (we are fairly certain Tesla will implement something brilliant with it).
These things could cause an unstable run.
A headwind would increase drag as speed rises, while a tailwind would do the opposite. Meanwhile, surface effects, like wind-driven dust, light debris, or even rain, could reduce grip at the exact moment the tires are asked for peak longitudinal force. Standing water plus a crosswind is a common reason an acceleration attempt might be scrapped.
Flying or Not
No matter what Tesla has in store for the Roadster, waiting for ideal conditions is a great idea. People who follow and support the company, along with the engineers involved in the Roadster program, have been waiting nine years since the last unveiling for this moment. Everything should be ideal.
Some speculate that it’s just not ready, and that’s ridiculous. Why would Tesla even schedule the event — albeit prematurely — after nine years if it was not ready? Why would they jump the gun now?
We were all excited for today, but it truly is the most ideal thing in the world to wait two more weeks so everything, including the weather, can be perfect. The delay is simply worth it. But Tesla, seriously, make this the last one.
Elon Musk
SpaceX nails “Lucky 13” astronaut launch, leaning into Tesla tradition and superstition
SpaceX launched Crew-13 astronauts to the ISS Thursday, setting up a record fast Dragon docking.

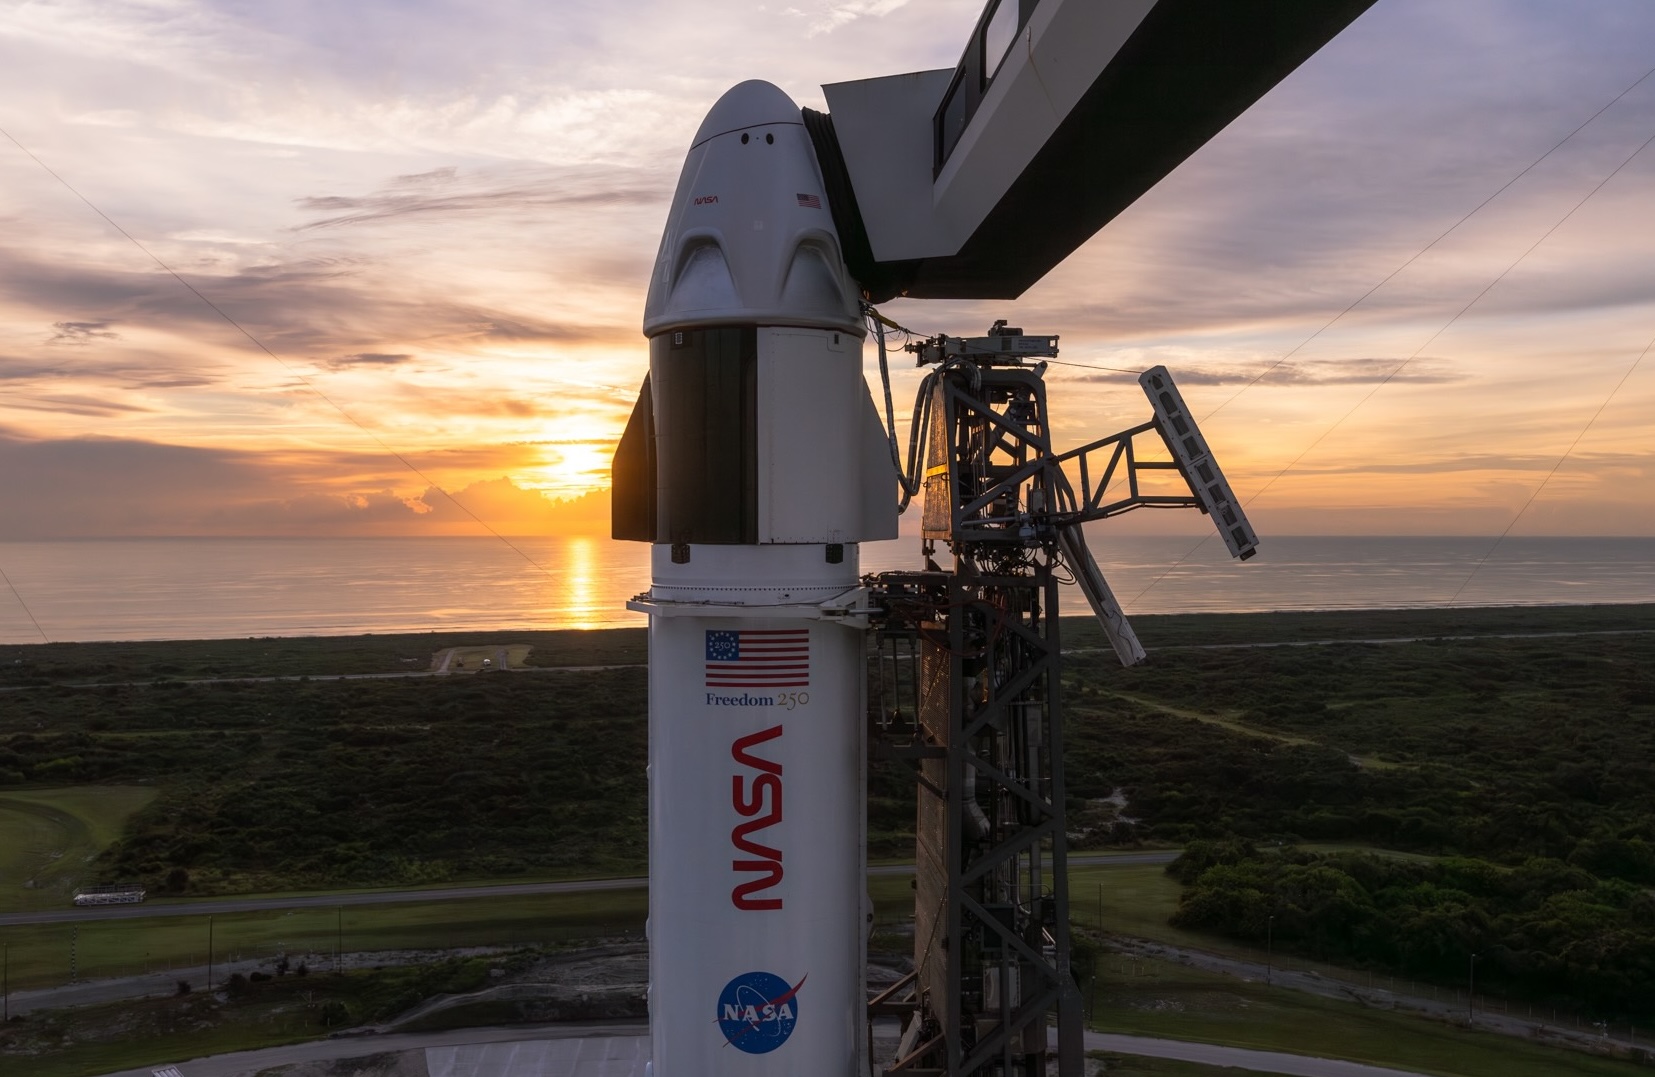
SpaceX launched NASA’s Crew-13 mission to the International Space Station on Thursday morning, getting four astronauts to orbit despite a forecast of thunderstorms and gusty winds that had threatened to push the flight to Friday.
Falcon 9 lifted off from Space Launch Complex 40 at Cape Canaveral Space Force Station at 11:10 a.m. ET carrying Dragon Grace, NASA confirmed. On board are NASA commander Jessica Watkins, NASA pilot Luke Delaney, Canadian Space Agency astronaut Joshua Kutryk and Roscosmos cosmonaut Sergey Teteryatnikov. The first stage booster, B1101, landed at Landing Zone 40 beside the pad on its third flight after previously supporting Crew-12 and a Starlink mission.
Liftoff of Crew-13! pic.twitter.com/vteT0DXMTh
— SpaceX (@SpaceX) October 1, 2026
It was the first spaceflight for Delaney, Kutryk and Teteryatnikov. Watkins, who flew on Crew-4 in 2022, became the first NASA astronaut to launch aboard a Crew Dragon twice.
Before launch, the crew rode to the pad in Teslas, a tradition on NASA’s SpaceX crew flights since 2020. This time the cars carried specialty plates reading “Lucky 13.” Watkins said the mission patch leans into the number on purpose, as a nod to Apollo 13 and the resilience of that crew.
Grace is now on a short trip to the station. Docking at the forward port of the Harmony module is scheduled for about 7 p.m. ET, roughly 7 hours and 50 minutes after liftoff, which Space.com notes would be the fastest Crew Dragon transit to the ISS yet. Most Dragon flights take around 15 to 24 hours to catch the station. Hatch opening is planned for 8:25 p.m. ET.
The launch came more than two weeks later than originally planned. An oxidizer leak was found in Grace’s propulsion system in August, and NASA and SpaceX added time for tests. That pushed back the return of Crew-12, which has been aboard the station since February and is now set to splash down off Southern California next week. Crew-13 is expected to stay about six months.
SpaceX rescue mission for stranded ISS astronauts nears end — Here’s when they’ll return home
SpaceX already holds NASA orders for crew rotations through Crew-17, while Boeing is preparing an uncrewed Starliner flight to the station as early as December.
Crew-13 was only the first of three SpaceX launches planned for Thursday, as Teslarati previewed on Wednesday. A Falcon 9 launched its Transporter-18 mission from California today, where Google will be launching its first orbital artificial intelligence (AI) test satellite. Meanwhile, Falcon Heavy is set to launch the classified NROL-97 mission for the National Reconnaissance Office from Launch Complex 39A at 11:53 p.m. ET. Its two side boosters will return to Landing Zones 1 and 2, which means Central Florida could hear up to three sonic booms in a single day. The busy stretch follows Starship’s Flight 14 on Monday, which reached orbit for the first time.
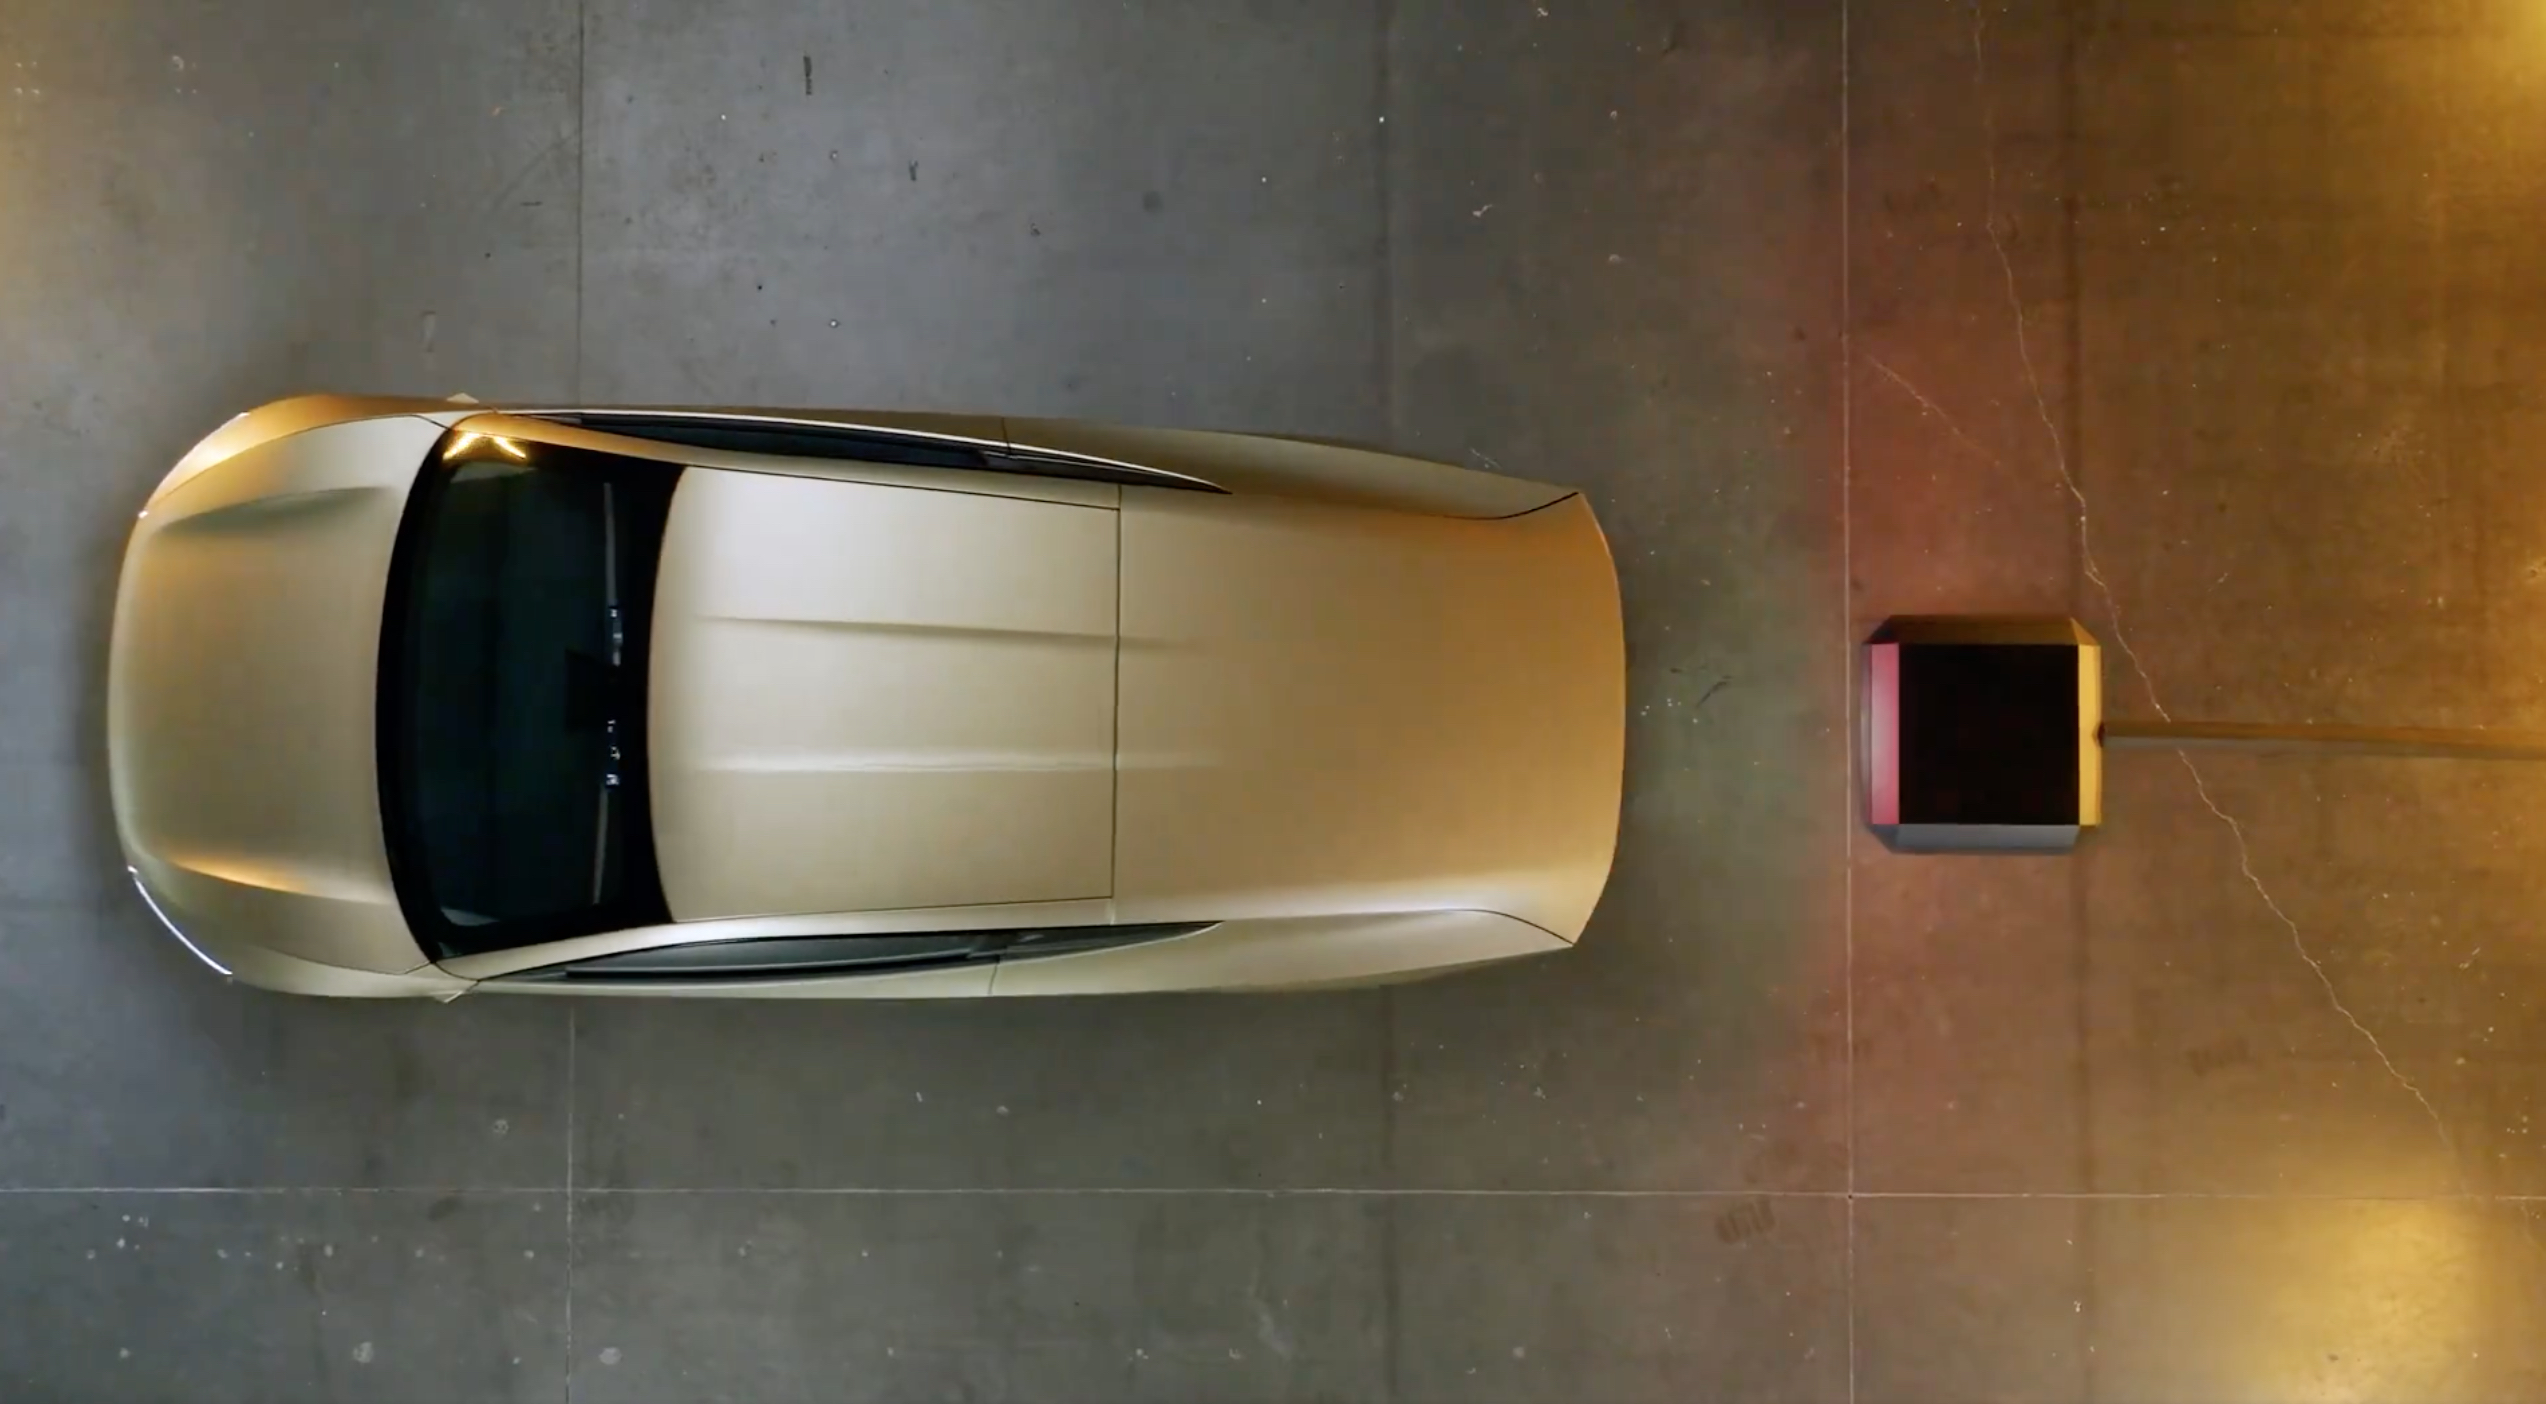
Tesla has moved its Wireless Charging efforts for its electric vehicles forward, as it had a new patent published today, one that it submitted back in March.
The patent describes a system for detecting foreign objects on the wireless charging pad under varying temperatures, aiming to mitigate any undesired results that could come from something being on top of the charging pad.
🚨 Tesla has a new patent application published today, which was submitted back in March, for a Wireless Charging Pad:
“The present disclosure relates to methods and systems that can reliably detect foreign objects on a wireless charging pad under varying temperatures. In some… pic.twitter.com/LIeLfZAuDJ
— TESLARATI (@Teslarati) October 1, 2026
The abstract of the patent states:
“The present disclosure relates to methods and systems that can reliably detect foreign objects on a wireless charging pad under varying temperatures. In some examples, an object detector can utilize a set of inductive coils included in resonant tanks, and excite the resonant tanks using signals in a range of frequencies including or near a nominal resonant frequency of the resonant tanks. The object detector can detect a metal object based on resistance of a coil increasing and inductance of the coil decreasing. By analyzing the shifts and/or distributions in resonant frequencies and output magnitudes (e.g., output voltage peaks), the object detector can distinguish between changes of frequencies and magnitudes caused by temperature and those caused by foreign objects to accurately detect the foreign objects.”
The object detection system will utilize a set of inductive coils included in resonant tanks, and “excite the resonant tank using signals in a range of frequencies including or near a nominal resonant frequency of the tanks.” Metal can be detected by an increase in the coil’s resistance and a decrease in the coil’s inductance.
By analyzing shifts or disruptions in resonant frequencies and output magnitudes, the system can detect foreign objects. These types of safeguards need to be implemented through the normal operation of the charging pads.
Tesla says its Cybercab wireless charging efficiency is ‘well above 90%’
Tesla plans to utilize wireless charging with Cybercab and Robotaxi-enabled units to help streamline the fully autonomous experience from A to Z. The last thing the company wants to do is have any sort of small obstruction preventing the rider from experiencing Robotaxi as intended.

Why Tesla Roadster unveiling delay might have nothing to do with it flying

SpaceX nails “Lucky 13” astronaut launch, leaning into Tesla tradition and superstition


