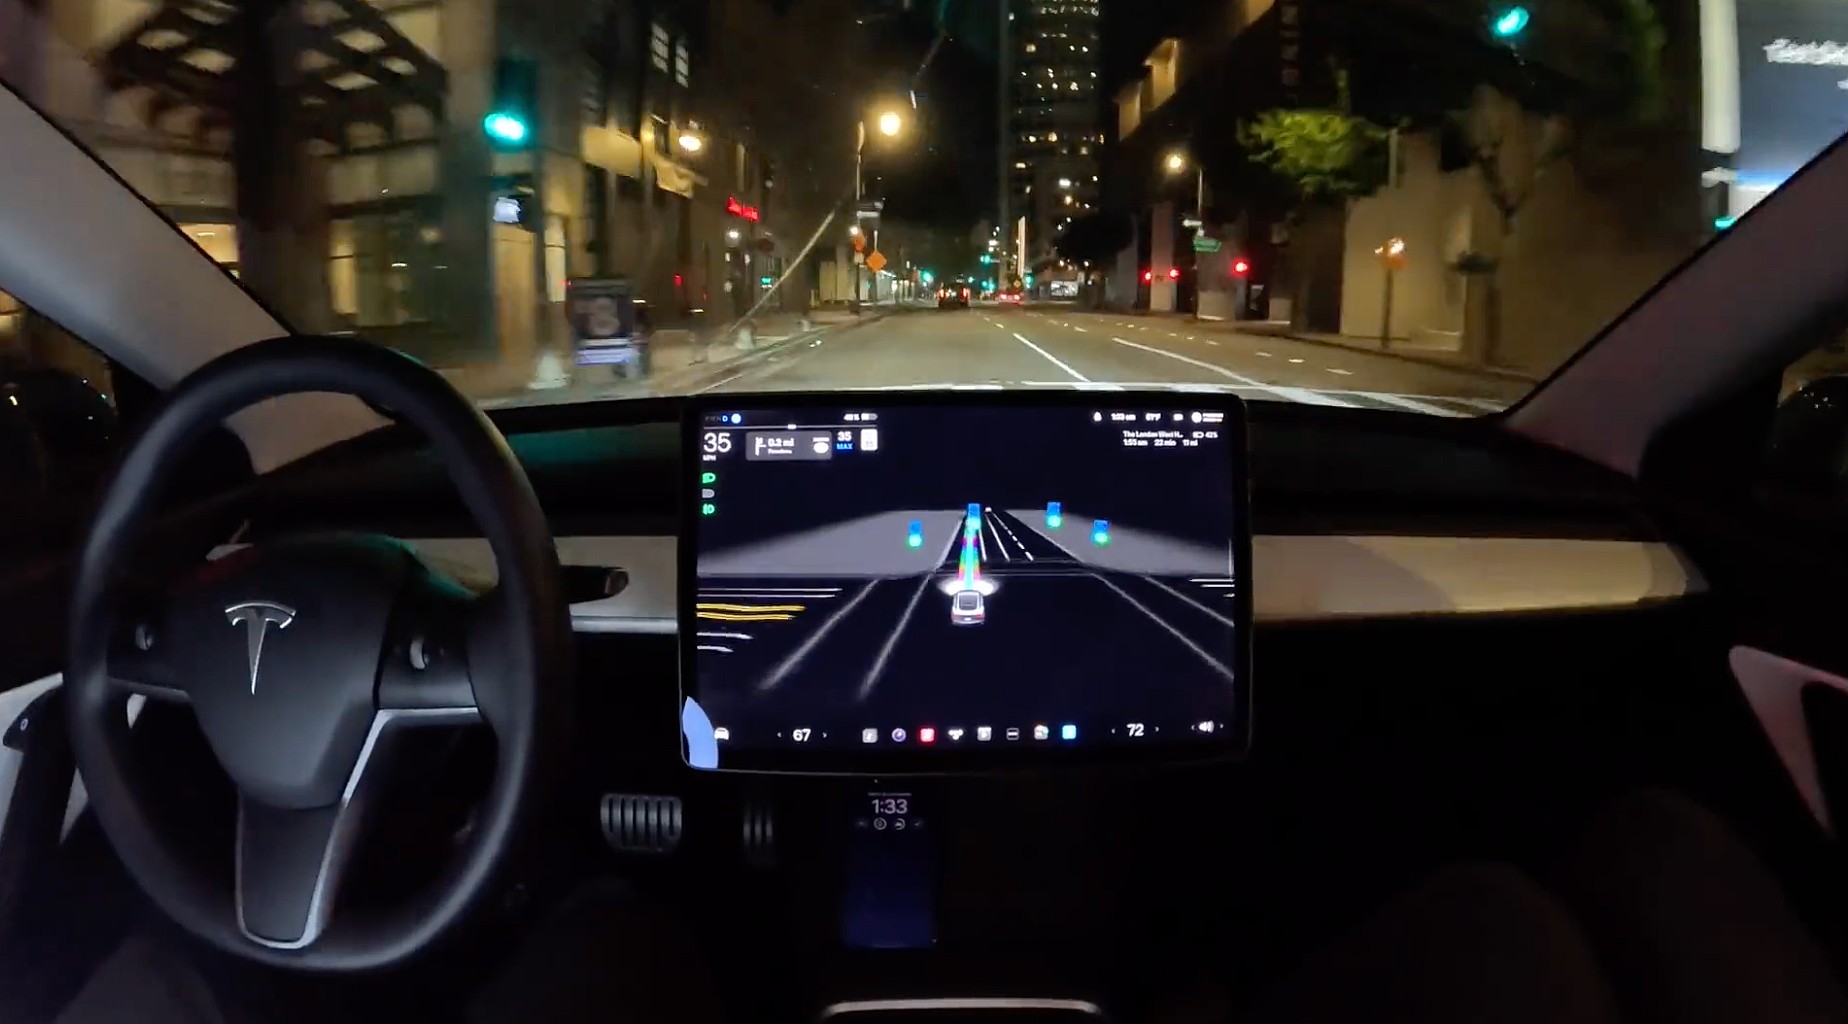

Tesla appears to have started slowly rolling out v11 of the Full Self-Driving Beta program this morning, just a few days after CEO Elon Musk stated the company would begin releasing it to more vehicles.
Tesla’s FSD Beta v11.3.1 started to roll out to employees late last year and a select few of the automaker’s long-standing testers a few weeks ago.
The controlled rollout allows Tesla to monitor its behaviors and tendencies in a highly safe way, as it can determine issues or bugs in a small sample size and fix them before a wider release begins.
On March 14, Musk stated that “ V11 starts going wide this weekend,” and we’ve heard it before. However, it appears the automaker is happy with the early reviews and is starting to release it to more vehicles.
V11 starts going wide this weekend
— Elon Musk (@elonmusk) March 15, 2023
v11.3.2 is the newest version of the Beta and is being rolled out with Tesla Software Update 2022.45.11. According to statistics from TeslaScope, more vehicles are being updated with the new FSD Beta v11, and more drivers on the r/TeslaMotors subreddit are beginning to report that they have received the update.
Drivers who have experienced the early editions of this rollout have reported that there have been several improvements to highway driving, and inner-city street navigation has also been refined and feels more accurate than ever before, which is undoubtedly a step in the right direction.
The full release notes for the FSD Beta are available below via TeslaScope:
- Enabled FSD Beta on highway. This unifies the vision and planning stack on and off-highway and replaces the legacy highway stack, which is over four years old. The legacy highway stack still relies on several single-camera and single-frame networks, and was setup to handle simple lane-specific maneuvers. FSD Beta’s multi-camera video networks and next-gen planner, that allows for more complex agent interactions with less reliance on lanes, make way for adding more intelligent behaviors, smoother control and better decision making.
- Improved recall for close-by cut-in cases by 15%, particularly for large trucks and high-yaw rate scenarios, through an additional 30k auto-labeled clips mined from the fleet. Additionally, expanded and tuned dedicated speed control for cut-in objects.
- Improved the position of ego in wide lanes, by biasing in the direction of the upcoming turn to allow other cars to maneuver around ego.
- Improved handling during scenarios with high curvature or large trucks by offsetting in lane to maintain safe distances to other vehicles on the road and increase comfort.
- Improved behavior for path blockage lane changes in dense traffic. Ego will now maintain more headway in blocked lanes to hedge for possible gaps in dense traffic.
- Improved lane changes in dense traffic scenarios by allowing higher acceleration during the alignment phase. This results in more natural gap selection to overtake adjacent lane vehicles very close to ego.
- Made turns smoother by improving the detection consistency between lanes, lines and road edge predictions. This was accomplished by integrating the latest version of the lane-guidance module into the road edge and lines network.
- Improved accuracy for detecting other vehicles’ moving semantics. Improved precision by 23% for cases where other vehicles transition to driving and reduced error by 12% for cases where Autopilot incorrectly detects its lead vehicle as parked. These were achieved by increasing video context in the network, adding more data of these scenarios, and increasing the loss penalty for control- relevant vehicles.
- Extended maximum trajectory optimization horizon, resulting in smoother control for high curvature roads and far away vehicles when driving at highway speeds.
- Improved driving behavior next to row of parked cars in narrow lanes, preferring to offset and staying within lane instead of unnecessarily lane changing away or slowing down.
- Improved back-to-back lane change maneuvers through better fusion between vision-based localization and coarse map lane counts.
- Added text blurbs in the user interface to communicate upcoming maneuvers that FSD Beta plans to make. Also improved the visualization of upcoming slowdowns along the vehicle’s path. Chevrons render at varying opacity and speed to indicate the slowdown intensity, and a solid line appears at locations where the car will come to a stop.
- Improved the recall and precision of object detection, notably reducing the position error of semi-trucks by 10%, increasing the recall and precision of crossing vehicles over 100m away by 3% and 7%, respectively, and increasing the recall of motorbikes by 5%. This was accomplished by implementing additional quality checks in our two million video clip autolabeled dataset.
- Reduced false offsetting around objects in wide lanes and near intersections by improving object kinematics modeling in low speed scenarios.
I’d love to hear from you! If you have any comments, concerns, or questions, please email me at joey@teslarati.com. You can also reach me on Twitter @KlenderJoey, or if you have news tips, you can email us at tips@teslarati.com.

News
Why Elon Musk’s target date for buying an Optimus robot is harder than it sounds
Musk says China’s magnet export ban cost Optimus months, and robot hands remain shockingly hard.

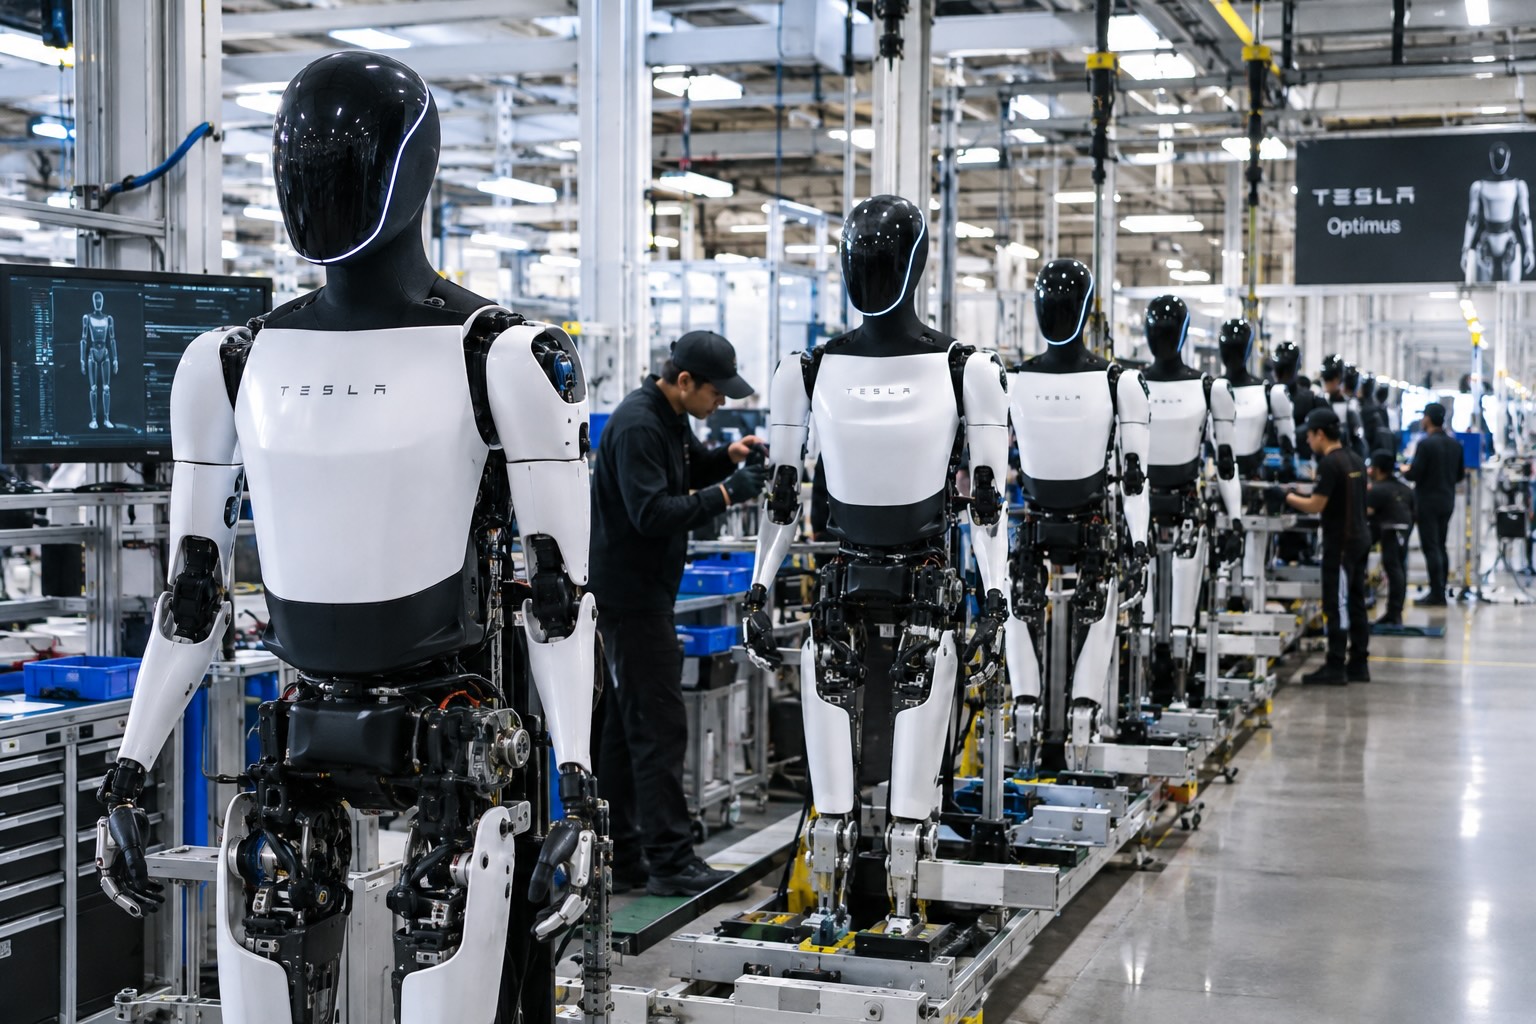
Elon Musk says China’s export curbs on magnets used in electric motors set back Tesla’s Optimus program by two to three months, and that the robot’s hands remain the hardest part of the project. He made the comments Saturday during a live interview with Tesla Owners Silicon Valley at the X Takeover event at Giga Texas, in front of roughly 2,000 attendees. The Optimus discussion begins around the 49 minute mark of the stream.
On the hands, Musk was blunt and noted that a general purpose humanoid needs fine motor skills that are “incredibly difficult to get right. Shockingly difficult,” he said in the interview. He pointed to a problem he says no one has demonstrated yet: “One of the hardest things also generally is to do precision and force at the same time,” such as driving a small self tapping screw into wood. Touch sensors add another layer, since it is “actually kind of hard to get touch sensors that elastically deform and can handle high cycle life and it won’t just break after a few thousand cycles.”
He also took aim at rival robot videos. “Any complicated looking robot demo, it’s a canned demo. It’s not real,” Musk said, adding that real AI means showing a robot something it has never seen and watching it still cope, the way FSD handles a city it has never driven.
Musk expects the Optimus ramp to be slower than a new vehicle production ramp. “The initial part of that S curve of production ramp is going to be very slow at the beginning,” Musk said, partly because “unlike cars, there’s no pre existing supply chain for robot stuff.” That echoes his July reply on X that Optimus production “will be extremely slow at first, as everything is new.”
The magnet disclosure puts a number on a problem Musk first raised in 2025. He said China “prevented the export of magnets for use in electric motors” and that it “set back the Optimus program by like two or three months.” Then he added: “We had robots with no arms.” Tesla’s fix is to bring the supply chain home. “You’ve got to be able to make all the parts domestically,” he said. Teslarati reported in April 2025 that Musk tied the issue to permanent magnets in the arm actuators, where motors have to be as small as possible.
Tesla Optimus V3 hand and arm details revealed in new patents
Production is moving regardless, with a reported internal goal of more than 1,000 a week by the end of 2026. Teslarati recently covered how Tesla is certifying supply partners in China for Optimus parts, while the company’s hand design has been the subject of new patent filings.
Musk has said he wants Optimus available to the public by late 2027, though Tesla has not confirmed that date or published updated production figures.
Investor's Corner
Elon Musk drops a Thanksgiving hint about Starship’s biggest test yet
Elon Musk says Starship Flight 15 will try to catch the ship itself, a first.
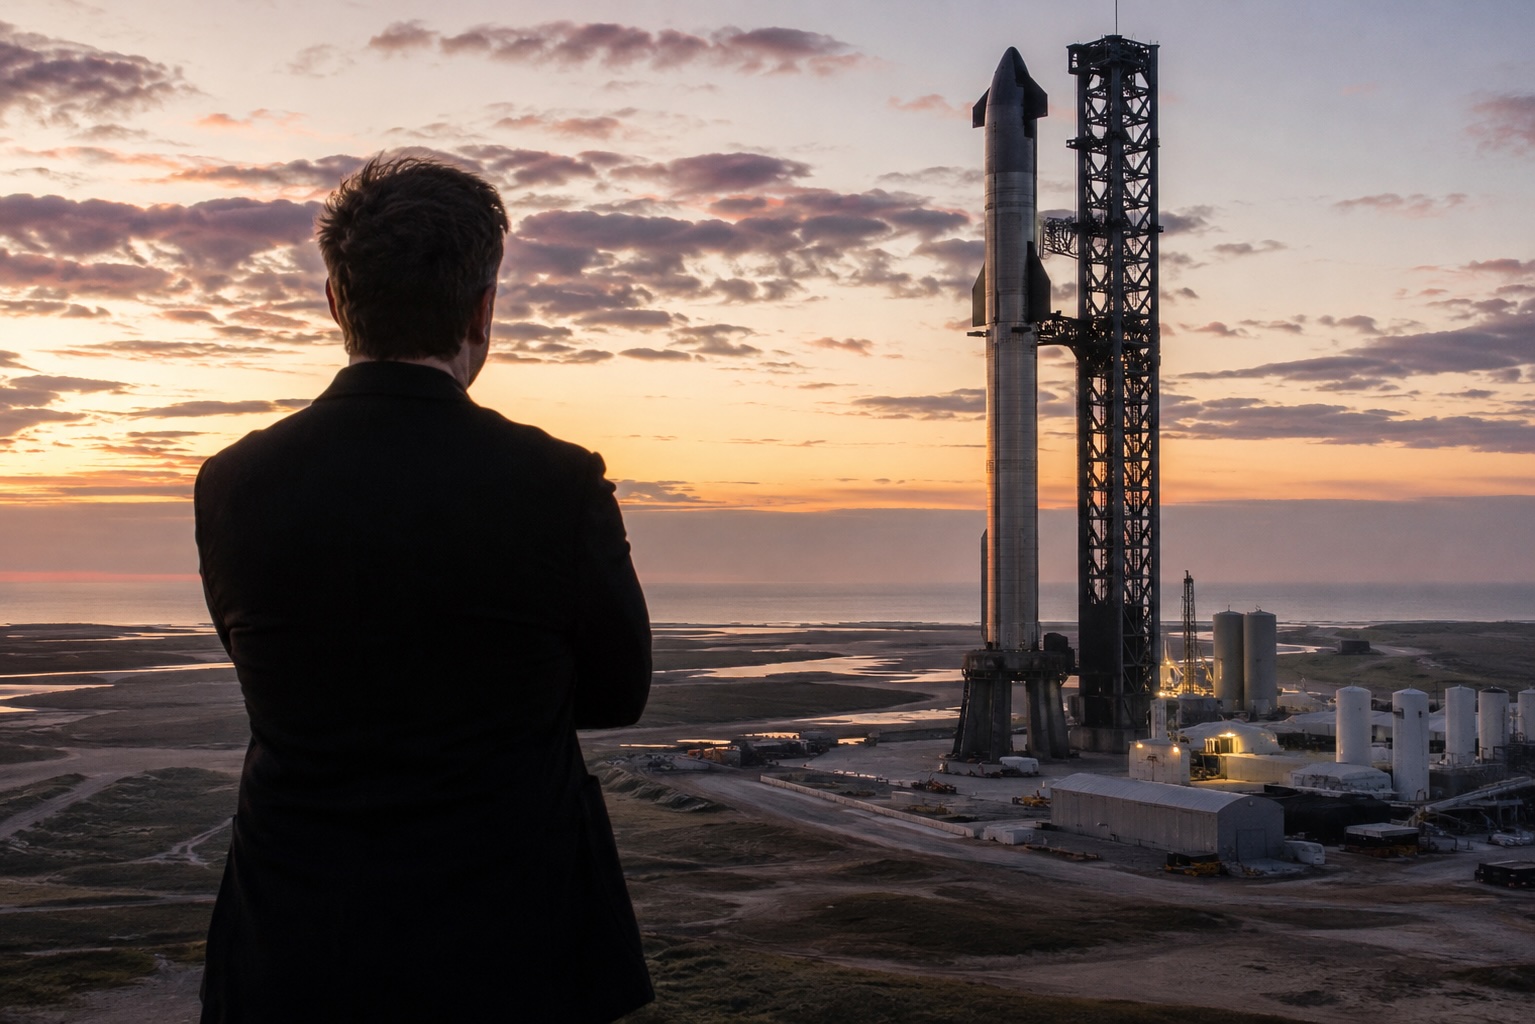
Elon Musk says SpaceX’s next Starship flight will try something nobody has done before, by catching the ship itself. Speaking to roughly 2,000 people at the X Takeover event at Giga Texas on Saturday, Musk said Flight 15 is about four to six weeks away and “probably launches a little bit before Thanksgiving, is my guess.”
That is a slip from earlier reporting, which had pointed to a launch as early as October 19. Musk explained why the date keeps moving. “We’re making a bunch of improvements to the rocket between every flight,” he said, adding that there are often hundreds, sometimes thousands, of small changes. This time the list is short, “but some of them take a fair bit of work and we’ve got to go inside the tank to make some of these changes.”
“We’re going to try to catch the ship, which is a super big deal,” Musk said. “If we do so, that’ll be the first time that there’s been full recovery of an orbital class rocket.” SpaceX has already caught the Super Heavy booster with the tower’s mechanical arms, and has talked about catching the ship since late 2025, but the upper stage has never been caught.
Musk also laid out what comes after. “The next big milestone would be to refly both the booster and the ship,” he said, describing a Flight 16 where “all parts of an orbital rocket are reflown.”
The reason SpaceX wants this comes down to cost and cadence. Every Starship ship so far has ended its flight in the ocean, and SpaceX expects most of those water landings to end in fireballs. A ship that returns to Starbase intact can be inspected and flown again. SpaceX’s IPO filing, says Starship V3 is designed to deliver 100 metric tons to orbit in a fully reusable configuration, that SpaceX aims to cut the cost to reach orbit by 99% or more versus the historical average, and that tower catches should allow “multiple launches per day.”
The payoff goes beyond cheaper launches. The next generation Starlink V3 satellites are too large for Falcon 9 and can only fly on Starship, which can carry up to 60 per flight. Flight 14 on September 28 deployed the first 26 of them after Starship reached orbit despite an early engine shutdown, as Teslarati reported. Musk blamed engine computer software, and said the heat shield “was extremely robust,” which he claimed in August had solved Starship’s biggest challenge.
NASA’s Moon plans depend on the same capability. NASA’s inspector general has described a lander mission that needs a propellant depot in low Earth orbit and more than 10 tanker flights, with SpaceX targeting one tanker launch every six days. That schedule only works if ships and boosters come back fast and fly again. Also, ship to ship propellant transfer has not been attempted yet.
One interesting hurdle yet to be explored is bringing the ship back to the launch site, with reentry over land, which will undoubtedly come with a lot of aviation safety reviews.
Lifestyle
Tesla’s mirrorless Cybercab will give riders a visibility upgrade
Tesla engineer confirms Cybercab update letting riders pull up rear and repeater cameras on demand.
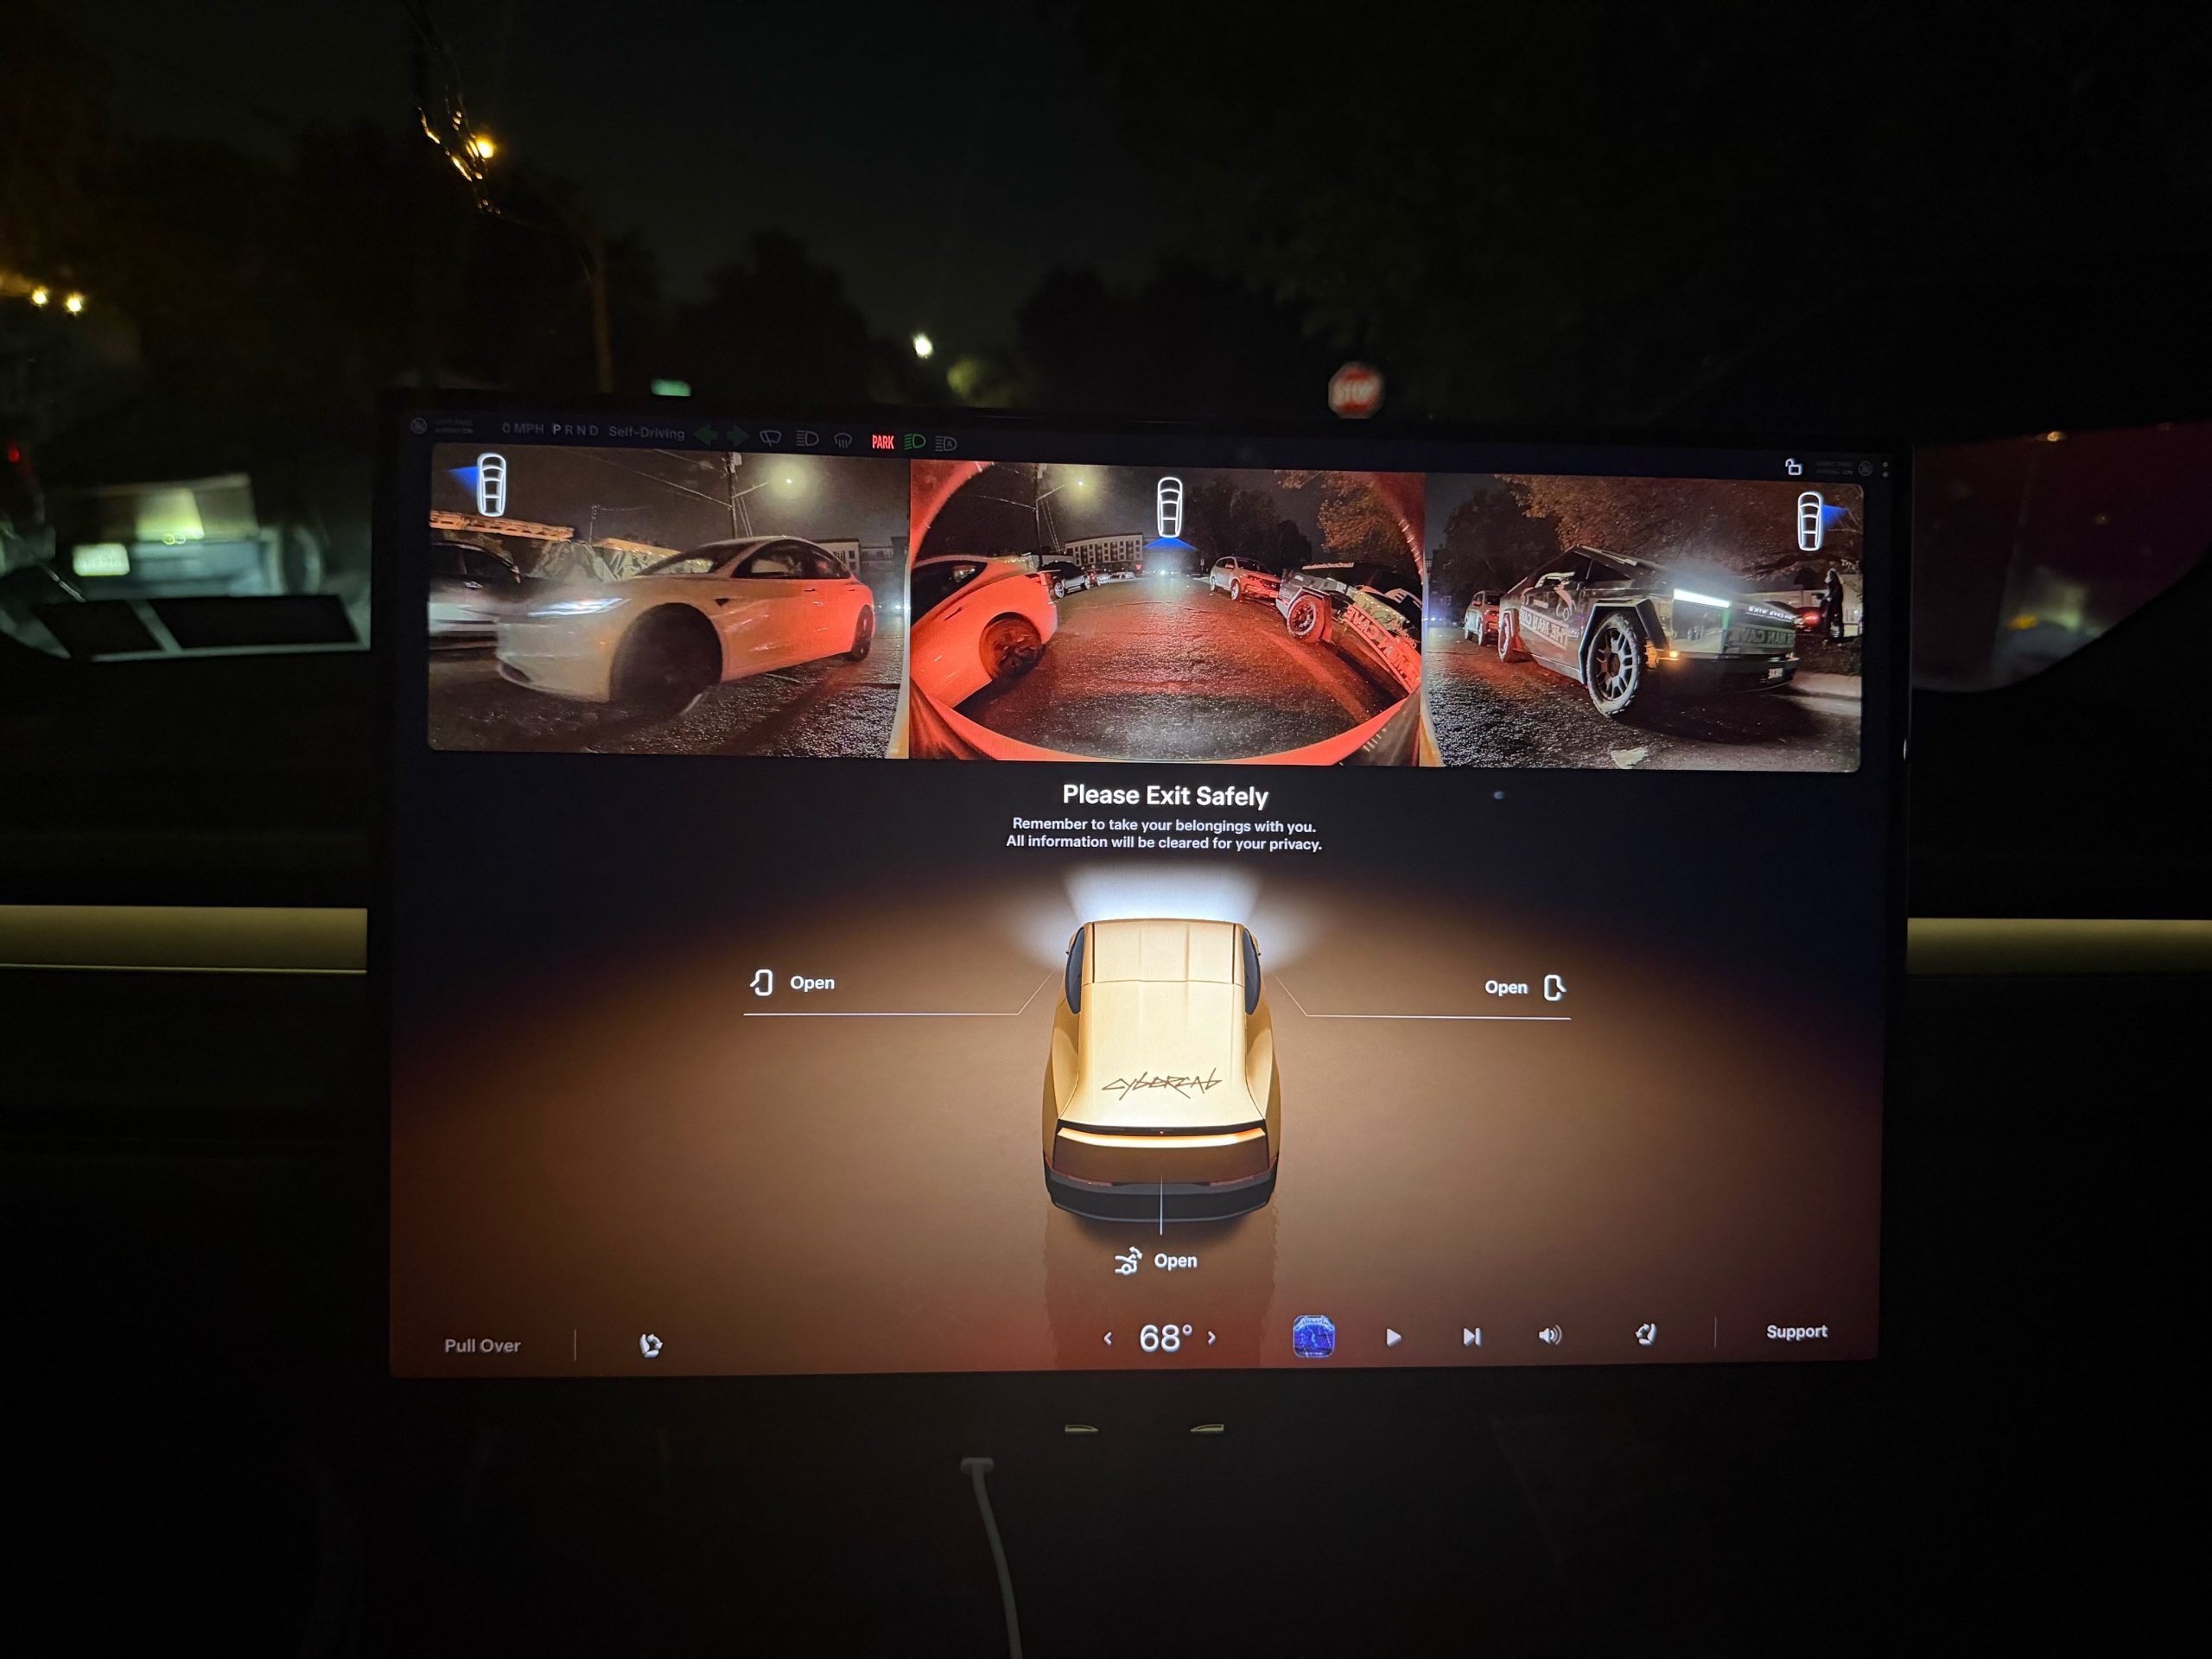
Tesla is working on a Cybercab update that would let passengers pull up the vehicle’s rear and side cameras on demand, and the request came straight from a rider.
The exchange played out on X late Friday. Cybercab rider Dan Burkland shared photos of the two-seater’s cabin screen after an evening ride, praised the UI team’s work, and left one request: let riders open the rear and repeater cameras whenever they want, “especially for peace of mind.” Tesla UI software engineer Evan (@CarCoder) answered with two words: “In development.”
The Tesla UI team absolutely crushed it with the infotainment software. Nicely done @CarCoder!
One feature request: Allow folks to pull up the rear & repeater cameras on demand. This would be great especially for peace of mind. https://t.co/mNAOSLx6pE
— Dan Burkland (@DBurkland) October 10, 2026
The idea fits a pattern Teslarati has tracked since public rides began. Days after paid Cybercab service opened in Austin, Tesla sent riders a survey that asked them to rate the touchscreen, the app and the cabin, and to pick the features they wanted most. We reported on that survey in September, and a camera view is the kind of small software change Tesla can push quickly if riders keep asking.
It also speaks to something unique about the vehicle. With no steering wheel, no pedals and no driver, passengers have no mirror to check and no way to see behind them. The hardware is clearly built for camera awareness, from the repeater cameras to the rear camera. Letting a passenger look through those same cameras would give a nervous first time rider a way to confirm what is around the car.
The timing matters because the fleet is growing fast. Tesla’s Robotaxi account said on Saturday that more than 300 Cybercabs are now serving Austin, an eightfold increase in 30 days, and Tesla AI chief Ashok Elluswamy named Dallas as the next city. More cars and more cities mean more people riding in a driverless vehicle for the first time, which is exactly when small trust features carry weight.
For now, the feature is confirmed only as in development. If Tesla follows its usual pattern with Cybercab software, riders could see it appear in a point release without any announcement, and Teslarati will watch for it.

Why Elon Musk’s target date for buying an Optimus robot is harder than it sounds

Elon Musk drops a Thanksgiving hint about Starship’s biggest test yet

Tesla’s mirrorless Cybercab will give riders a visibility upgrade

The Pentagon taps Elon Musk to design the battlefield of the future

Tesla Roadster’s new patent preps white-knuckle speeds, keeping it grounded


