News
Tesla FSD Beta 10.69 release notes highlight better left turns, smoother driving

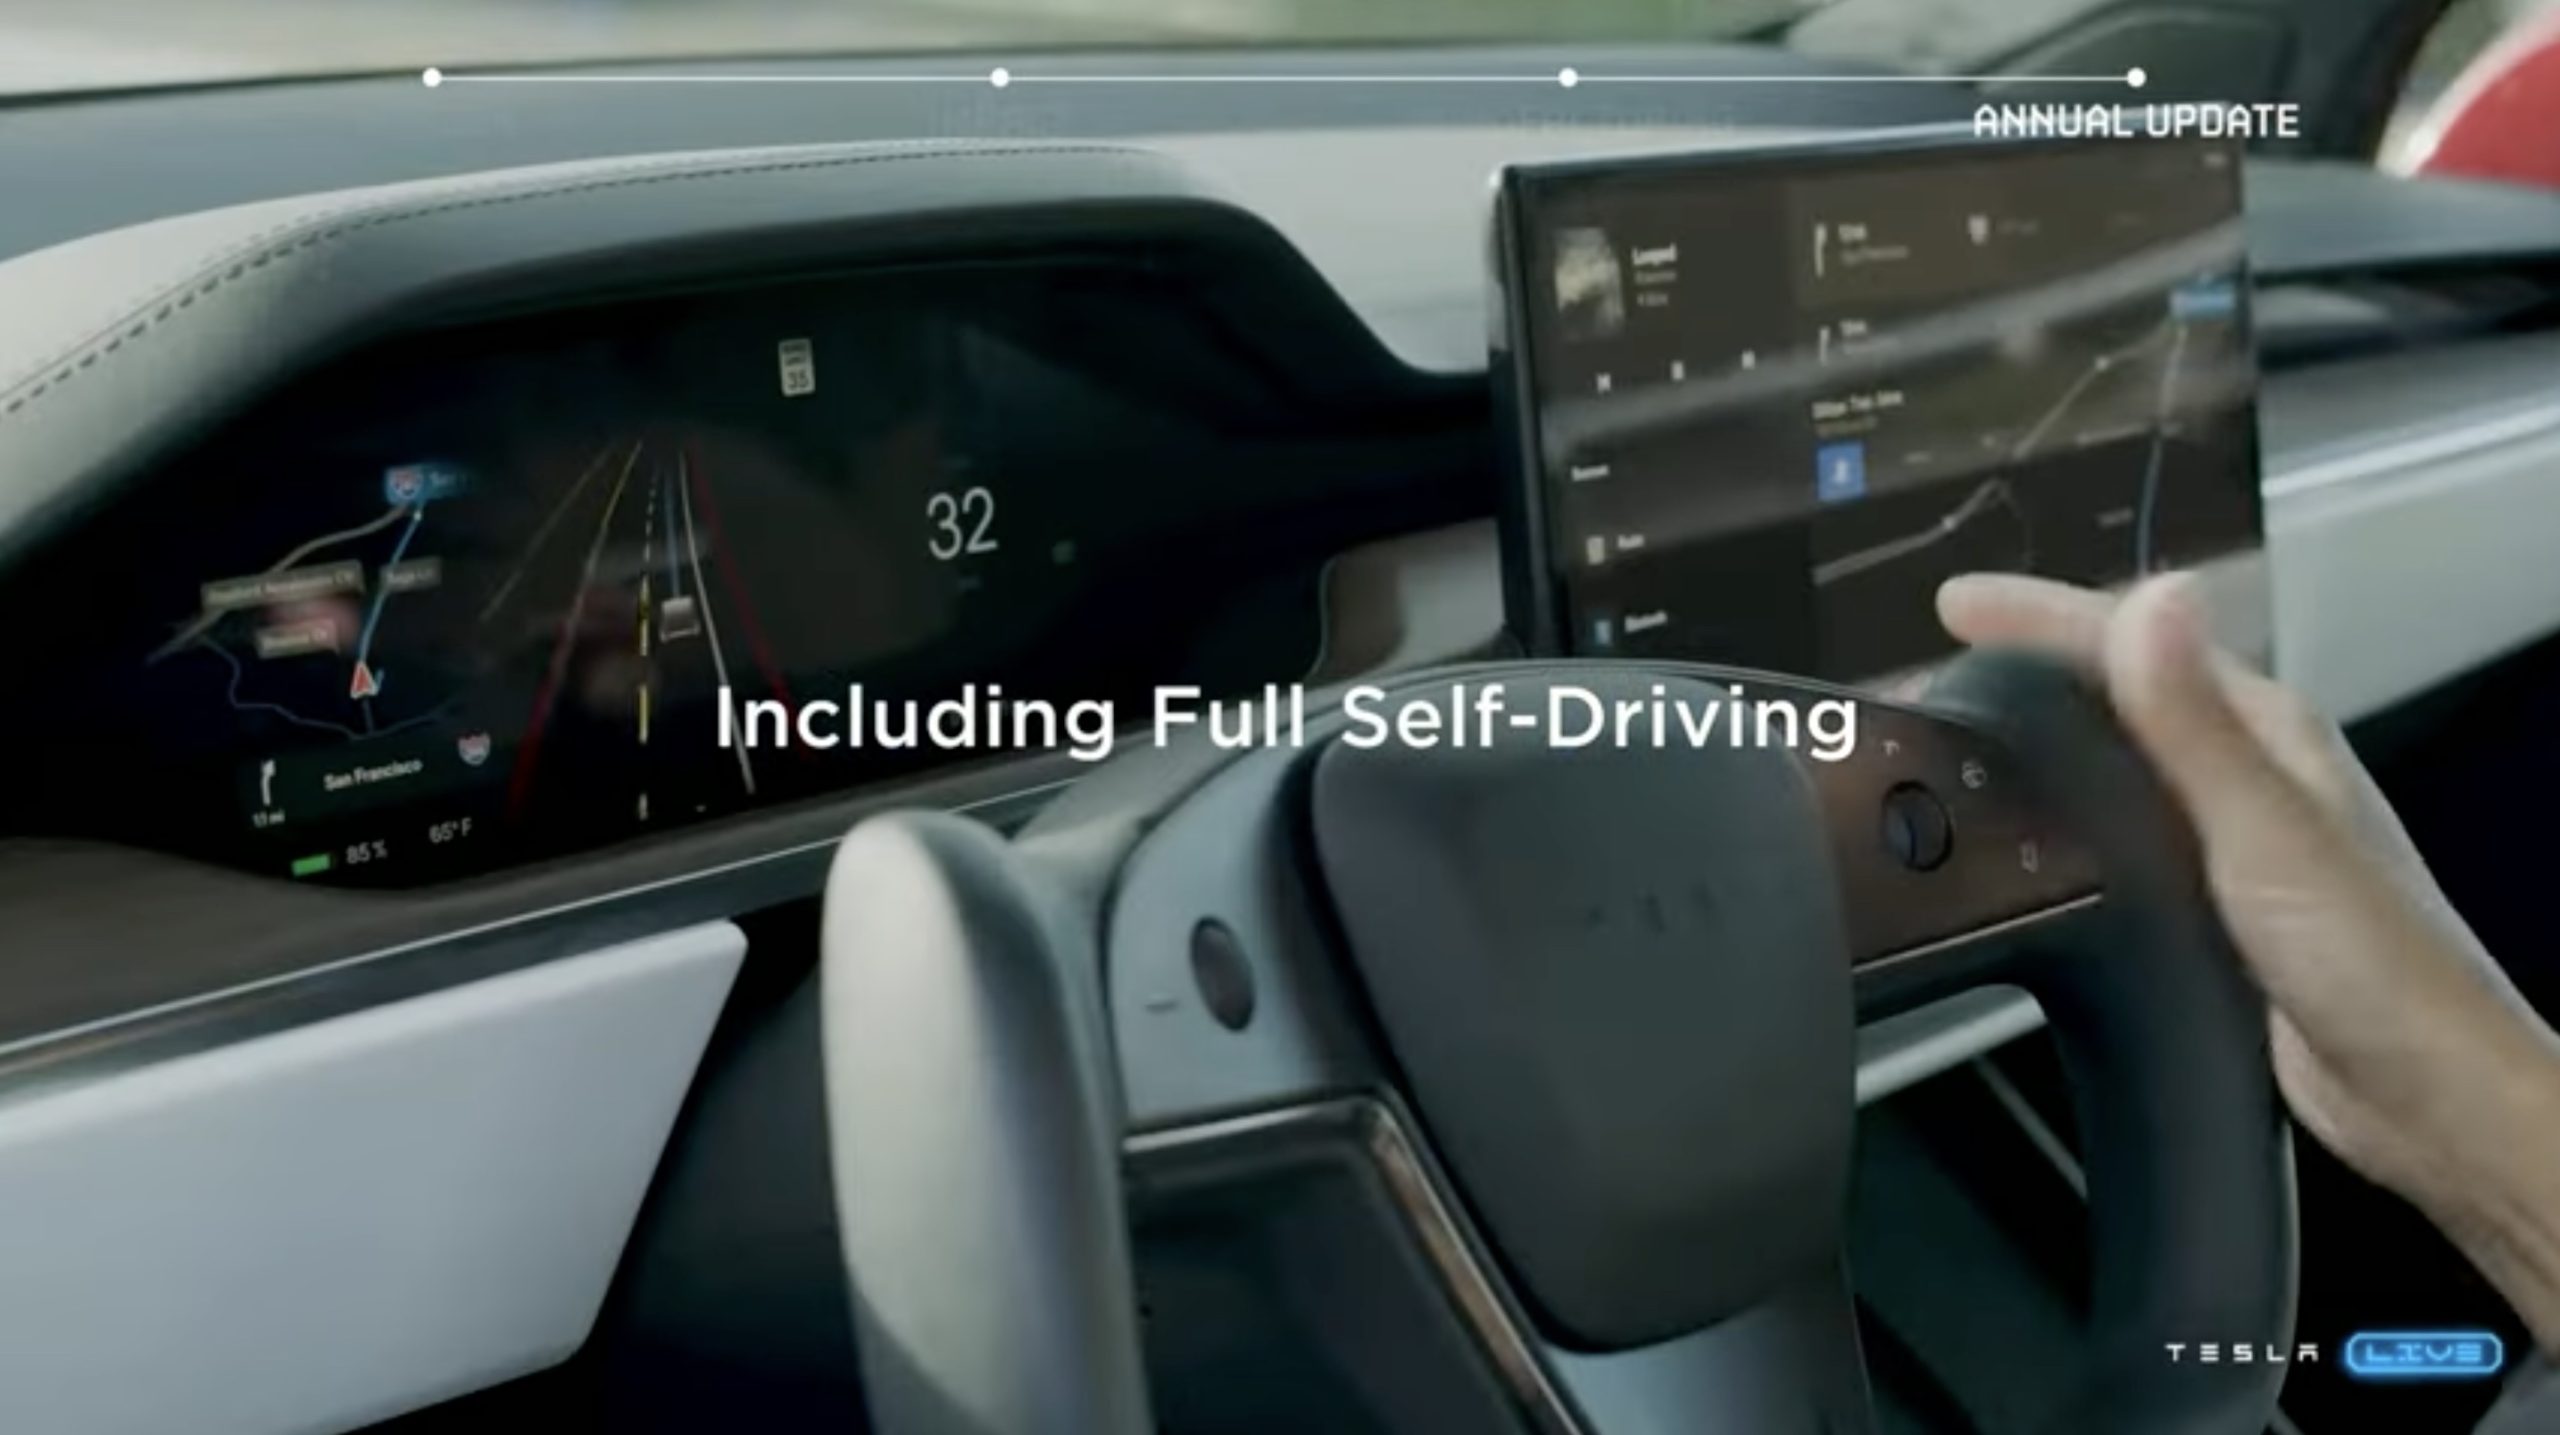
Tesla released FSD Beta 10.69 to the first round of testers over the weekend. Read v.10.69’s release notes below to check out the latest improvements.
Stay in your Lanes
- Added a new “deep lane guidance” module to the Vector Lanes neural network which fuses features extracted from the video streams with coarse map data, i.e. lane counts and lane connectivites. This architecture achieves a 44% lower error rate on lane topology compared to the previous model, enabling smoother control before lanes and their connectivities becomes visually apparent. This provides a way to make every Autopilot drive as good as someone driving their own commute, yet in a sufficiently general way that adapts for road changes.
Nothing Like Smooth Driving
- Improved overall driving smoothness, without sacrificing latency, through better modeling of system and actuation latency in trajectory planning. Trajectory planner now independently accounts for latency from steering commands to actual steering actuation, as well as acceleration and brake commands to actuation. This results in a trajectory that is a more accurate model of how the vehicle would drive. This allows better downstream controller tracking and smoothness while also allowing a more accurate response during harsh manevuers.
- Increased smoothness for protected right turns by improving the association of traffic lights with slip lanes vs yield signs with slip lanes. This reduces false slowdowns when there are no relevant objects present and also improves yielding position when they are present.
- Reduced false slowdowns near crosswalks. This was done with improved understanding of pedestrian and bicyclist intent based on their motion.
- Enabled creeping for visibility at any intersection where objects might cross ego’s path, regardless of presence of traffic controls.
- Improved accuracy of stopping position in critical scenarios with crossing objects, by allowing dynamic resolution in trajectory optimization to focus more on areas where finer control is essential.
- Reduced latency when starting from a stop by accounting for lead vehicle jerk.
Chuck’s Left Turn
- Improved unprotected left turns with more appropriate speed profile when approaching and exiting median crossover regions, in the presence of high speed cross traffic (“Chuck Cook style” unprotected left turns). This was done by allowing optimizable initial jerk, to mimic the harsh pedal press by a human, when required to go in front of high speed objects. Also improved lateral profile approaching such safety regions to allow for better pose that aligns well for exiting the region. Finally, improved interaction with objects that are entering or waiting inside the median crossover region with better modeling of their future intent.
Safety is Number 1
- Added control for arbitrary low-speed moving volumes from Occupancy Network. This also enables finer control for more precise object shapes that cannot be easily represented by a cuboid primitive. This required predicting velocity at every 3D voxel. We may now control for slow-moving UFOs.
- Made speed profile more comfortable when creeping for visibility, to allow for smoother stops when protecting for potentially occluded objects.
- Improved speed when entering highway by better handling of upcoming map speed changes, which increases the confidence of merging onto the highway.
- Enabled faster identification of red light runners by evaluating their current kinematic state against their expected braking profile.
Tesla FSD “Brain” Improvements
- Upgraded Occupancy Network to use video instead of images from single time step. This temporal context allows the network to be robust to temporary occlusions and enables prediction of occupancy flow. Also, improved ground truth with semantics-driven outlier rejection, hard example mining, and increasing the dataset size by 2.4x.
- Upgraded to a new two-stage architecture to produce object kinematics (e.g. velocity, acceleration, yaw rate) where network compute is allocated O(objects) instead of O(space). This improved velocity estimates for far away crossing vehicles by 20%, while using one tenth of the compute.
- Improved geometry error of ego-relevant lanes by 34% and crossing lanes by 21% with a full Vector Lanes neural network update. Information bottlenecks in the network architecture were eliminated by increasing the size of the per-camera feature extractors, video modules, internals of the autoregressive decoder, and by adding a hard attention mechanism which greatly improved the fine position of lanes.
- Improved recall of animals by 34% by doubling the size of the auto-labeled training set.
- Increased recall of forking lanes by 36% by having topological tokens participate in the attention operations of the autoregressive decoder and by increasing the loss applied to fork tokens during training.
- Improved velocity error for pedestrians and bicyclists by 17%, especially when ego is making a turn, by improving the onboard trajectory estimation used as input to the neural network.
- Improved recall of object detection, eliminating 26% of missing detections for far away crossing vehicles by tuning the loss function used during training and improving label quality.
- Improved object future path prediction in scenarios with high yaw rate by incorporating yaw rate and lateral motion into the likelihood estimation. This helps with objects turning into or away from ego’s lane, especially in intersections or cut-in scenarios.
Tesla is rolling out FSD Beta v.10.69 in phases, starting with ~1,000 testers over the weekend. Once the update is rolled out for wide release, the price of FSD Beta will increase.
The Teslarati team would appreciate hearing from you. If you have any tips, contact me at maria@teslarati.com or via Twitter @Writer_01001101.

News
Tesla Robotaxi app update now tells riders if Cybercab is the better choice
Tesla’s Robotaxi app now shows ETAs, wait times and availability for Cybercab and Model Y.

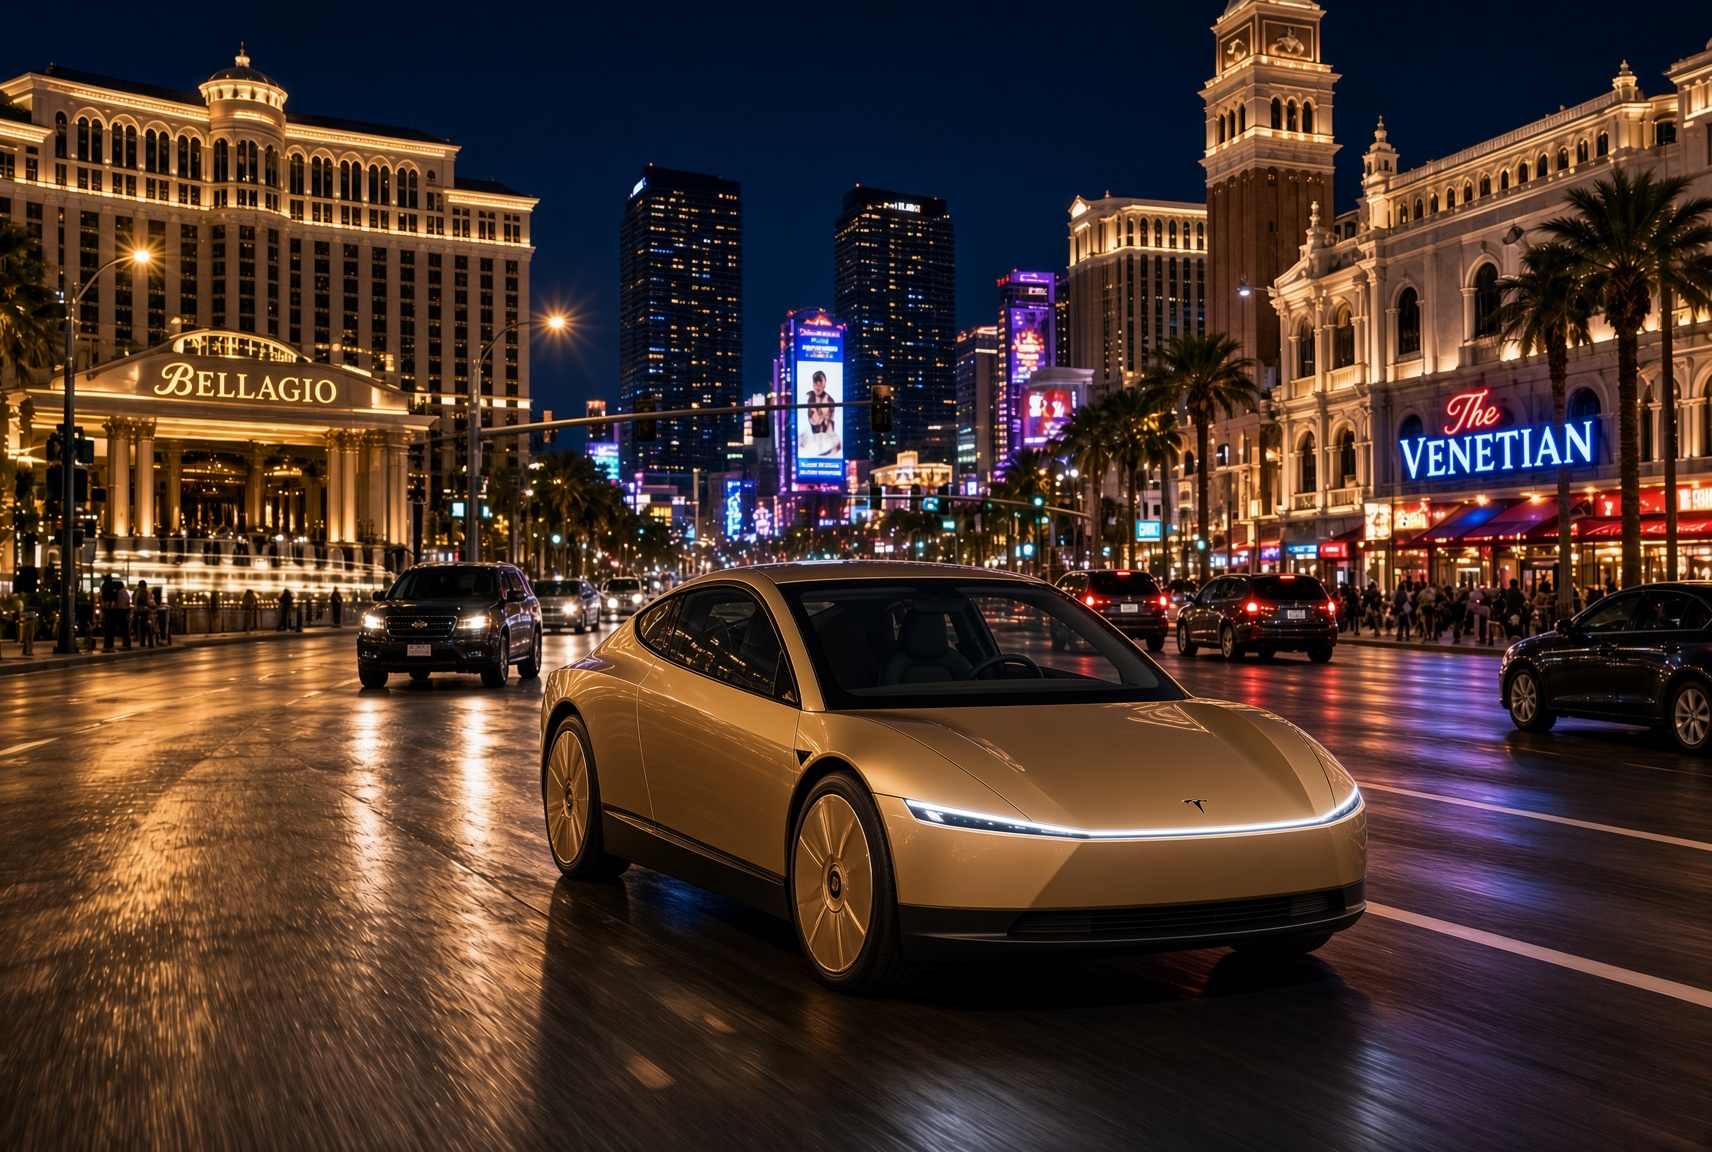
Tesla has rolled out a new vehicle selection screen in its Robotaxi app, and it puts the numbers riders care about most in front of them before they book.
Version 26.11.0 of the app shows the estimated arrival time, the expected wait and current availability for each vehicle option on a single screen, according to a video shared by @gheeunit on X on November 7. Riders deciding between a Cybercab and a Model Y Robotaxi can now compare those figures side by side instead of picking a car first and learning how long it will take afterward.
Tesla first gave riders that choice on September 3, the day paid Cybercab rides began in Austin. The original version of the screen listed the Cybercab, which seats two, next to the Model Y, which seats four. A later build, 26.8.2, added a seating capacity indicator so groups knew which car would fit them. What it did not show was whether choosing the Cybercab meant standing on the curb a few extra minutes.
Newest version of @robotaxi app has a new vehicle selector UI for choosing between Cybercab and Model Y and shows you the fare for both simultaneously! https://t.co/7qoDQ0vACX — mantequilla 🧈 (@gheeunit) November 7, 2026
That question matters more now than it did two months ago. Tesla had 45 Cybercabs on the Texas DMV roster when rides started. By late October the state listed 573, alongside 631 Model Ys, and community trackers logged a record 1,576 Cybercab sightings across Austin on Halloween alone. With two large fleets sharing one service area, the closest car and the quickest pickup are not always the same vehicle.
Inline availability also changes what happens when demand spikes. If no Cybercab is free nearby, the rider sees that on the selection screen rather than after trying to book one.
For now the comparison is mostly an Austin feature. Riders in Dallas, Houston, Fort Worth and the Florida markets are still matched with Model Y vehicles, though Tesla said on its third quarter earnings call that Cybercab rides would launch in Dallas this month.
The update follows a steady run of smaller changes to the rider experience. Late last month Tesla brought a quiet mode that blacks out the cabin screen to Model Y Robotaxis after first testing it in the Cybercab, and it has stretched Austin service to run from 6 a.m. to 2 a.m.
The Cybercab side of that selection screen is about to get much busier. Elon Musk said this week that Tesla will wind down Cybertruck production at Gigafactory Texas around the middle of 2027 to make room for more Cybercab output, and Tesla has said it is aiming to get Cybercabs to customers by the end of this year.
Tesla has not published official release notes for version 26.11.0.

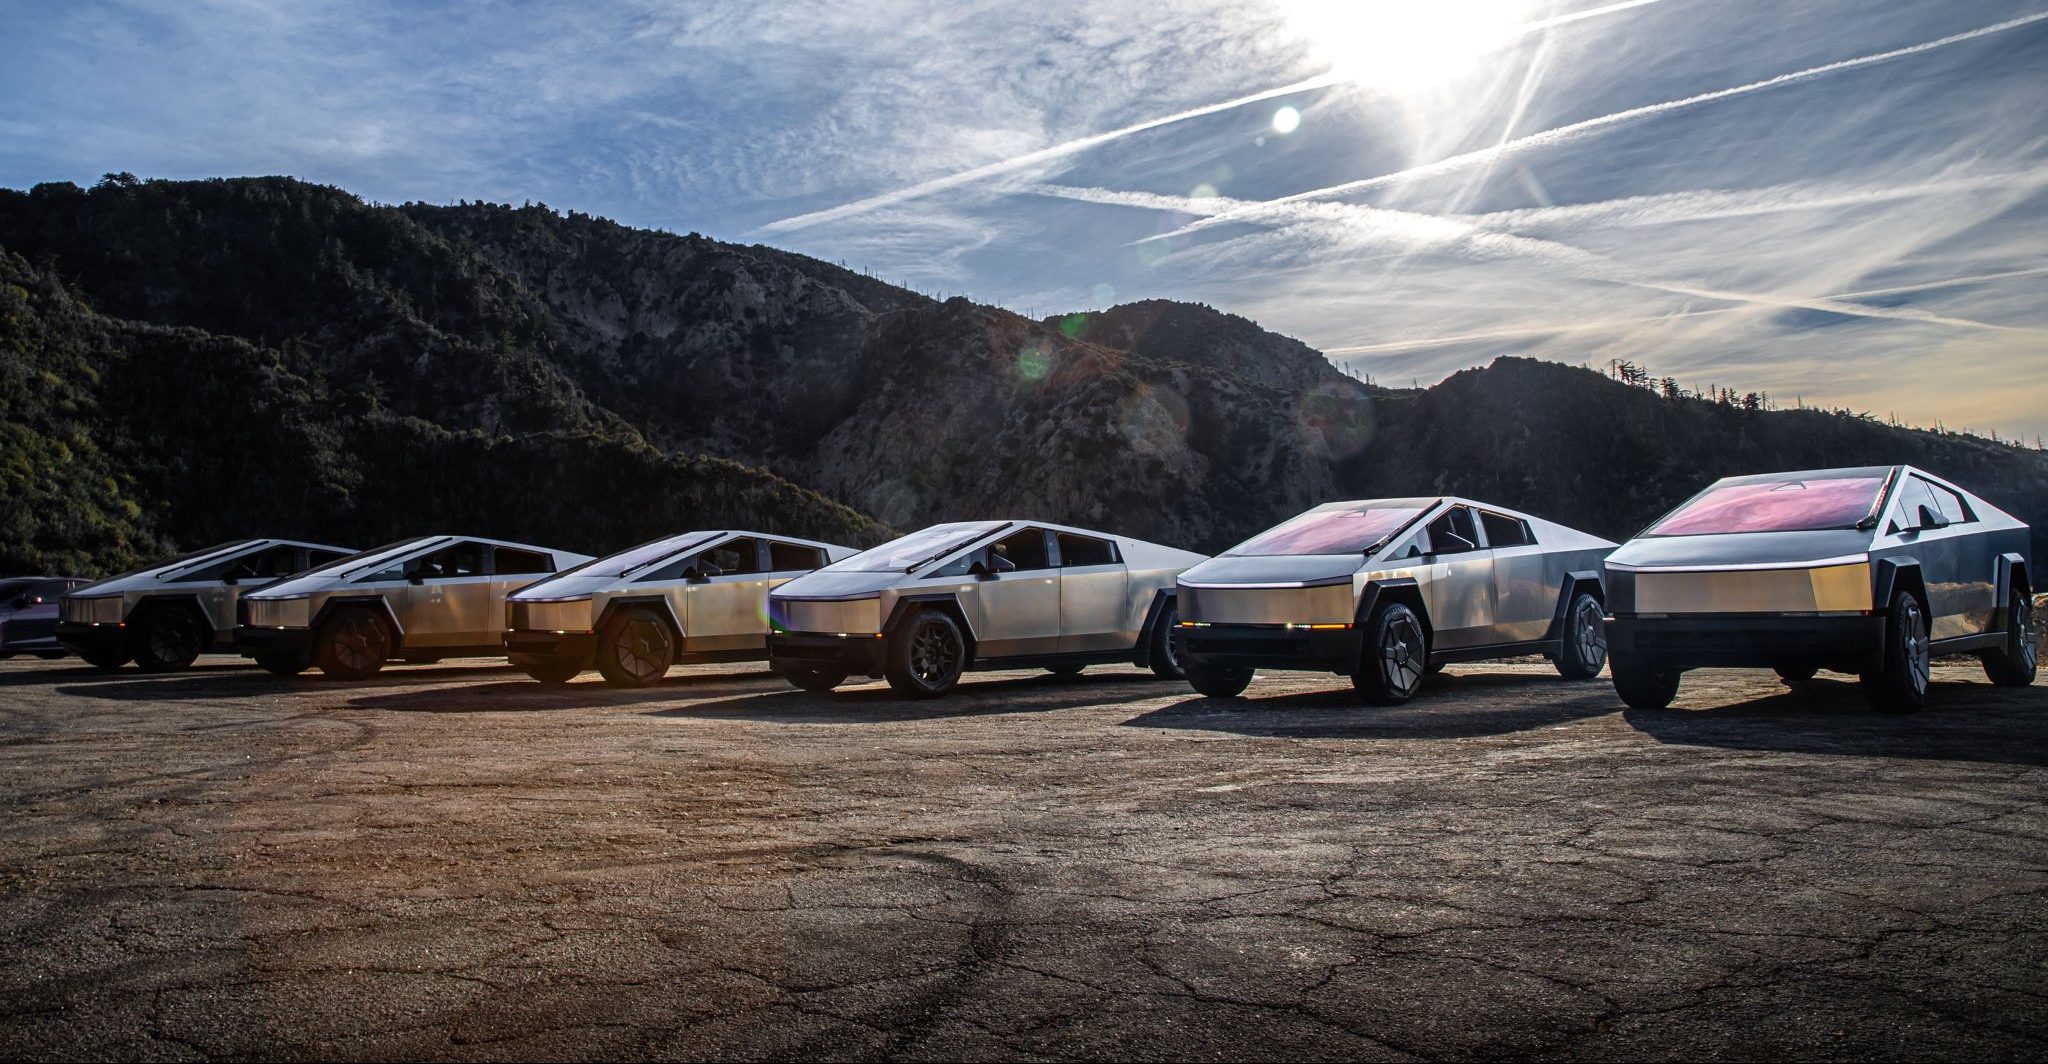
Tesla is ending Cybertruck production sometime in mid-2027, according to CEO Elon Musk.
Musk made the announcement on X last night, which came as a shock to many. He said that the Cybertruck will end production “to make room for increased Cybercab production” at Gigafactory Texas.
It is a huge blow to the fans of Tesla who have come to love the Cybertruck and identify with it as a symbol of their fandom. It has been the best-selling electric pickup, but it has had an underwhelming sales performance in terms of what was expected. This is mostly due to Tesla not meeting the prices it planned to offer the Cybertruck, as its unveiling and actual release were four years apart.
Tesla will be winding down production of the Cybertruck at Gigafactory Texas around the middle of next year to make room for increased Cybercab production
— Elon Musk (@elonmusk) November 6, 2026
Overall, the responses were mixed. Some fans understood the move toward Cybercab production, especially as Tesla is truly pushing the autonomous future through its Robotaxi platform. However, others did not understand it.
“Damn, how many Cybercabs do you guys need?” one response read. Another said it was “Sad but understandable.”Even analyst Gary Black had responded to the news, stating he hoped Tesla planned to replace it with a traditional pickup design.
It doesn’t seem like that will be the case.
Tesla is so hell-bent on delivering autonomy and eventually providing a driverless service that owning a car seems like an arbitrary idea, according to their thesis. Instead, Cybercabs will be available to pick you up and drop you off on demand, safely, without any human help.
As a result, Tesla has thinned its lineup considerably, and one can only ask where the vehicle lineup goes from here. Eventually, it seems like Cybercab could be the only vehicle that Tesla will sell.
Elon Musk
SpaceX’s next Starship flight set to make history on Friday the 13th
SpaceX is targeting Friday, November 13 for Starship Flight 15 and its first ship catch.
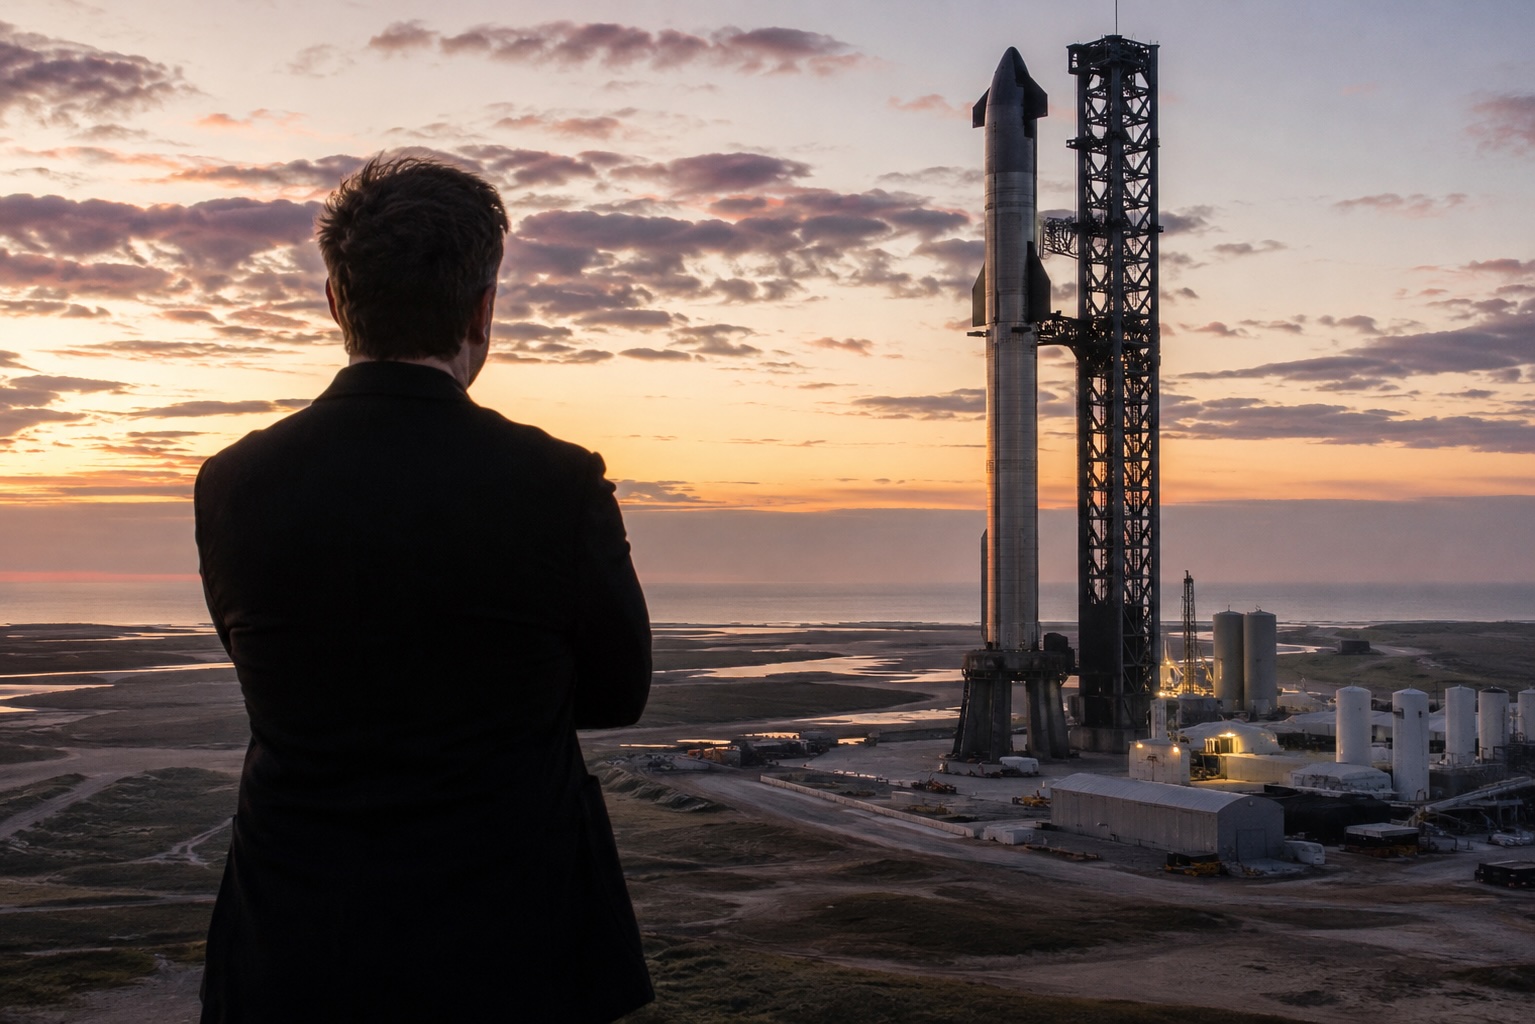
SpaceX is targeting Friday, November 13 for Starship Flight 15, the mission the company plans to use for its first attempt at catching the ship itself with the launch tower.
SpaceX Vice President of Launch Kiko Dontchev shared the date on stage at the UP.Summit on Thursday, according to Ars Technica’s Eric Berger, who was in attendance. It is the first launch target to come directly from a SpaceX executive. Until now, the public schedule had relied on FAA air traffic planning slides, which listed Flight 15 for no earlier than November 8 and later November 12. SpaceX has not posted an official mission page yet, and no launch time has been shared.
The date lands inside the window Elon Musk sketched out last month. Speaking at Giga Texas on October 10, Musk said the flight would “probably launch a little bit before Thanksgiving,” as Teslarati reported. On SpaceX’s third quarter earnings call ten days later, he confirmed that Flight 15 would try to catch both the Super Heavy booster and the ship, and put the odds of a successful ship catch at “more likely than not.” SpaceX also aired an animation of the maneuver during that webcast, showing the ship swinging vertical over Starbase before dropping into the tower’s chopsticks.
The hardware is ready. Booster 22 fired all 33 of its Raptor engines for a full duration static fire at Pad 2 on October 25. Ship 42 followed with a single engine burn simulating a deorbit maneuver on October 26 and a 60 second firing of all six engines the next day, according to NASASpaceflight. Ship 42 had already rehearsed the catch in September, when the Pad 2 arms lifted it into position and crews connected the quick disconnect arm while the vehicle hung from the tower.
The remaining hurdle is regulatory. The FAA’s Starship page does not yet list a Flight 15 license. SpaceX President Gwynne Shotwell said in October that, after “significant constructive engagement with the FAA,” she expects the license to cover a return to the launch site and a tower catch for both stages. Bringing the ship home means a reentry path that heads toward land, rather than ending over open ocean as every Starship flight so far has.
SpaceX has caught Super Heavy three times, on Flights 5, 7 and 8, but the ship comes back from orbital velocity and has never been caught. Flight 14 on September 28 was the first Starship to reach orbit, deploying 26 Starlink V3 satellites before splashing down despite an early engine shutdown that Musk blamed on engine computer software.
Musk has called a successful ship catch “the first time that there’s been full recovery of an orbital class rocket,” and he has already named the step after it: a Flight 16 where both the booster and the ship fly again. NASASpaceflight reports that Ship 43, the next vehicle in line, is set for static fire testing in December.

Tesla Robotaxi app update now tells riders if Cybercab is the better choice

Tesla is ending Cybertruck production


