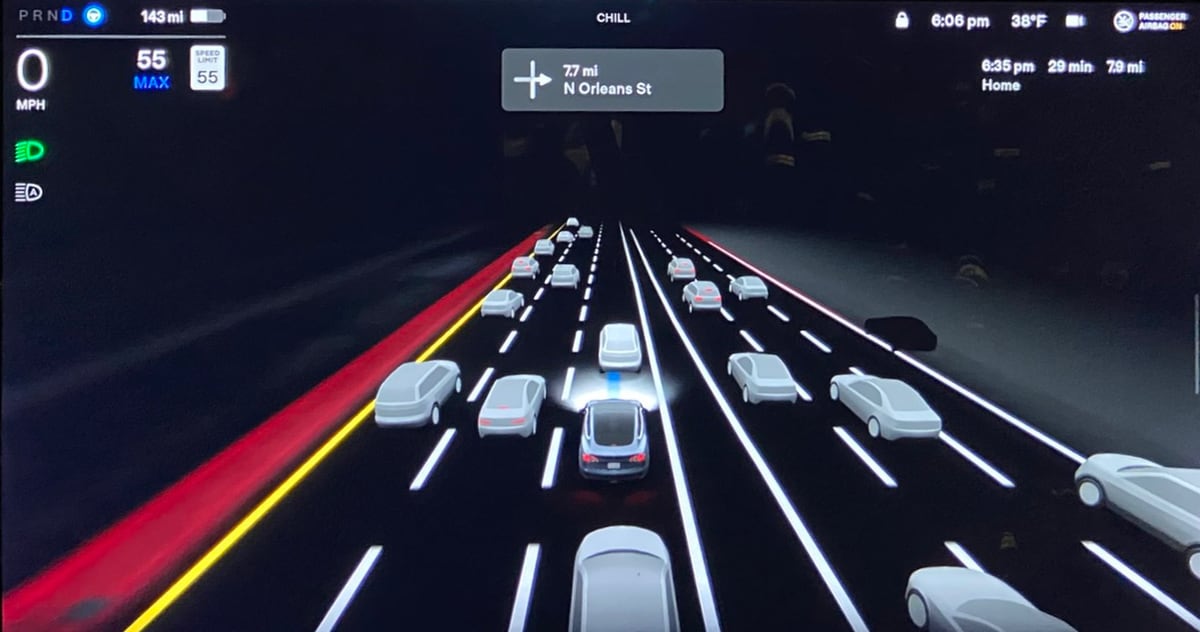

On the 11th of November, at 11:11 p.m. PST, Tesla started the initial rollout of FSD Beta V11. The update was extremely exciting, in no small part due to the fact that it represented the first iteration of Tesla’s Full Self-Driving Beta that utilizes a single stack.
Tesla, however, has been very cautious with the rollout of FSD Beta V11. Days passed, and numerous FSD Beta testers were yet to receive the highly-anticipated update. Elon Musk later noted that a wider release of V11 should happen before Thanksgiving.
Details of the changes present in FSD Beta V11 are scarce, especially since only partial release notes of the update were shared online. That is, at least, until now. Thanks to the efforts of longtime FSD Beta testers such as @WholeMarsBlog, the full release notes of Tesla’s V11 update are now publicly available.
Following are the full release notes of Tesla’s FSD Beta V11.
FSD Beta V11 Release Notes
-Enabled FSD Beta on highway. This unifies the vision and planning stack on and off-highway and replaces the legacy highway stack, which is over four years old. The legacy highway stack still relies on several single-camera and single-frame networks, and was setup to handle simple lane-specific maneuvers. FSD Beta’s multi-camera video networks and next-gen planner, that allows for more complex agent interactions with less reliance on lanes, make way for adding more intelligent behaviors, smoother control and better decision making.
– Improved Occupancy Network’s recall for close by obstacles and precision in severe weather conditions with 4x increase in transformer spatial resolution, 20% increase in image featurizer capacity, improved side camera calibration, and 260k more video training clips (real-world and simulation).
– Improved merging behavior by leveraging lane geometry and lane bounds, association with coarse map information and better gap selection algorithms, allowing for a smoother and safer experience.
– Added highway behavior to offset away from blocked lanes and generic obstacles like road debris while also adding a smooth hand- off between in-lane offsetting and lane changing.
– Improved speed-based lane change decisions to better avoid slowing down traffic in fast lanes, and interfere less with navigation.
– Reduced sensitivity for speed-based lane changes in CHILL mode.
– Improved lane changes to allow higher jerk maneuvers if required to stay on-route or to move away from lane blockages.
– Improved smoothness at highway lane splits by being less strict about centering between lane lines and allowing lower jerk maneuvers, where safe to do so.
– Reduced latency of trajectory optimization by 20% on average, without sacrificing behavior, by leveraging numerical tricks for more efficient computations.
Press the “Video Record” button on the top bar UI to share your feedback. When pressed, your vehicle’s external cameras will share a short VIN-associated Autopilot Snapshot with the Tesla engineering team to help make improvements to FSD. You will not be able to view the clip.
For now, video demonstrations of FSD Beta V11’s capabilities are yet to populate video sharing sites such as YouTube. With the update poised for a wider release in the coming weeks, however, it’s only a matter of time before stress tests and demonstrations of FSD Beta V11 in action are shared online.
Don’t hesitate to contact us with news tips. Just send a message to simon@teslarati.com to give us a heads up.

Investor's Corner
Tesla has a Cybercab problem nobody saw coming
Tesla’s Cybercab line now builds robotaxis faster than Tesla can deploy them, Lars Moravy says.

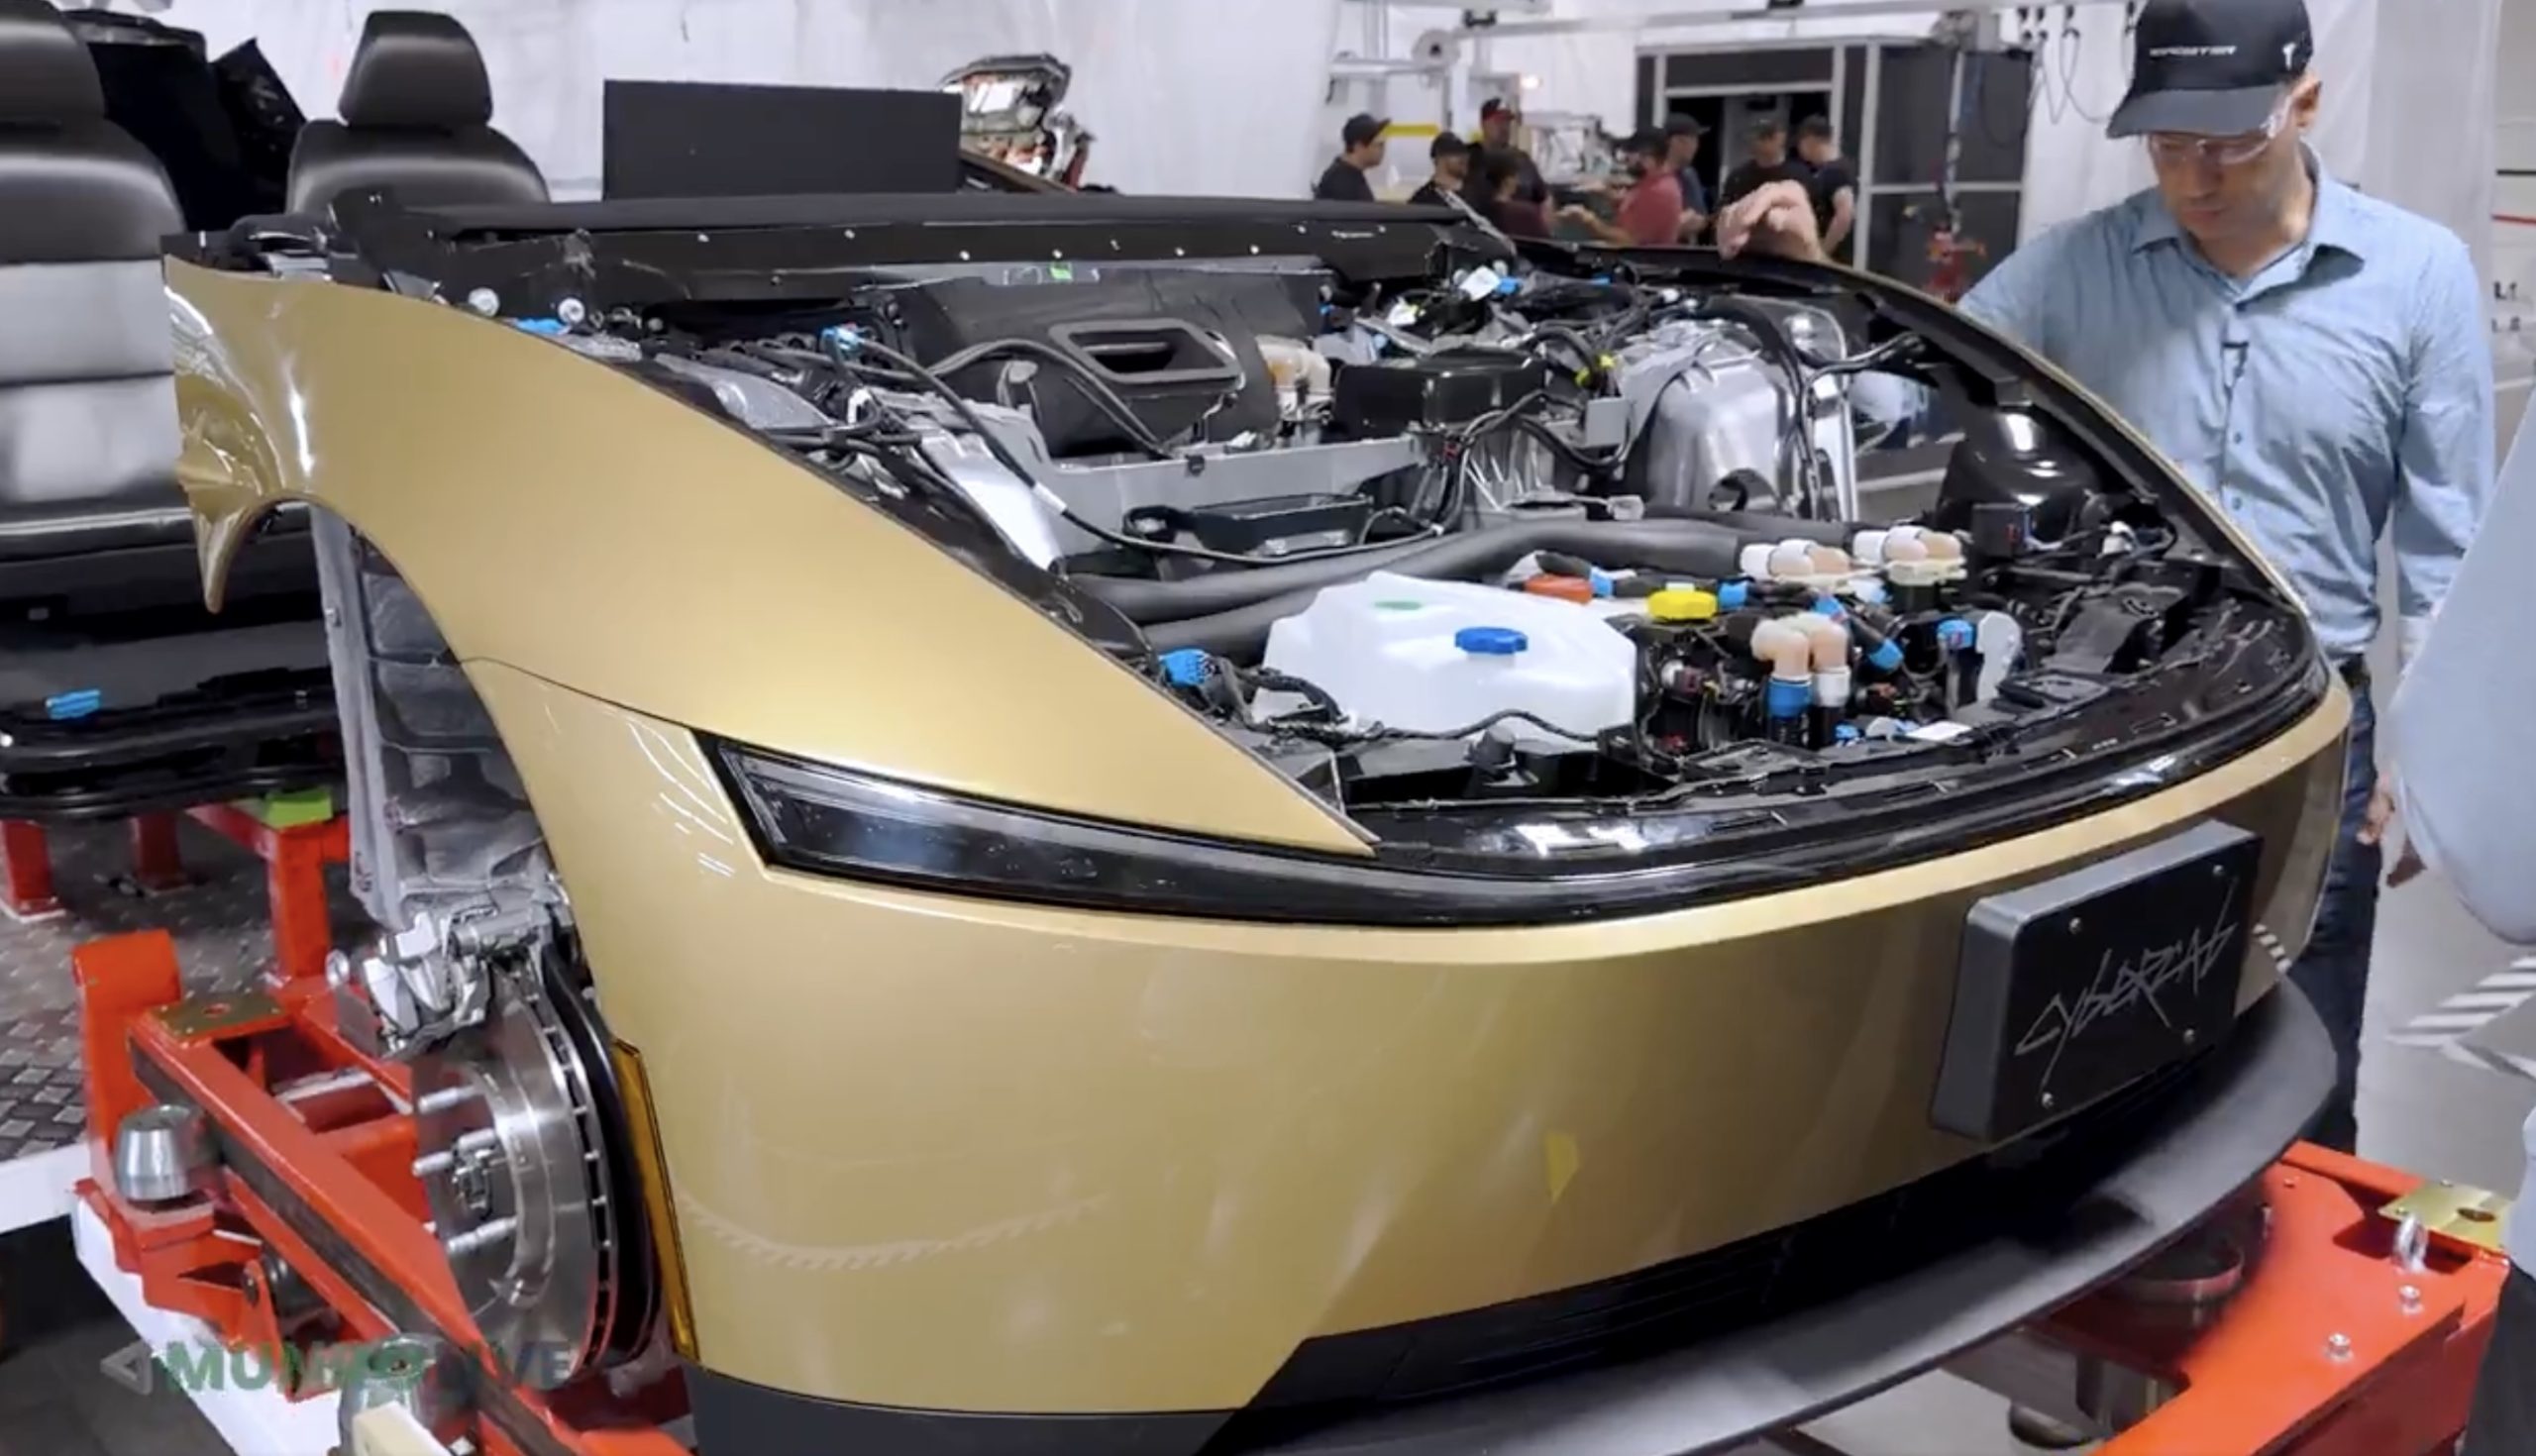
Tesla’s Cybercab line in Texas can now build the two seat robotaxi faster than the company can put it into service, according to Lars Moravy, Tesla’s Vice President of Vehicle Engineering. “We don’t run every day because the line can run so fast. It’s currently outpacing our deployments,” Moravy said in a new Cybercab deep dive from Munro Live. “So, it’s a bit of a race right now. Who’s going to go faster? Right now the manufacturing line’s ahead.”
Tesla’s official Robotaxi account shared a Cybercab analysis video on X on Monday, calling it a “Cybercab engineering deep dive.” Moravy’s comments go further than what he told analysts on the Q3 earnings call last week, when he said the Cybercab line’s listed capacity of more than 125,000 units a year undersells what it can actually run.
The tour shows where that speed comes from. Tesla’s unboxed process splits the Cybercab into front, rear, side and center modules that are built and tested on their own before they meet on a short final line. That final line has just 25 fully automated stations, which Tesla’s team estimated is a fifth to a tenth of what a Model Y needs. The full line is about 78% automated, the framing line is already at 100%, and the layout uses roughly 50% less floor space per vehicle. The stated goal is “100% automation in 10 second cycle time,” or one finished Cybercab every 10 seconds.
Tesla also deleted the paint shop. Only the side modules are coated, and the exterior panels get their color inside the molding machine. Engineers said the car is designed to run at least 500,000 miles, which matters for a vehicle that will spend most of its day carrying riders.
The battery got the same treatment. The Cybercab uses an 88S6P pack of 4680 cells in a steel enclosure, a first for Tesla, with each module potted separately so a single failed module can be swapped instead of the whole pack. Wireless battery management boards replace a wiring harness, and new contactors are fast enough to drop the pyro fuse entirely. Tesla’s battery director graded the pack an A minus, compared with a D for the Model Y structural pack and a B minus for Cybertruck. Up front, the drive unit runs an 11:1 gear ratio versus roughly 9:1 on most Teslas, since the Cybercab does not need a high top speed.
Cybercab engineering deep dive — Robotaxi (@robotaxi) October 26, 2026
The deployment side is now the bottleneck Moravy described. Tesla had more than 50 Cybercabs working the Formula 1 weekend in Austin, and Texas records show 463 Cybercabs registered. Tesla said on its earnings call that Cybercab service will launch in Dallas next month, and Moravy said the company is aiming to get Cybercabs to customers by the end of 2026. Every unit built so far has gone into Tesla’s own fleet since the line moved into volume production in April.
Munro Live also asked when it could get a Cybercab to tear down. Tesla’s answer: “Not yet.”

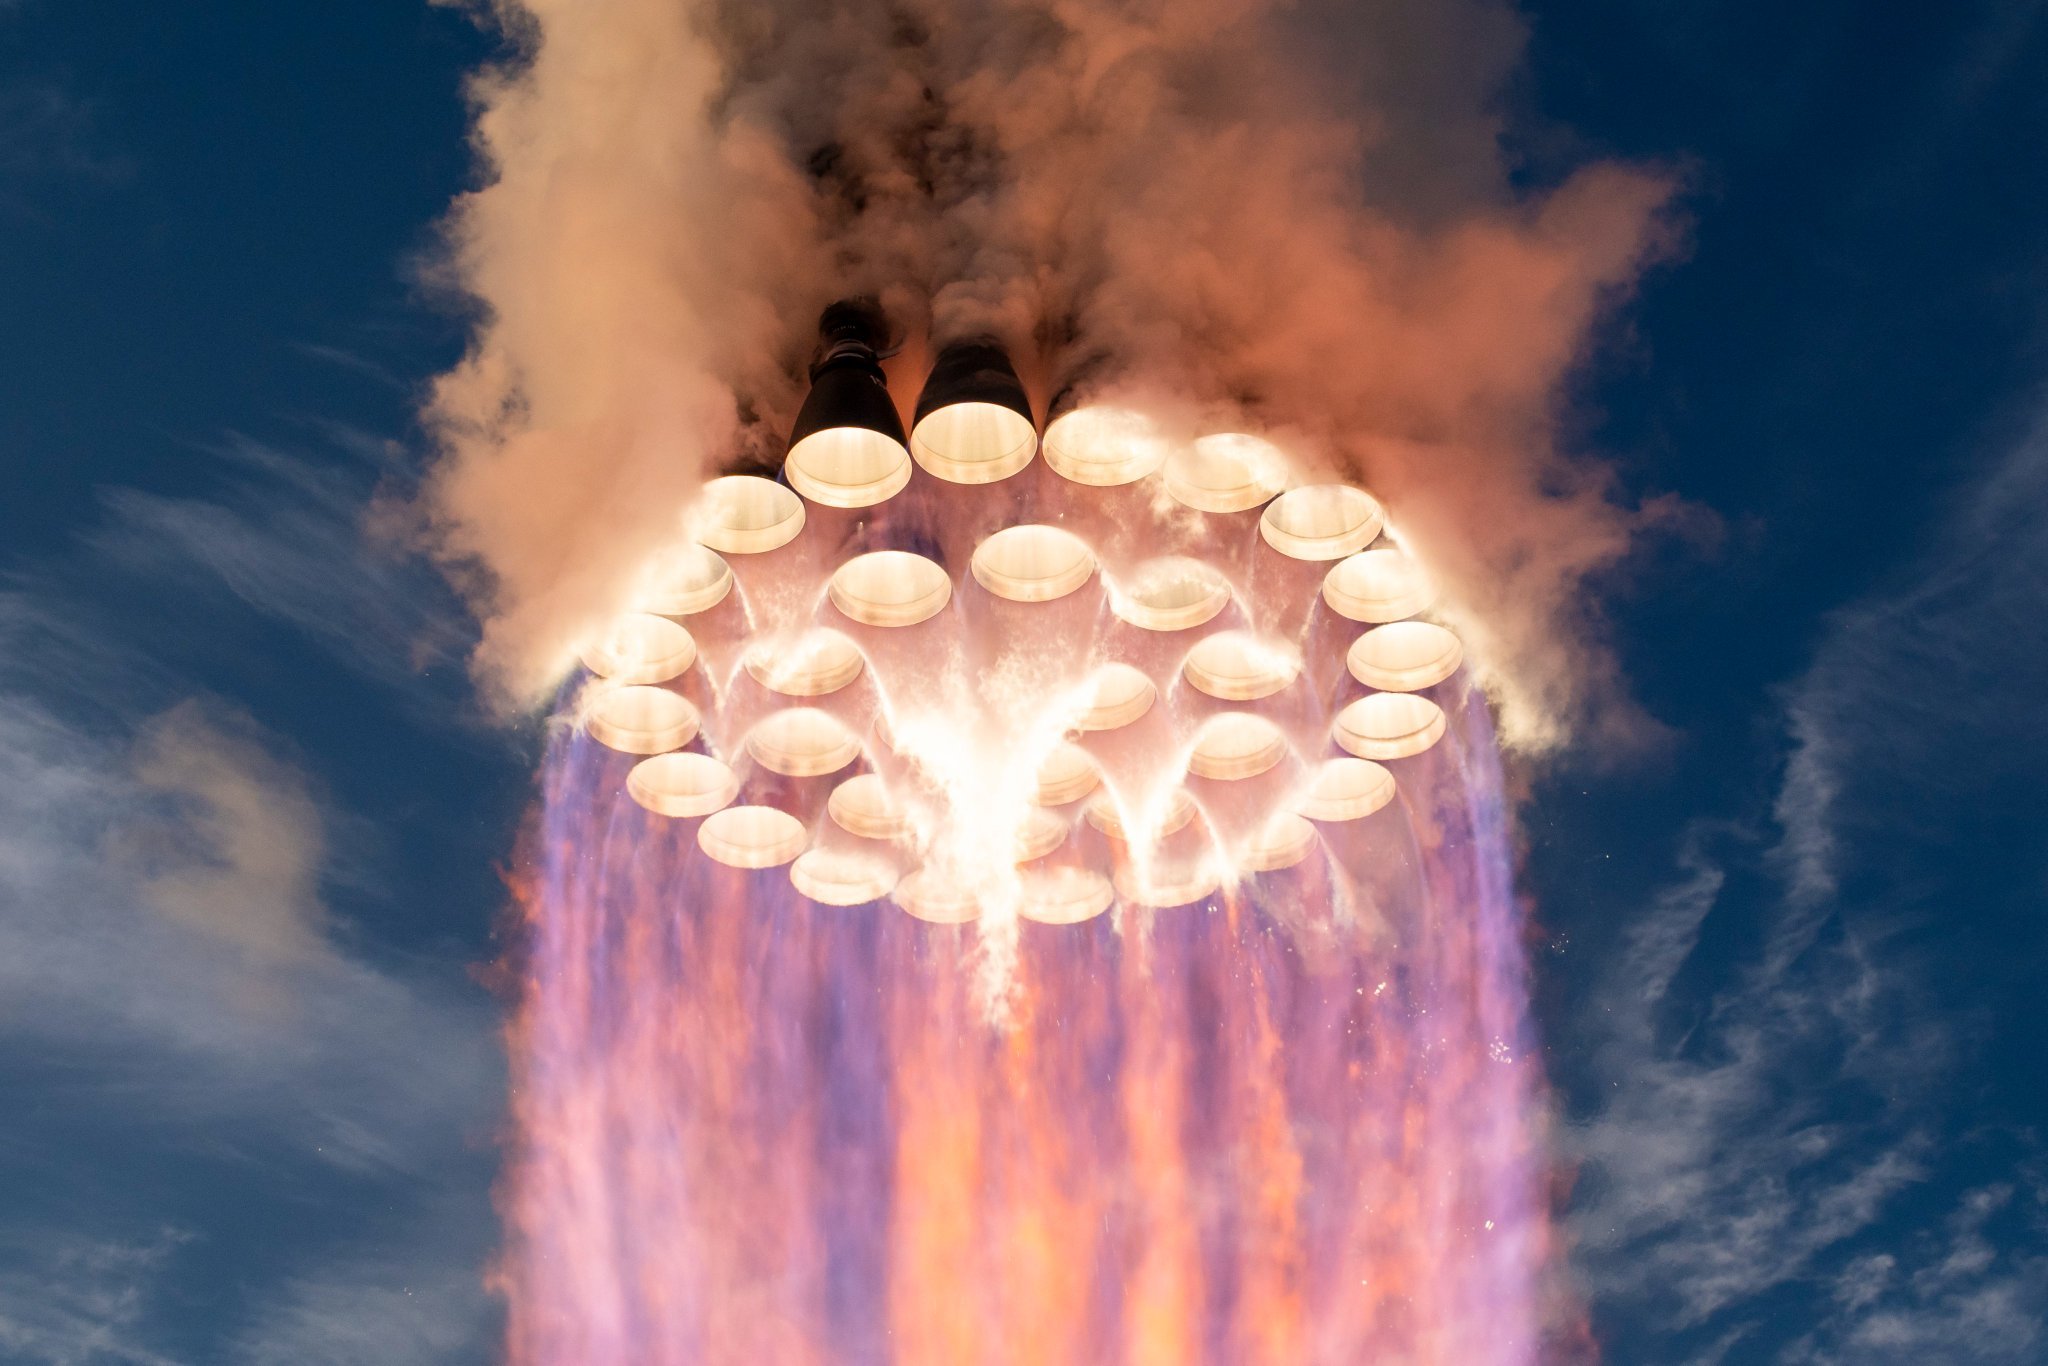
SpaceX’s Raptor engine family has steadily increased sea-level thrust while simultaneously reducing mass, turning iterative engineering gains into substantially higher performance for the Super Heavy booster. CEO Elon Musk shed more light on how powerful Raptor 4 will be, and it’s pretty crazy.
Raptor 1 delivered 185 metric tons of thrust at roughly 2,080 kilograms, while Raptor 2 raised that to 230 tons while cutting mass to about 1,630 kilograms. SpaceX data for Raptor 3 lists a target of 280 tons at 1,525 kilograms (with further reductions in associated vehicle hardware), while operational flight ratings have been cited near 250 tons.
This morning, Elon Musk stated that Raptor 4 is expected to reach 300 tons of sea-level thrust at roughly the same mass as Raptor 3. Across these versions, thrust has risen by more than 60 percent from the first engines while engine mass has fallen, producing a sharp improvement in thrust-to-weight ratio. This is a true testament to how great SpaceX engineering has been:
🚀 Elon says Raptor 4 will make 300 tons of thrust at sea level at roughly the same mass as Raptor 3.
How far Raptor has come:
Raptor 1: 185 tf, 2,080 kg
Raptor 2: 230 tf, 1,630 kg
Raptor 3: 250 tf, 1,525 kg
Raptor 4: 300 tf33 on Super Heavy = ~9,900 tf, nearly 3x Saturn V https://t.co/HQDswZhyvL
— TESLARATI (@Teslarati) October 26, 2026
With 33 engines on SuperHeavy, the jump from earlier versions to a 300-ton Raptor 4 would produce roughly 9,900 metric tons of total liftoff thrust, nearly three times the Saturn V’s approximately 3,400 metric tons from its five F-1 engines.
This is not just a larger number on a data sheet, either, as sea-level thrust is the force available the moment the vehicle leaves the pad. This is when it is heaviest and still deep in Earth’s gravity well and dense atmosphere.
Higher levels of sea-level thrust directly improves the initial thrust-to-weight ratio of the full stack. A higher ratio produces faster acceleration off the pad, which shortens the time the rocket has to spend fighting gravity, and gravity losses during the first minute or two of the flight are a major drain on total available delta-v. Every second shaved off of that early climb preserves more propellant energy for reaching orbital velocity or for carrying extra payload.
Because Super Heavy’s engine count is constrained by vehicle diameter and packing density, increasing thrust per engine is the most straightforward way to raise total liftoff performance without redesigning the booster structure or design.
The same-mass target for Raptor 4 is equally important. Holding engine mass roughly constant while raising thrust improves the engine’s own thrust-to-weight ratio and reduces the structural and propellant mass fraction that must be carried solely to support the engines.
Earlier Raptor iterations also simplified or eliminated extensive vehicle-side hardware such as heat shields. These gains compound: more force for less installed mass leaves additional capacity for propellant, payload, or operational margins such as engine-out capability.
For Starship’s architecture, the practical effects are large. Greater liftoff thrust supports heavier vehicles, larger propellant loads, and higher payloads to low Earth orbit, figures SpaceX has targeted in the 100-plus-ton reusable range. That capacity underpins orbital refueling, lunar missions, and eventual Mars cargo and crew flights.
Continued growth in sea-level thrust therefore tightens the gap between theoretical rocket performance and the high flight rates and reusability needed to make large-scale space transport practical.
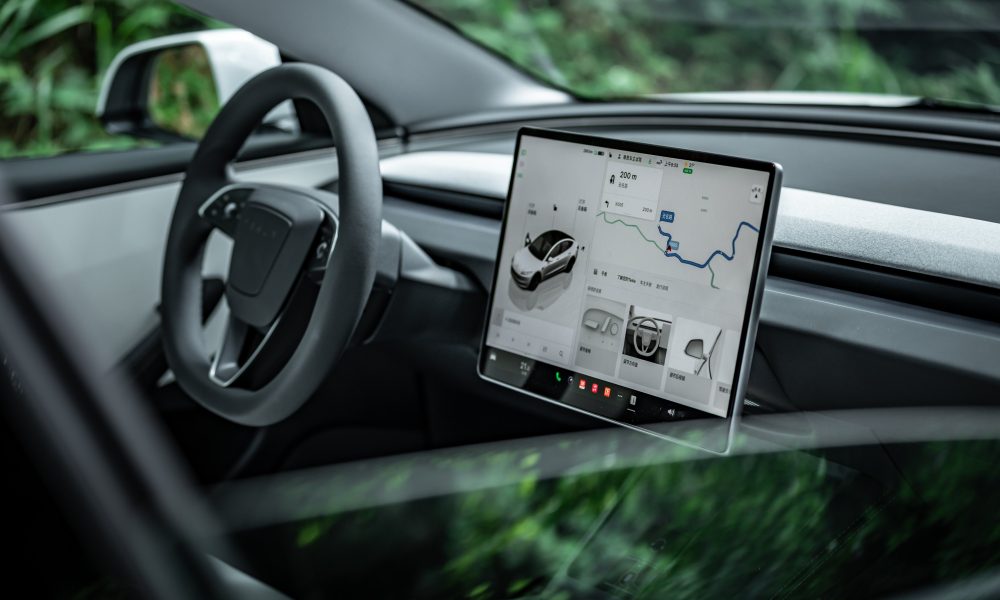
Tesla has expanded its Tesla Assisted Driving (TAD) suite to its tenth European country, as Latvia joined a growing list of European Union member states authorizing the company’s advanced driver assistance technology.
Tesla Europe announced this morning that the system is now approved in Latvia, with a software rollout to begin soon.
The approval and rollout follow recognition of a provisional European type approval originally granted by the Netherlands’ RDW authority on April 10.
🚨 Latvia has just received approval for Tesla Full Self-Driving (Supervised)
This is the 10th country in the EU to gain approval:
1. Netherlands — 10 April 2026 (original RDW approval)
2. Lithuania — 20 May 2026
3. Estonia — 29 May 2026
4. Denmark — 9 June 2026
5. Belgium — 10 June 2026
6. Slovenia — 7 September 2026
7. Czechia — 21 September 2026
8. Croatia — 29 September 2026
9. Slovakia — 16 October 2026— TESLARATI (@Teslarati) October 26, 2026
Latvia’s Road Traffic Safety Directorate (CSDD) evaluated the Dutch documentation, coordinated with the other national authorities, and reviewed updates from Tesla. These included tightened limits on speed offsets, automatic resets of any manual speed adjustments after each trip, and stronger driver monitoring.
In Europe, the feature is marketed as Tesla Assisted Driving after a recent rule change that labeled the name “Full Self-Driving” as misleading.
The system remains an SAE Level 2 driver assistance tool, not unsupervised autonomy. It can control speed, steering, braking, lane changes, and intersections while following a navigation route. Drivers need not keep their hands on the wheel at all times, yet they must continuously monitor the road and be prepared to intervene immediately.
The sequence of EU recognitions began with the Netherlands in April and continued through Lithuania, Estonia, Denmark, Belgium, Slovenia, Czechia, Croatia, and Slovakia. Most have relied on mutual recognition of the single Dutch provisional approval rather than independent national testing.
These national clearances do not yet constitute bloc-wide authorization. An EU-wide decision requires a qualified majority in the Technical Committee on Motor Vehicles: at least 15 of 27 member states representing 65 percent of the EU population. Larger markets, like Germany, France, and Italy, remain under review, and a vote is expected this December.
However, for Latvian Tesla owners with compatible vehicles and software, the imminent rollout expands access to the supervised system while underscoring that attentive human oversight remains essential.

Tesla has a Cybercab problem nobody saw coming

How SpaceX Is raising Raptor’s sea-level thrust while holding engine mass steady


