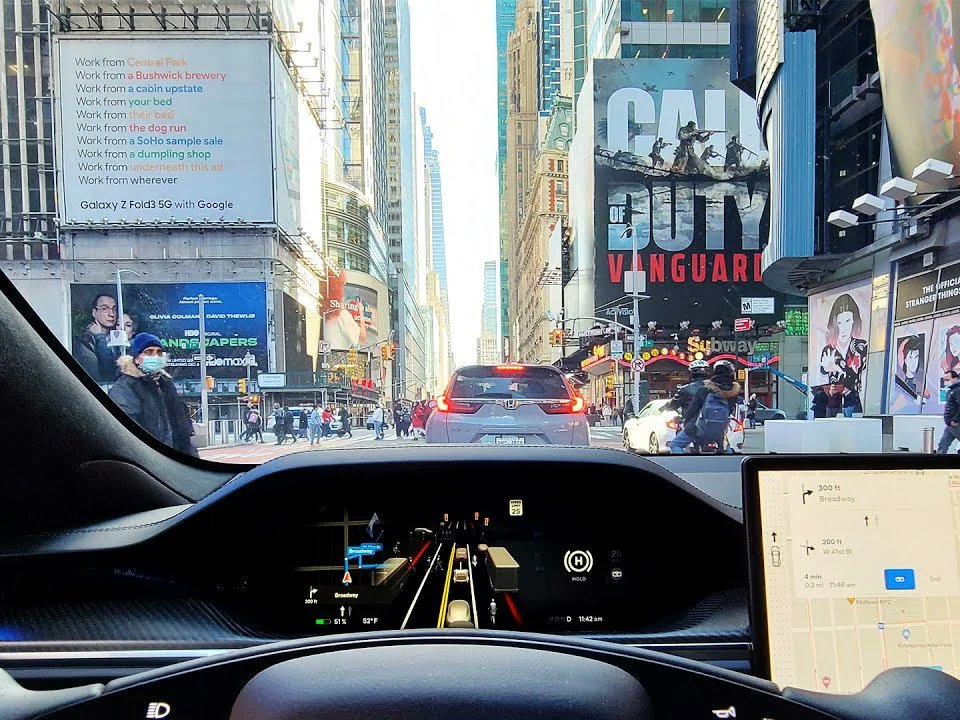

The release notes for Tesla FSD Beta V11.3 have been shared online. Observers from the electric vehicle community suggest that Tesla Full Self-Driving Beta 11.3 is rolling out to the company’s employee FSD Beta testers, at least for now.
The following are Tesla’s FSD Beta V11.3 release notes:
- Enabled FSD Beta on highway. This unifies the vision and planning stack on and off-highway and replaces the legacy highway stack, which is over four years old. The legacy highway stack still relies on several single-camera and single-frame networks, and was setup to handle simple lane-specific maneuvers. FSD Beta’s multi-camera video networks and next-gen planner, that allows for more complex agent interactions with less reliance on lanes, make way for adding more intelligent behaviors, smoother control and better decision making.
- Added voice drive-notes. After an intervention, you can now send Tesla an anonymous voice message describing your experience to help improve Autopilot.
- Expanded Automatic Emergency Braking (AEB) to handle vehicles that cross ego’s path. This includes cases where other vehicles run their red light or turn across ego’s path, stealing the right-of-way.
- Replay of previous collisions of this type suggests that 49% of the events would be mitigated by the new behavior. This improvement is now active in both manual driving and autopilot operation.
- Improved autopilot reaction time to red light runners and stop sign runners by 500ms, by increased reliance on object’s instantaneous kinematics along with trajectory estimates.
- Added a long-range highway lanes network to enable earlier response to blocked lanes and high curvature.
- Reduced goal pose prediction error for candidate trajectory neural network by 40% and reduced runtime by 3X. This was achieved by improving the dataset using heavier and more robust offline optimization, increasing the size of this improved dataset by 4X, and implementing a better architecture and feature space.
- Improved occupancy network detections by oversampling on 180K challenging videos including rain reflections, road debris, and high curvature.
- Improved recall for close-by cut-in cases by 20% by adding 40k autolabeled fleet clips of this scenario to the dataset. Also improved handling of cut-in cases by improved modeling of their motion into ego’s lane, leveraging the same for smoother lateral and longitudinal control for cut-in objects.
- Added “lane guidance module and perceptual loss to the Road Edges and Lines network, improving the absolute recall of lines by 6% and the absolute recall of road edges by 7%.
- Improved overall geometry and stability of lane predictions by updating the “lane guidance” module representation with information relevant to predicting crossing and oncoming lanes.
- Improved handling through high speed and high curvature scenarios by offsetting towards inner lane lines.
- Improved lane changes, including: earlier detection and handling for simultaneous lane changes, better gap selection when approaching deadlines, better integration between speed-based and nav-based lane change decisions and more differentiation between the FSD driving profiles with respect to speed lane changes.
- Improved longitudinal control response smoothness when following lead vehicles by better modeling the possible effect of lead vehicles’ brake lights on their future speed profiles.
- Improved detection of rare objects by 18% and reduced the depth error to large trucks by 9%, primarily from migrating to more densely supervised autolabeled datasets.
- Improved semantic detections for school busses by 12% and vehicles transitioning from stationary-to-driving by 15%. This was achieved by improving dataset label accuracy and increasing dataset size by 5%.
- Improved decision making at crosswalks by leveraging neural network based ego trajectory estimation in place of approximated kinematic models.
- Improved reliability and smoothness of merge control, by deprecating legacy merge region tasks in favor of merge topologies derived from vector lanes.
- Unlocked longer fleet telemetry clips (by up to 26%) by balancing compressed IPC buffers and optimized write scheduling across twin SOCs.
Here are the V11.3 release notes again if you haven't seen them. Very happy to see improvements in rain reflections as that was rare, but could give some insane errors #FSDBeta @elonmusk pic.twitter.com/ZIOcIhmUMd
— Dirty Tesla (@DirtyTesLa) February 20, 2023
Several longtime FSD Beta testers have pointed out some key improvements that would likely be very appreciated by users in V11.3. These include the systems’ improved handling through high speed and high curvature scenarios, as well as improvements to Automatic Emergency Braking (AEB). With the improvements in place, FSD Beta V11.3 would behave closer to a proper human driver.
Comments from longtime Tesla FSD Beta testers also suggest that V11.3 is still only being released for company employees for now. Considering Tesla’s past updates, it would not be surprising if the greater FSD Beta fleet gets the V11.3 update in the coming week or so. This is, of course, unless V11.3 ends up going the way of FSD Beta V11, which was released to employees in November but not to the greater fleet of FSD Beta testers.
The Teslarati team would appreciate hearing from you. If you have any tips, contact me at maria@teslarati.com or via Twitter @Writer_01001101.

News
Tesla Cybercabs take over Austin’s F1 weekend
Tesla Cybercabs swarmed Austin’s F1 Grand Prix as sightings hit a record during race weekend.

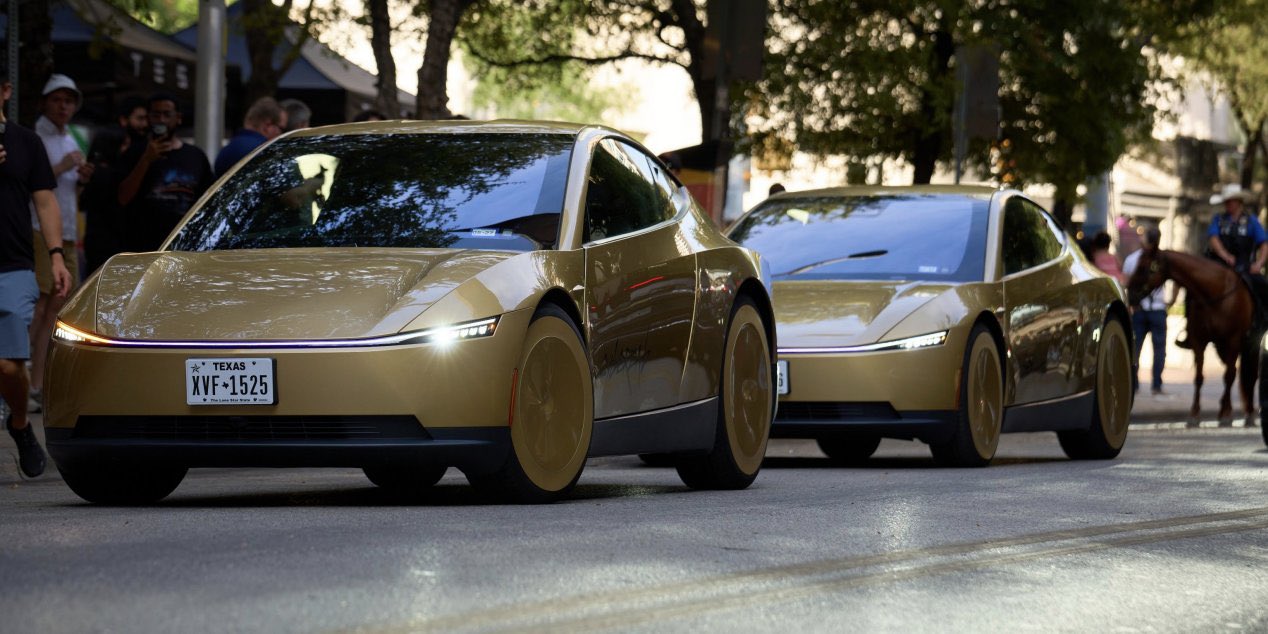
Tesla’s driverless Cybercabs used the Formula 1 United States Grand Prix in Austin as their biggest public stress test yet. On Sunday afternoon, Tesla head of AI software Ashok Elluswamy quoted a photo from X user Ben Steindl showing a long line of gold Cybercabs and Model Y Robotaxis stacked up on a road near Circuit of the Americas. “Robotaxis as far as the eye can see!” Elluswamy wrote. Steindl’s original post was more matter of fact: “@Tesla @robotaxi is busy for the Austin F1.”
The fleet also handled the trip home. The race started at 3 p.m. Central, and once it ended, Cybercab Spotter, an account that logs Cybercab sightings around Austin, posted that “People are requesting Cybercabs to get home.”
Robotaxis as far as the eye can see! 🤩
— Ashok Elluswamy (@aelluswamy) October 25, 2026
Tesla set this up days in advance without announcing it. Late on October 22, rider David Moss posted Robotaxi app screenshots showing the Austin service area wrapping around the track toward Elroy and FM 812, with ride requests open until 1 a.m. A banner in the app read “Last call is 1am · Limited to nearby dropoffs.” Austin rides ended at 11 p.m. as recently as early October, as Teslarati reported, before moving to midnight on October 17.
Not every rider got dropped at the gate. Early app searches showed spots like COTA Karting as “Service blocked,” and one rider who took a Cybercab to the track Friday said the rideshare area was less than a 20 minute walk from the front gate.
The weekend also produced a new activity record. Cybercab Spotter counted 1,250 Cybercab sightings in Austin on Saturday, qualifying day. The previous high was 1,072 on October 16. Sightings count the same car more than once, so they measure how busy the fleet is rather than how big it is. For size, the Texas automated vehicle registry listed 463 Cybercabs at midday Sunday, up from the 300+ Tesla claimed on October 10, when Elluswamy also said Dallas is next for Cybercab.
The track was out of reach for Tesla’s main rival. Waymo runs in Austin only through Uber, and its service area stops well short of COTA. Waymo did not announce any race day service.
Tesla has not said how many rides it gave to and from the circuit, or whether the expanded zone and 1 a.m. cutoff will stay after race weekend. On the third quarter earnings call, Elluswamy said 2 a.m. service is coming “pretty soon” and that Tesla plans to run Robotaxi around the clock before the end of the year. The company is also aiming to hand the first Cybercabs to customers before 2026 ends, which would put cars like these outside Tesla’s own fleet for the first time.
News
Tesla makes good on its Cybercab promise in just two weeks
Tesla Cybercab riders can now pull up a rear camera view and darken the screen.
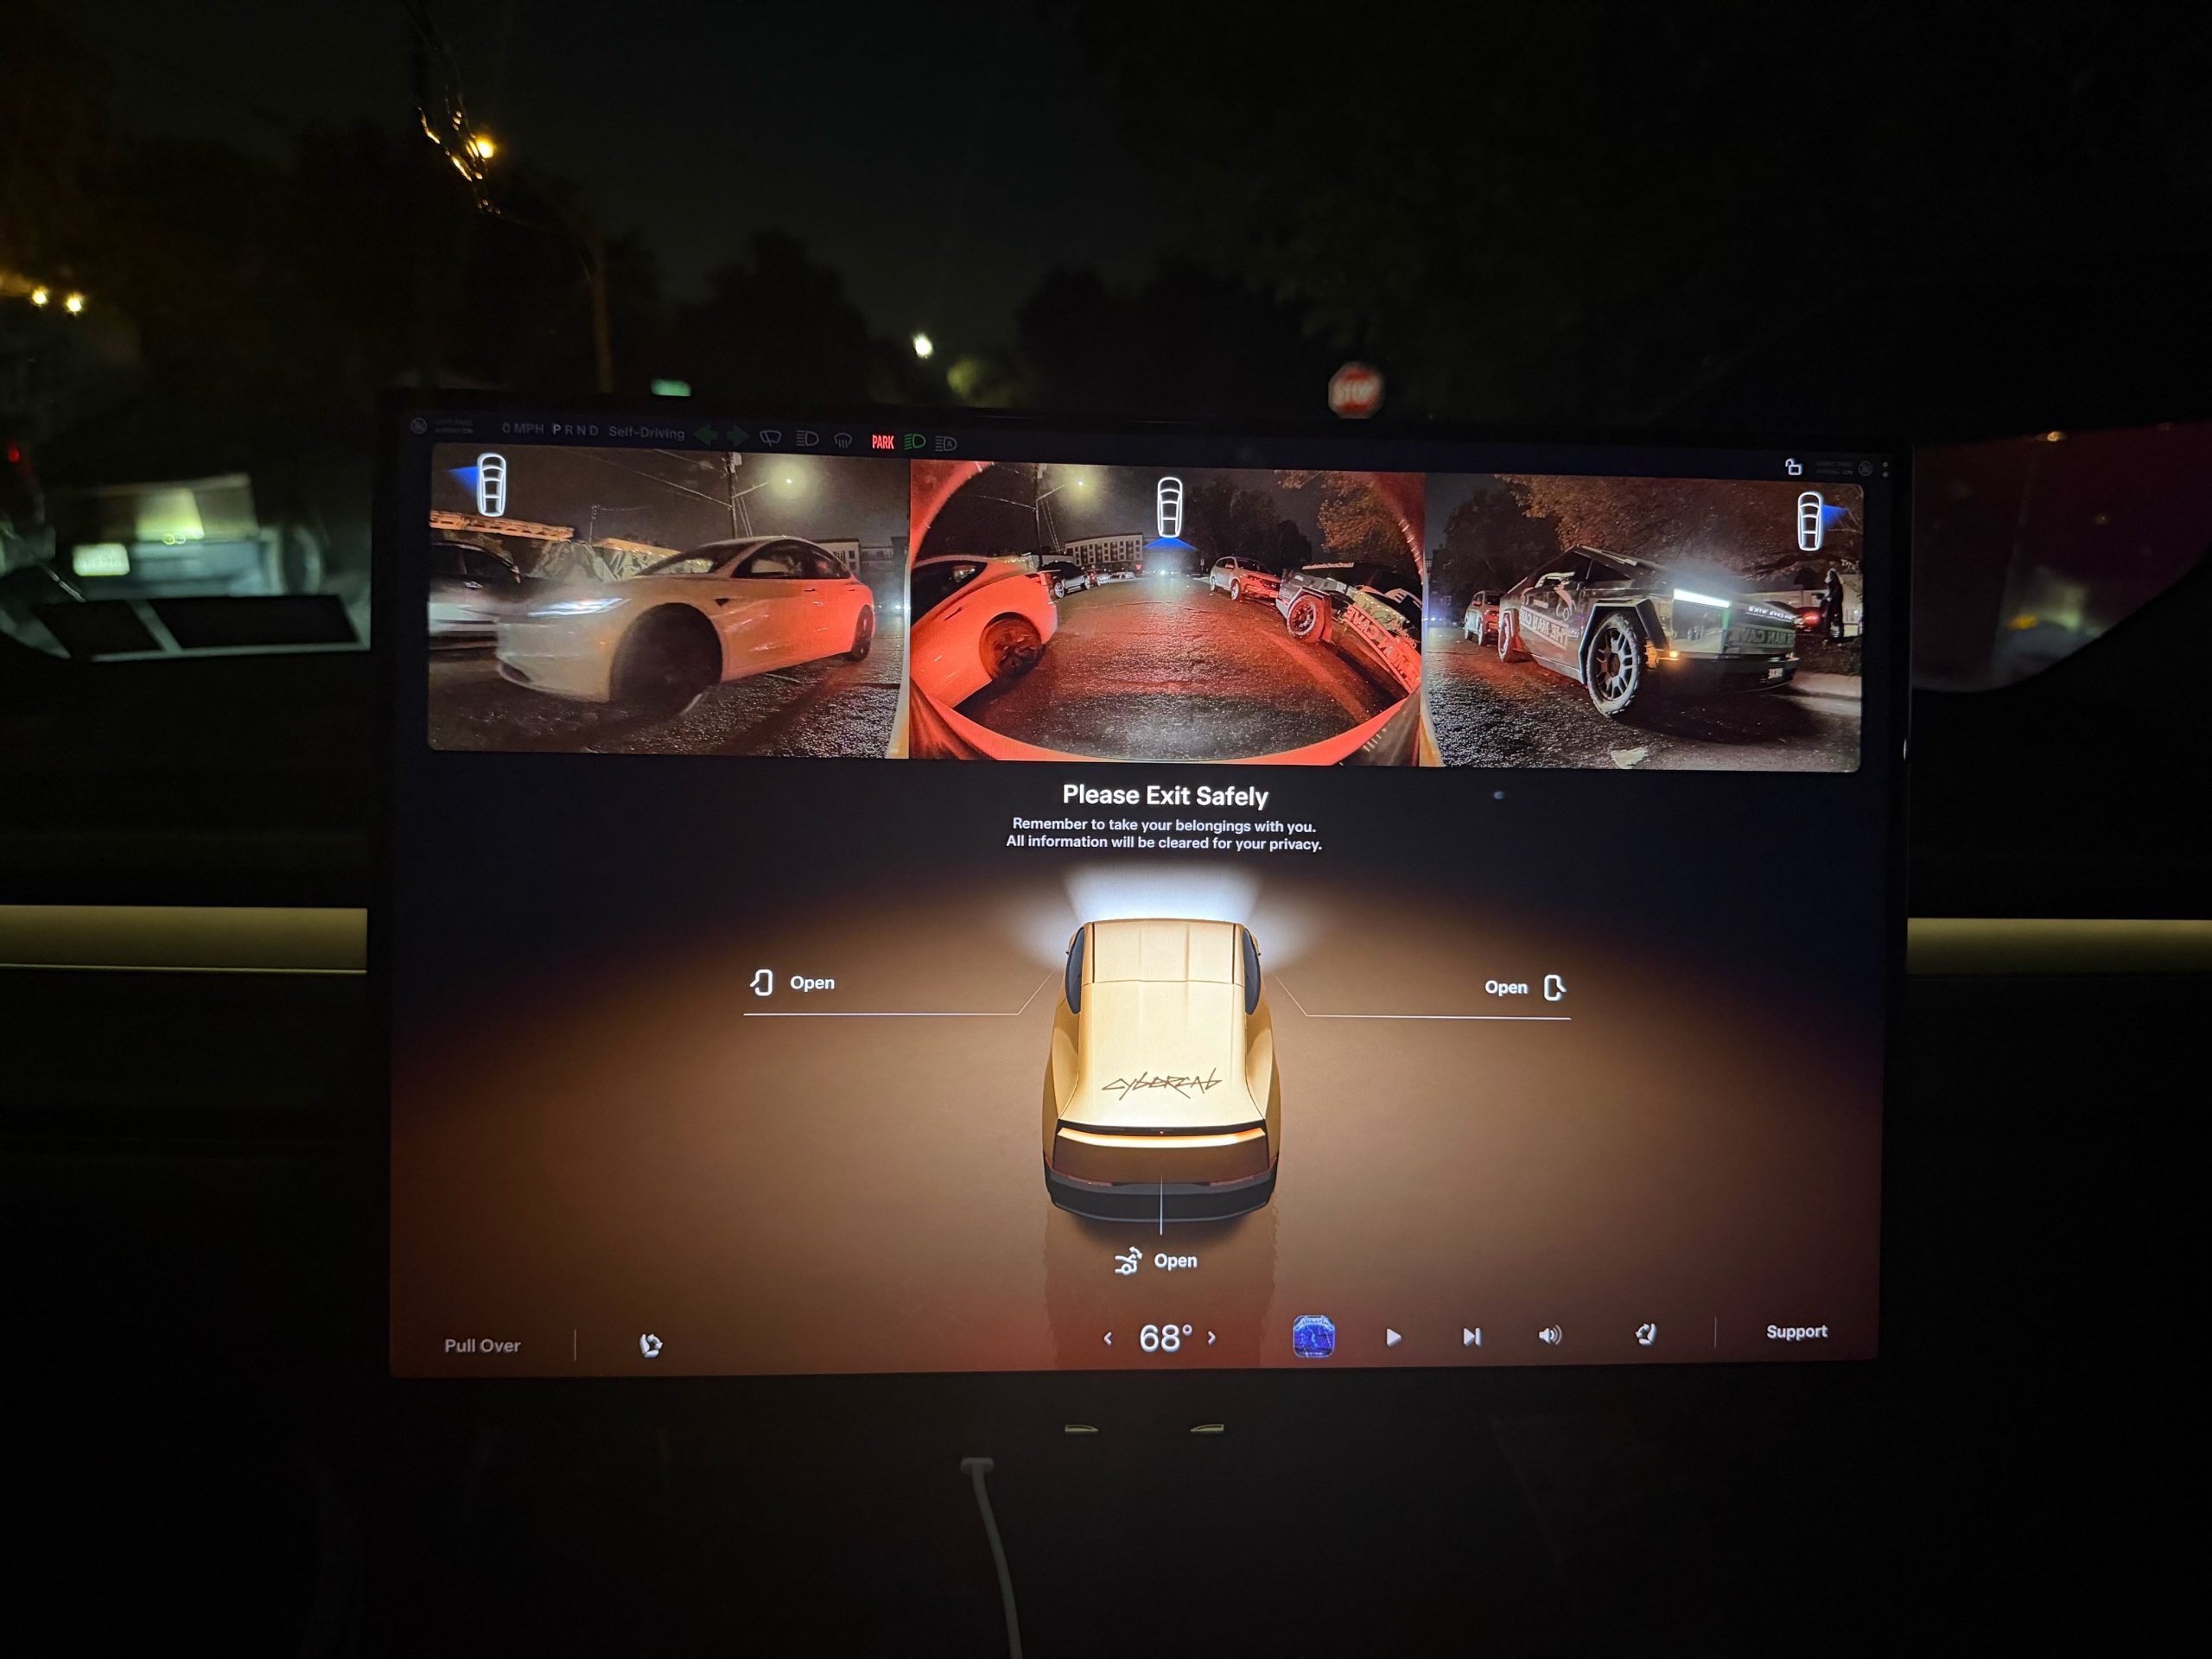
Tesla has given Cybercab passengers a way to see what is behind them, along with a way to turn the cabin screen off entirely.
Riders in Austin can now bring up a live rearview camera feed on the Cybercab’s center display in the middle of a trip. Austin rider Ethan McKanna spotted the change late Friday night, posting from a ride that “You can now open the camera to view what’s behind you in Cybercab!” His photo shows a strip of rear camera video across the top of the screen, with another Cybercab following on a bridge. Sawyer Merritt shared the image Saturday and wrote that it “sounds like” there is also a new quiet mode that darkens the entire screen for riders who want to relax, sleep, or avoid a bright display at night.
The camera view goes beyond the rear feed. Tesla UI software engineer Evan, who posts as @CarCoder, replied to McKanna with a tip: “You can also tap it to see more cameras, and swipe it up or down to hide and show.” Until now, the Cybercab only showed its rear and repeater feeds on the “Please Exit Safely” screen at the end of a ride, so passengers could check for cyclists and traffic before opening a door.
Quiet mode surfaced a day earlier. Austin rider Jackson Blatz posted a video Friday morning of the new Robotaxi interface in a Cybercab with the option. Tesla has not published release notes for either feature.
The rear camera view moved quickly from request to release. Earlier this month, Cybercab rider Dan Burkland asked Tesla to let passengers pull up the rear and repeater cameras whenever they want, “especially for peace of mind.” Evan answered “In development,” as Teslarati reported at the time. About two weeks later, riders have it.
The feature fills a gap created by the Cybercab’s design. With no steering wheel, no pedals, no mirrors and no rear window, a passenger has no natural way to glance behind the car. The eight exterior cameras that feed Tesla’s autonomy software were already on board, so the change only required software.
There is also an AI angle to how it was built. Yun-Ta Tsai, a senior staff engineer on Tesla’s AI team, quoted Merritt’s post and wrote that the “(human) camera view tuning is optimized with Grok and implements part of the algorithm by directly programming the fixed-function hardware, so I don’t even need to check the datasheet.” Tsai did not say which part of the algorithm Grok handled. Grok already plays a bigger role inside the vehicle, with Grok Bot now enabled across every Cybercab and the Model Y Robotaxi fleet after Tesla brought the agent into its cars in September.
The two features join a busy week of changes for riders in Austin, which also brought a redesigned Live Activity for iPhone and Apple Watch and live trip sharing. They also arrive as Tesla prepares the Cybercab for life outside its own fleet. On the third quarter earnings call, Lars Moravy said the company is aiming to deliver Cybercabs to customers before the end of 2026. Tesla has not said whether the camera view and quiet mode will also come to its Model Y Robotaxis.
Elon Musk
Tesla shows what Roadster drivers will see on screen before thruster activation
Tesla’s Roadster video reveals a fighter jet inspired cockpit with a 5,500 PSI thruster gauge.
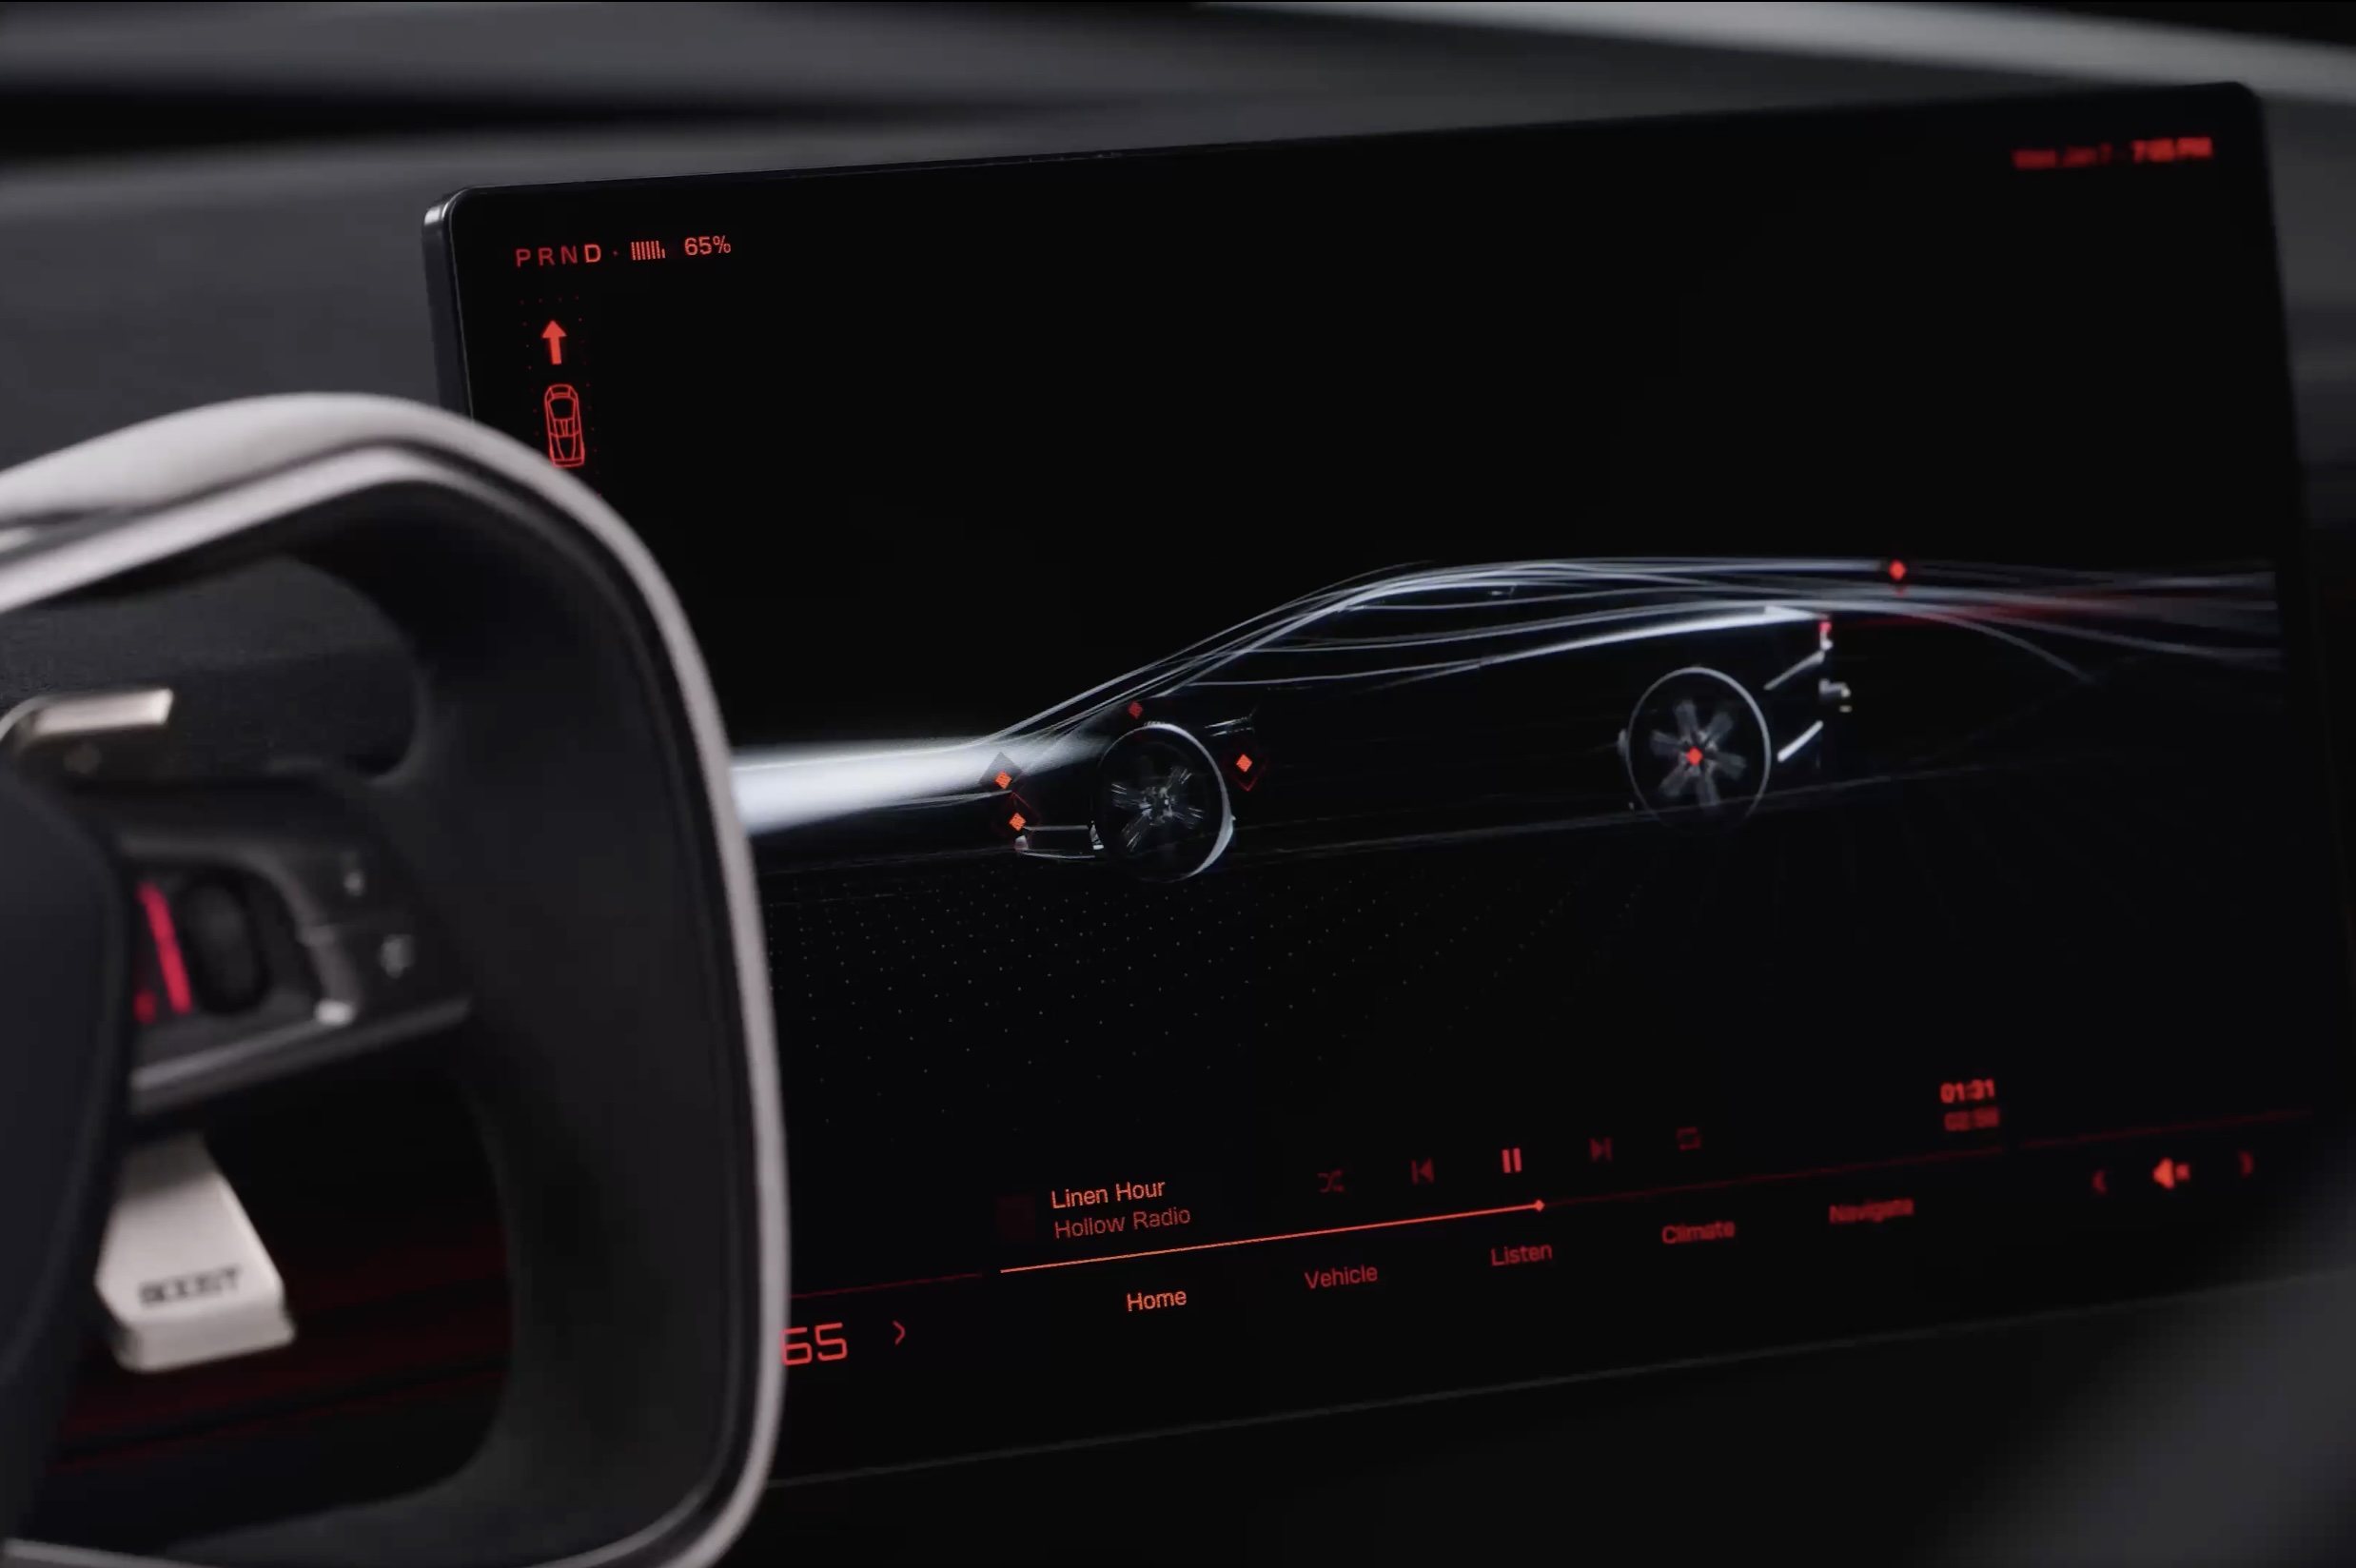
Tesla has given future owners their clearest look yet at the cockpit of its next generation Roadster. In a 34 second video posted to X on Friday afternoon, the company walked through the car’s touchscreen with a caption: “Inspired by fighter jet cockpits, Roadster’s interface was designed around the pilot.”
The clip opens on a black screen with red graphics and a 3D wireframe of the car, which sits beside the Roadster’s squared off yoke. Tapping parts of the model brings up controls for the rear wing, including low drag and high downforce positions, along with a charging page with a charge limit bar and a small music player. A row of tabs along the bottom reads Home, Vehicle, Listen, Climate and Navigate.
Most of the video is spent in Track Mode. The dashboard shows a live circuit map, a list of session lap times, brake and motor temperatures, and pressure and temperature readouts for each tire. A setup page lets the driver pick Auto, Low Drag, High Downforce or Custom aero modes, adjust aero balance and brake balance, and switch stability and traction control off. Along the bottom, a status bar reads “Thruster · 5,500 PSI” next to a “Boost Ready” indicator.
That gauge ties the software to the hardware Tesla showed off near Waco, Texas on October 15. The Thrust and Rocket versions use cold gas thrusters fed by carbon overwrapped pressure vessels, and Tesla lists 0 to 60 mph times of under 0.9 seconds and under 0.59 seconds for them, as Teslarati detailed in its breakdown of the three Roadster configurations. The base Performance car relies on a fan and ground sealing system for grip, and the aero settings on screen match the active wings and suction setup covered in our look at how the Roadster generates downforce.
The Roadster layout is a departure from the rest of Tesla’s lineup. Instead of a map centered screen, the Roadster puts the car itself at the center of the home page, and Tesla’s Roadster page lists two smaller forward displays alongside the main touchscreen. Tesla has not said whether any of the Track Mode telemetry will make its way to the Model 3 Performance or other vehicles.
The interface could still change before deliveries. Elon Musk said at the event that Roadster production will begin in 2028, and Tesla says the flagship Rocket version is not approved for public road use. Reservations are open with a $50,000 payment, while Thrust is listed as a limited release and Rocket is invite only.
Those who want to see the car in person will get their first chance this weekend. The Roadster goes on display in the lobby of the Petersen Automotive Museum in Los Angeles from October 24 to 27, according to Sawyer Merritt, the first time the public will be able to view it up close.

Tesla Cybercabs take over Austin’s F1 weekend

Tesla makes good on its Cybercab promise in just two weeks


